

Multimodal Fusion
3 related stories
CONTACT Authors on Tactile Sensing: What Robots Need for Tasks and Representations
42HOW Robotics speaks with CONTACT authors Zhiyuan Zhang and Adeesh Desai about why task-relevant physical information, rather than raw sensor data, is critical for contact-rich manipulation.
Purdue Team's IROS Best Paper Nominee: Active Palm and Multimodal Sensing in a Three-Finger Robot Hand
Yuhao Zhou and team from Purdue University present the VTAP Gripper, a three-fingered robot hand that achieves complex manipulation by making the palm active and multimodal. The design challenges the trend of adding fingers, proving that dexterity can come from effective use of existing contact surfaces rather than increased degrees of freedom.
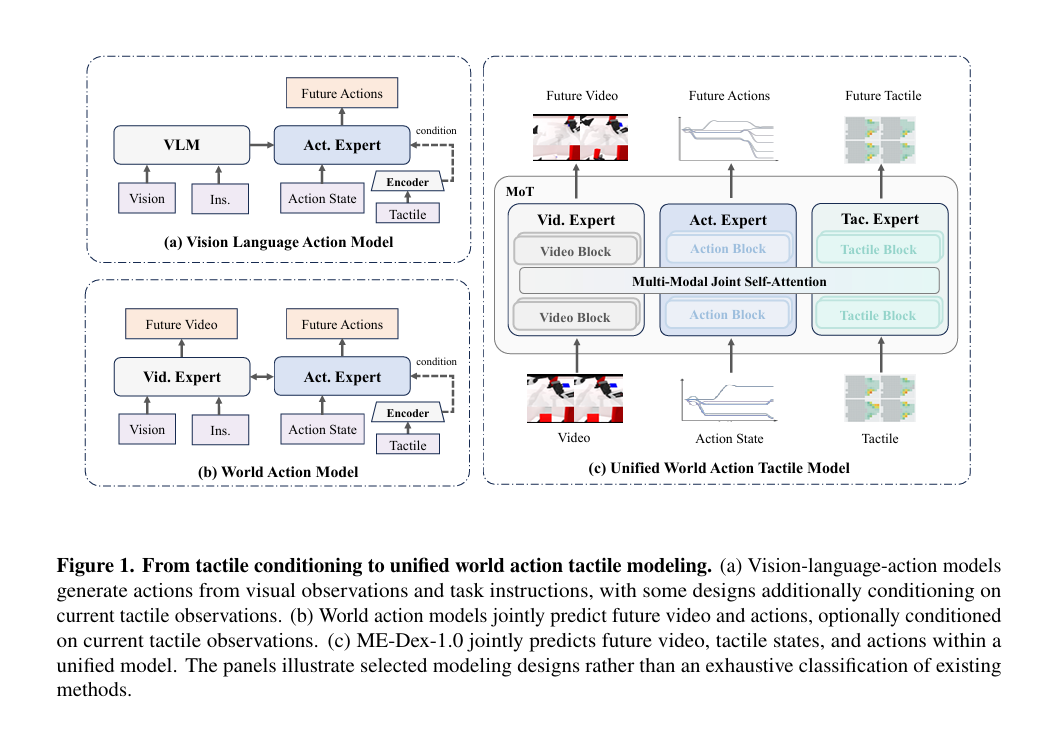
Li Auto's ME-Dex 1.0 Predicts Future Tactile States Alongside Visual Observations
Li Auto’s foundation model team released ME-Dex 1.0, a world action model that treats tactile sensing as a parallel prediction target to video. By aligning heterogeneous tactile data from five different hands into a unified representation, the system significantly improves success rates in high-contact dexterous manipulation tasks.