

42HOW Robotics — research, industry and AI hardware
AGILINK Cuts Dexterous Hand Failure Rate to 0.5% for Industrial Deployment
At AgiBot's Innovation Day on October 29, AGILINK demonstrated a production testing station via a cross-city link, where a dexterous hand used a screw gun to test another unit awaiting factory release. At the company's joint manufacturing base with Wolong in Shaoxing, the robot executes 72 operational steps, including material loading, barcode scanning, clamping, screw tightening, equipment activation, and unloading.
AgiBot Proposes 'Worken' Metric to Measure Actual Robot Labor Output
Following the deployment of over 300 robots at Chimelong, AgiBot introduced the "Worken" metric to evaluate actual labor output rather than mere deployment numbers, highlighting the ongoing challenge of scaling on-site engineering support.

Carnegie Mellon Researchers Introduce ELEVATE Framework to Help Quadrupeds Acquire New Controllers from Task Failures
Quadruped robots with manipulators face a hard limit when required motions are absent from pre-trained libraries. The new ELEVATE framework enables these robots to autonomously diagnose missing physical capabilities during task failures and train new whole-body controllers using reinforcement learning.
PokeBot Launches Free RoboAPI to Adapt a Single World-Action Model Across Multiple Robot Arms
On October 30, PokeBot released RoboAPI, a public interface for its proprietary Poke-Aurora world-action model, aiming to eliminate the need for repeated data collection and retraining when developers switch robot hardware.

Research
All Research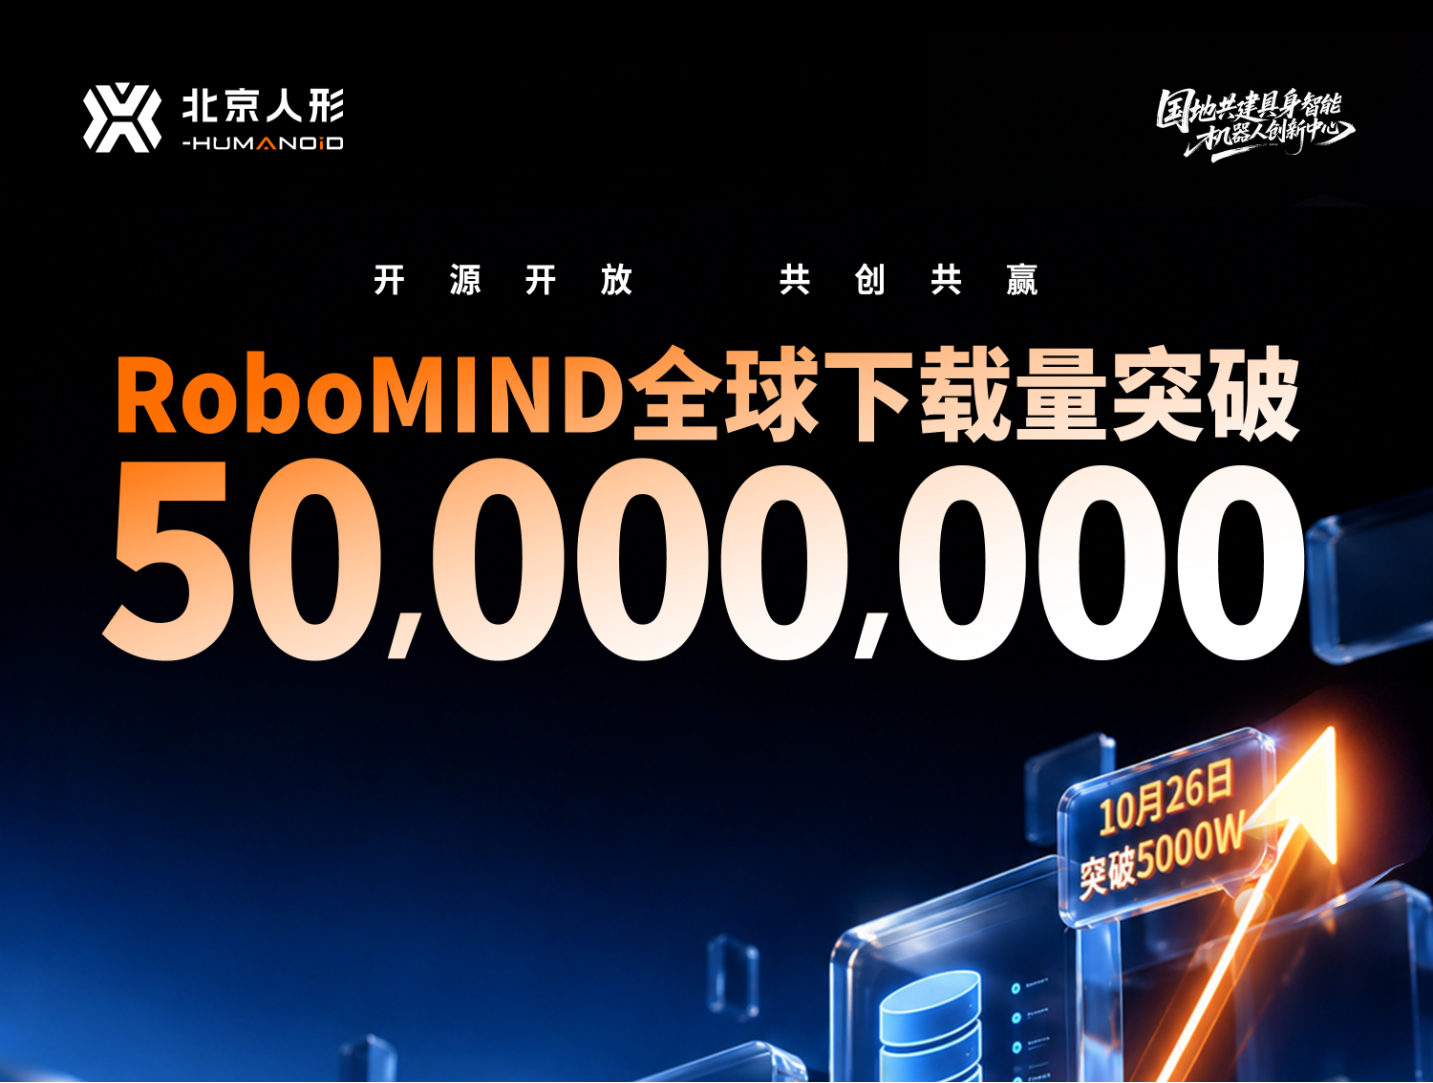 Embodied AI · Robotics Datasets
RoboMIND Downloads Surpass 50 Million, With the Latest 10 Million Achieved in Just 18 Days
The Beijing Innovation Center of Humanoid Robotics announced that its open-source dataset, RoboMIND, has exceeded 50 million global downloads. The latest 10 million downloads were achieved in just 18 days, reflecting rapid adoption as the dataset expands to over 400,000 trajectories.
 Embodied AI · Experience Retrieval
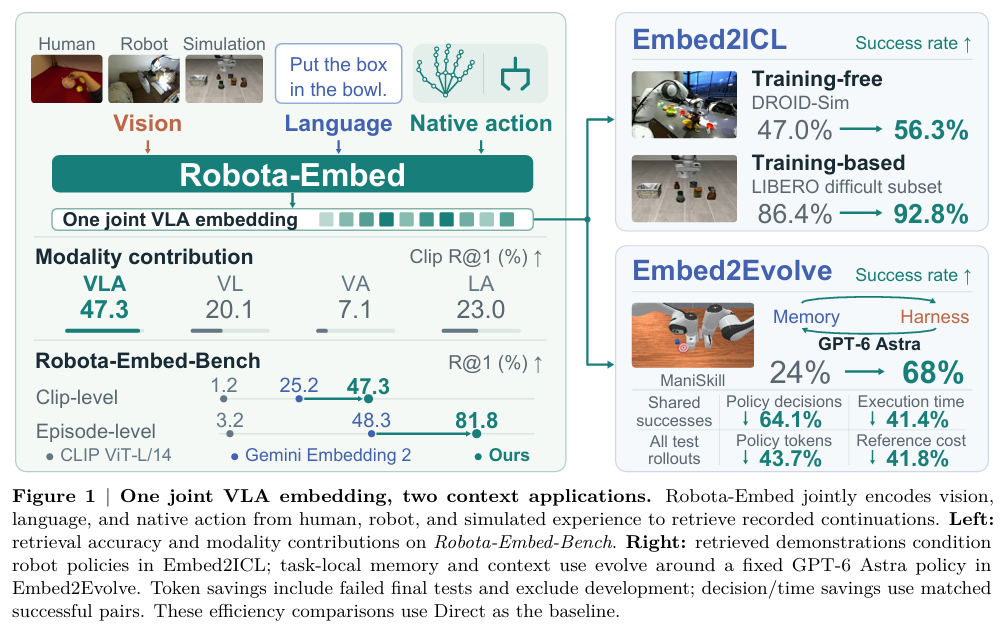
Robota-Embed: Joint Action and Visual Encoding for Robot In-Context Learning
A joint team from NVIDIA, MIT, UC Berkeley, Oxford, and CMU introduces Robota-Embed, a unified VLA embedding that incorporates action data into experience retrieval. The model significantly improves robot in-context learning by matching future behavior logic rather than just visual similarity.
 Embodied AI · World Models
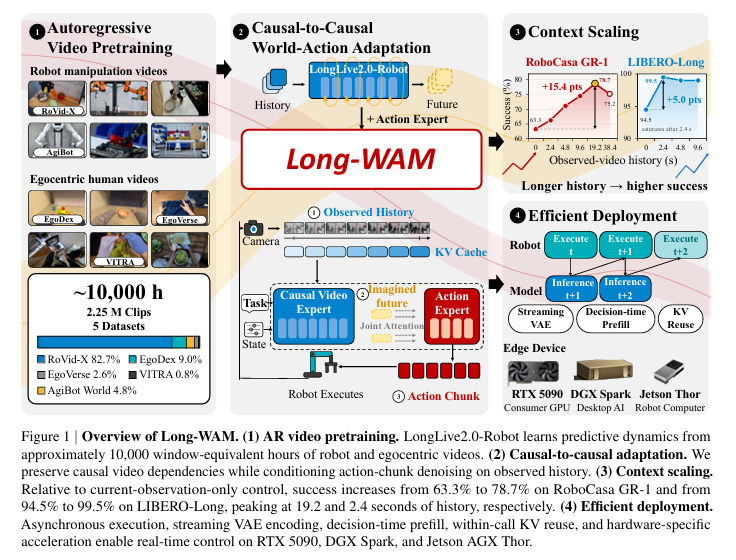
NVIDIA and MIT Researchers Show Long-Context Robotics Requires Autoregressive World Models
A joint paper from NVIDIA, MIT, HKU and UCSD demonstrates that simply extending visual history does not improve robot control; the model must first learn autoregressive prediction to effectively use long contexts. On the RoboCasa GR-1 platform, task success rates rose from 63.3% to 78.7% when context was extended to 19.2 seconds.
AI Hardware
Devices, chips, sensors and new interfaces that bring AI out of the browser and into the physical world. Exploring how emerging technology becomes real products.
Explore AI Hardware
Smart Glasses Sales Doubled in the First Nine Months, Yet Manufacturers Are Still Losing Money
Ahead of the Double 11 shopping festival, the smart glasses sector reported strong growth: Ray-Ban parent EssilorLuxottica recorded EUR 486 million in third-quarter wearable revenue, while China's Ministry of Commerce noted a 1.1-fold year-on-year increase in domestic smart glasses sales during the first nine months.
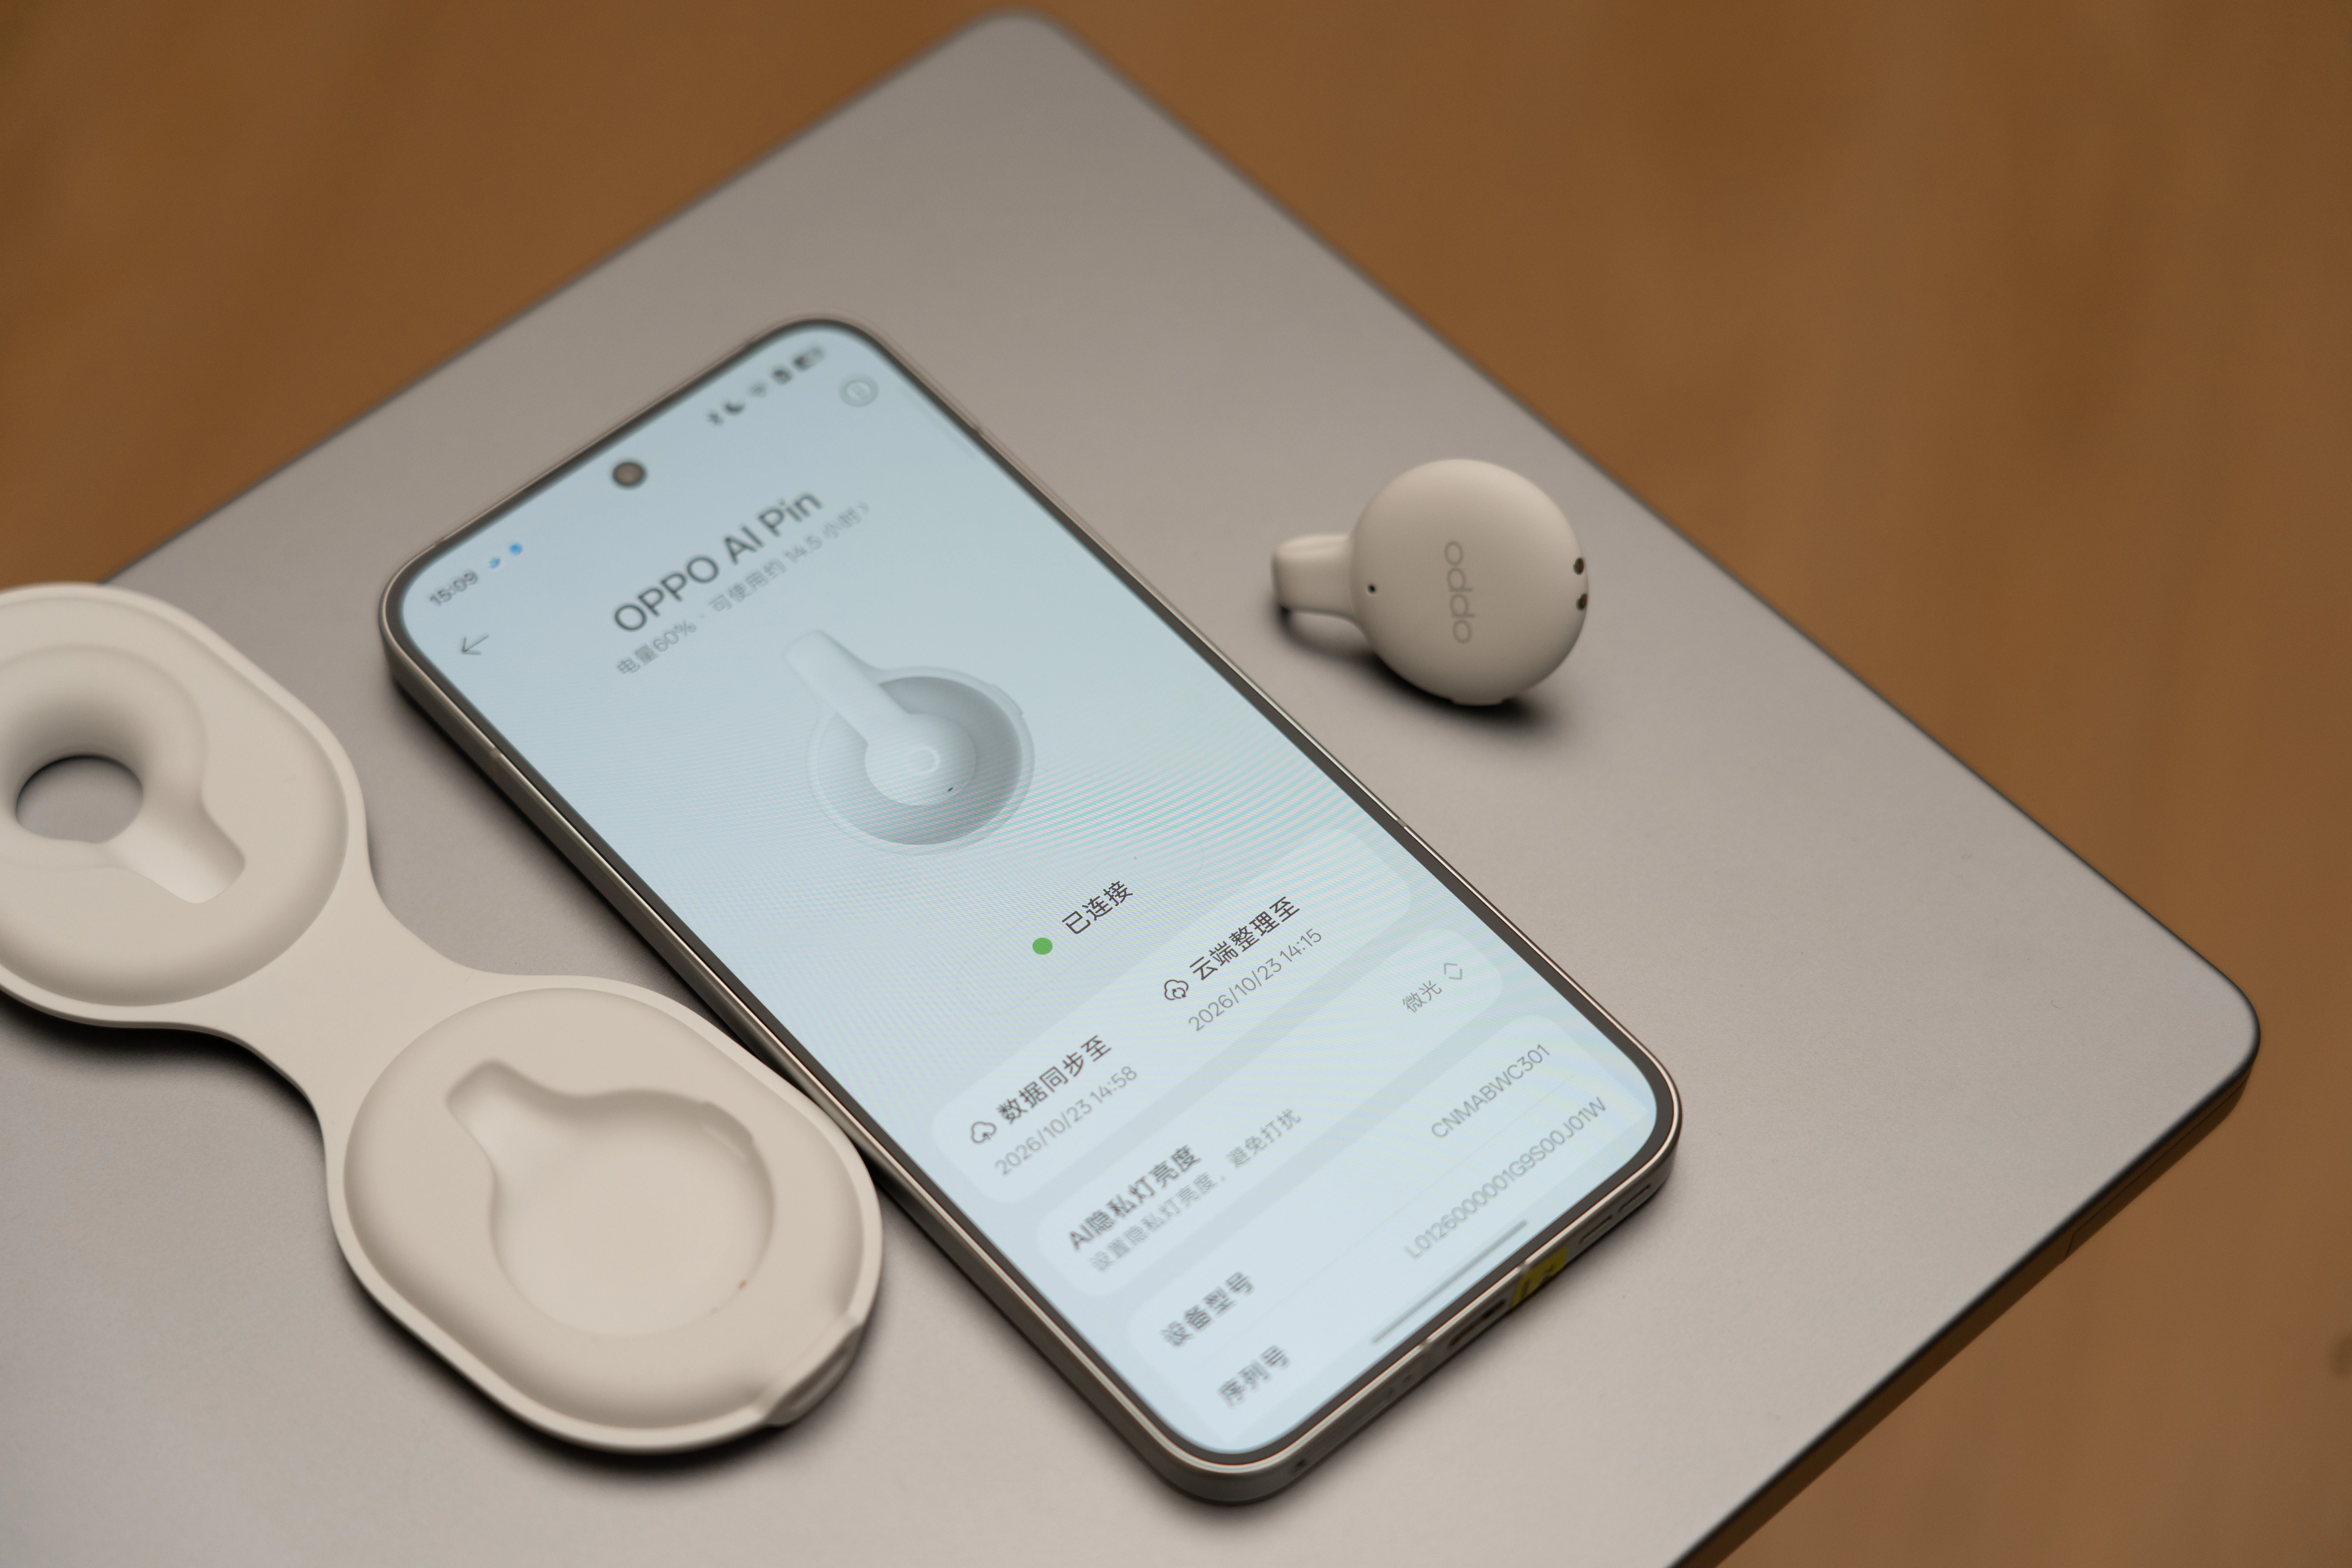
Hands-On With OPPO's Xinliqiu AI Wearable: Building a Proactive Personal Agent From Always-On Audio
The OPPO Xinliqiu, identified in the companion app as the OPPO AI Pin, is a minimalist 9.8-gram always-on audio wearable. We tested its real-world context capture and integrated it with third-party tools via the Model Context Protocol (MCP) to build a proactive personal agent, evaluating its utility and hardware limitations.
Industry & Deployment
All Industry
D-Robotics Raises USD 400 Million in C Round as Embodied AI Business Enters Mass Production
D-Robotics has closed a USD 400 million Series C round led by Future Asset, bringing its total disclosed funding since 2025 to USD 770 million. The company reports that its Sunrise S600 chip is entering mass production with over 20 clients, including TARS and UBTECH, while cumulative shipments of the Sunrise series have surpassed 8 million units.
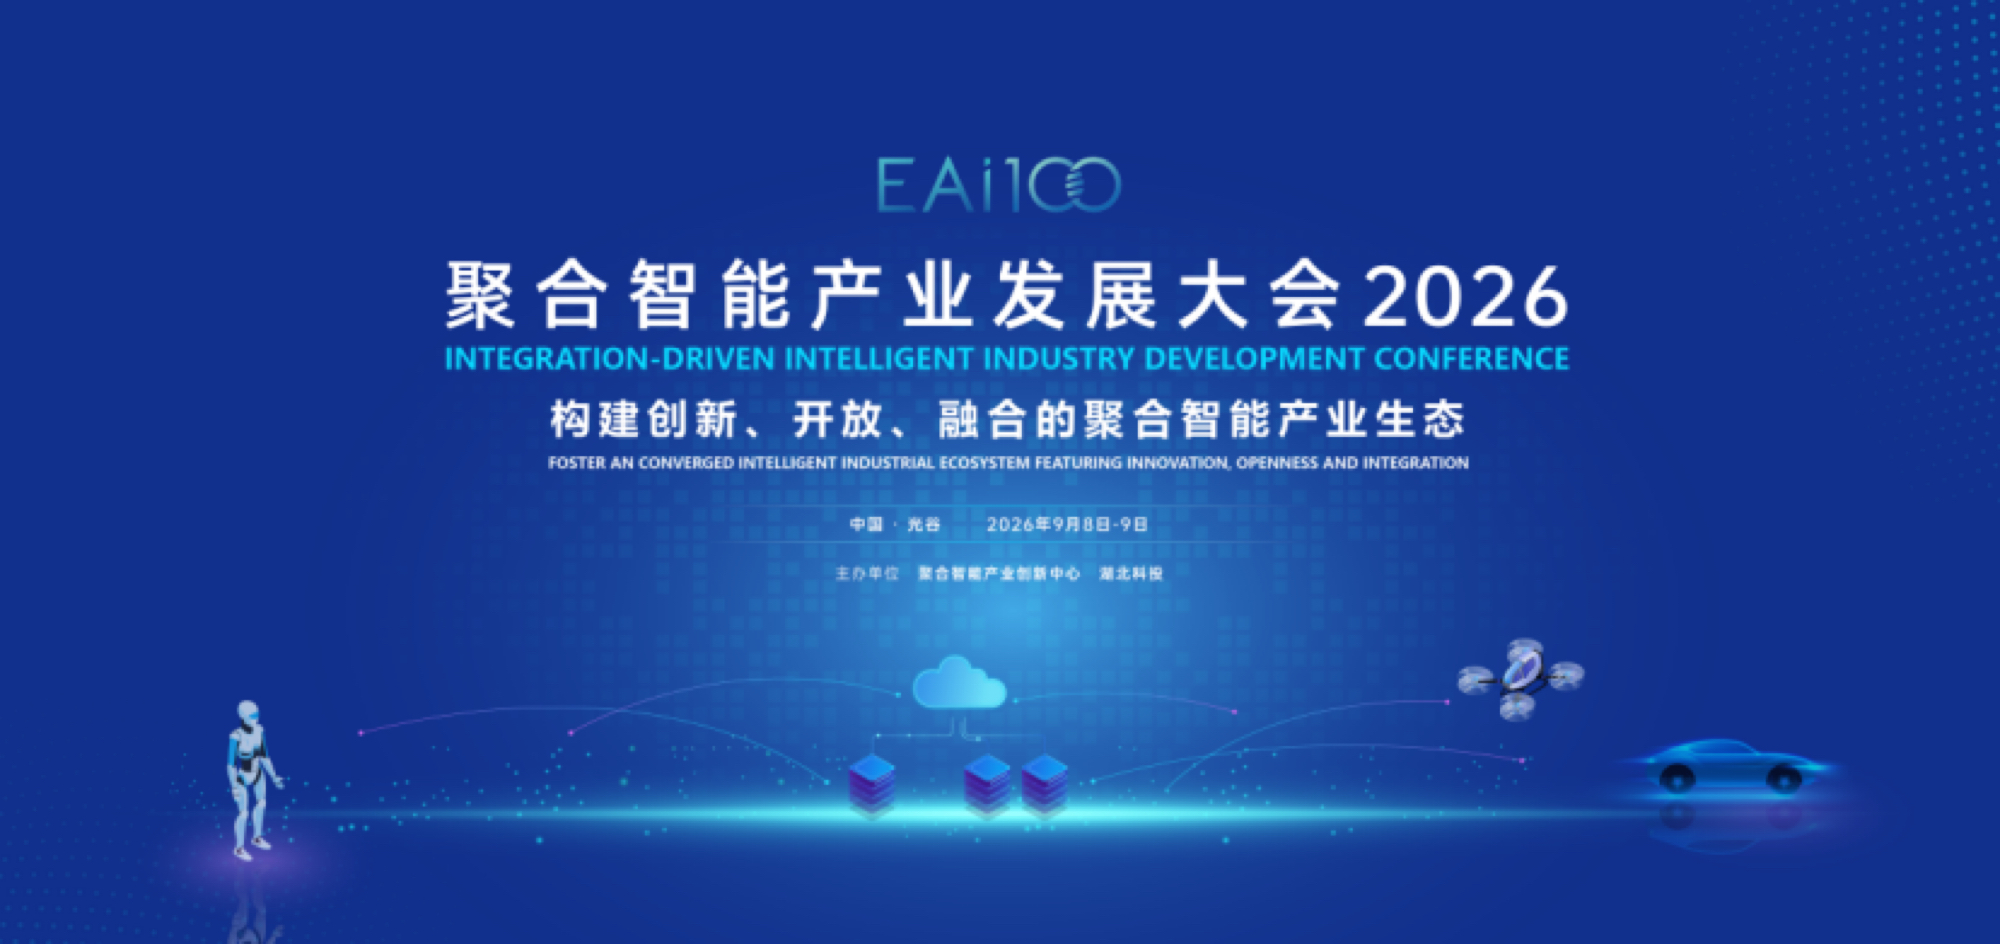
2026 Aggregated Intelligence Industry Development Conference to Be Held in Optics Valley
The 2026 Aggregated Intelligence Industry Development Conference will take place in Optics Valley on September 8-9, focusing on the synergy of smart vehicles, embodied AI, and low-altitude economy.
How Embodied AI Is Rethinking Robot Data
A Beijing humanoid robot data training center has ceased operations, highlighting that while embodied AI still lacks data, the industry needs high-quality, large-scale, diverse data infrastructure rather than just more robots.
Interviews
All interviews
IROS Best Paper Finalist: Helping Robots Detect Glass for Safer Navigation
42HOW Robotics interviews co-first author Yu Jingwen on the Southern University of Science and Technology team’s RANSAC-based framework that fuses depth foundation models with sensor data to enable safe robot navigation through glass obstacles.
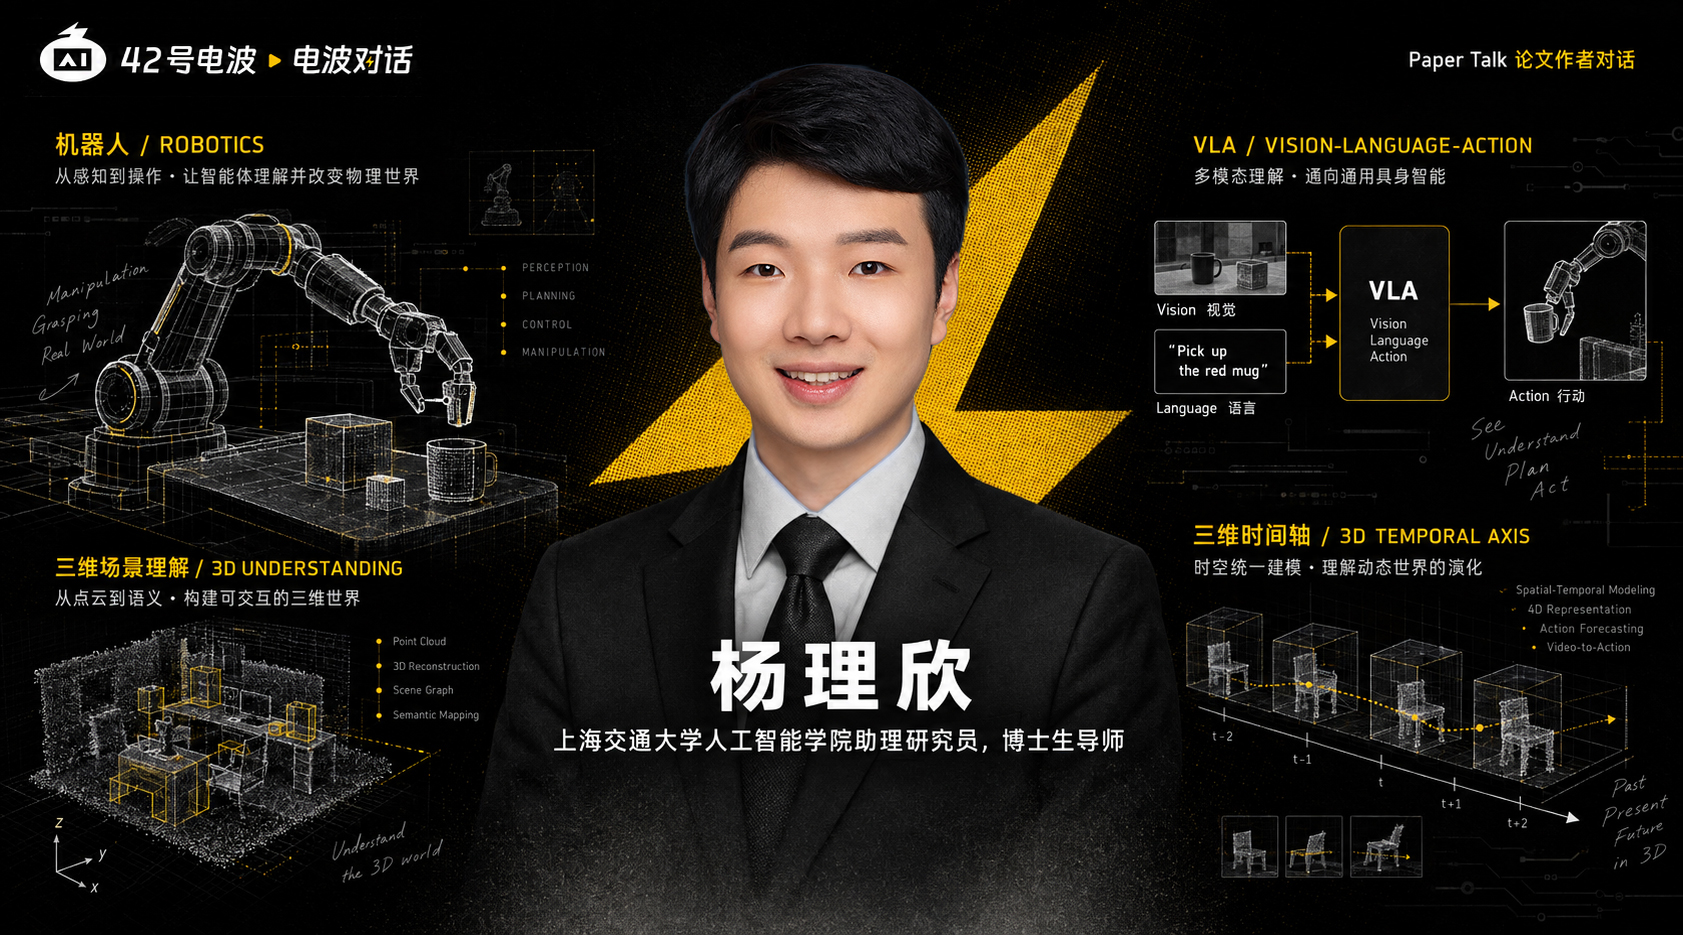
Shanghai Jiao Tong University Assistant Researcher Yang Lixin on Why Robots Need a '3D Time Axis'
Shanghai Jiao Tong University assistant researcher Yang Lixin discusses how LaMP, ChronoFlow-Policy, and Track4Action integrate 3D point flow to give robots spatial awareness, temporal memory, and understanding of environmental changes.