

Robot Control
3 related stories
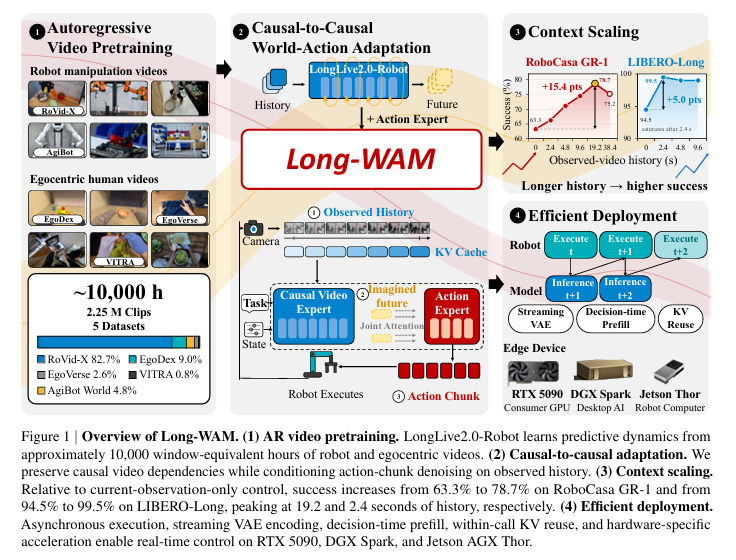
NVIDIA and MIT Researchers Show Long-Context Robotics Requires Autoregressive World Models
A joint paper from NVIDIA, MIT, HKU and UCSD demonstrates that simply extending visual history does not improve robot control; the model must first learn autoregressive prediction to effectively use long contexts. On the RoboCasa GR-1 platform, task success rates rose from 63.3% to 78.7% when context was extended to 19.2 seconds.
INTACT: Search-Free World Model for Robotics Achieves Faster, More Reliable Control
Researchers propose INTACT, a search-free world model framework that aligns physical and goal intentions using a shared operator. Achieving 95.33% success rate with 300x faster inference than LeWM, it upgrades JEPA from prediction to deployable control.
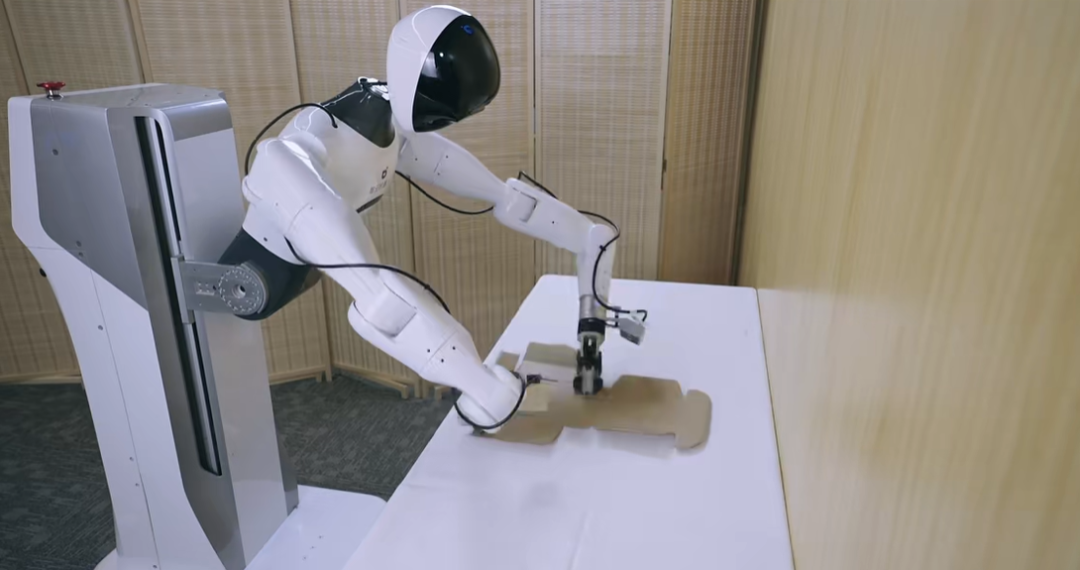
AgiBot Unveils GO-2 Model to Bridge the Semantic-Motor Gap in Robotics
AgiBot released its next-generation VLA foundation model, Genie Operator-2 (GO-2), introducing 'Action Chain of Thought' and an 'Asynchronous Dual-System' architecture to address the long-standing gap between perception and execution in robotics.