

Research
Papers, models, data and advances in robot learning.
Carnegie Mellon Researchers Introduce ELEVATE Framework to Help Quadrupeds Acquire New Controllers from Task Failures
Quadruped robots with manipulators face a hard limit when required motions are absent from pre-trained libraries. The new ELEVATE framework enables these robots to autonomously diagnose missing physical capabilities during task failures and train new whole-body controllers using reinforcement learning.

PokeBot Launches Free RoboAPI to Adapt a Single World-Action Model Across Multiple Robot Arms
On October 30, PokeBot released RoboAPI, a public interface for its proprietary Poke-Aurora world-action model, aiming to eliminate the need for repeated data collection and retraining when developers switch robot hardware.
AgiBot's Rollback Method Uses World Model 'Rewind' to Surpass Human Averages in 8 Hours of Real-Robot Training
AgiBot, Beihang University, and the National University of Singapore introduced Rollback, a policy improvement method that backtracks within a world model to explore alternative actions. Trained on a single real robot for eight hours, the approach outperformed human baselines in ball tossing and tabletop curling by eliminating costly physical scene resets.
AgiBot Upgrades Genie Sim to Unify Robot Training and Evaluation via Flexible-Body Simulation
Folding a towel or tightening a drawstring bag is simple for humans but challenging for robots, as fabrics and ropes continuously deform and contact friction alters subsequent manipulation conditions. If simulation fails to replicate these dynamics, robots may perform well virtually but fail in real-world deployment.
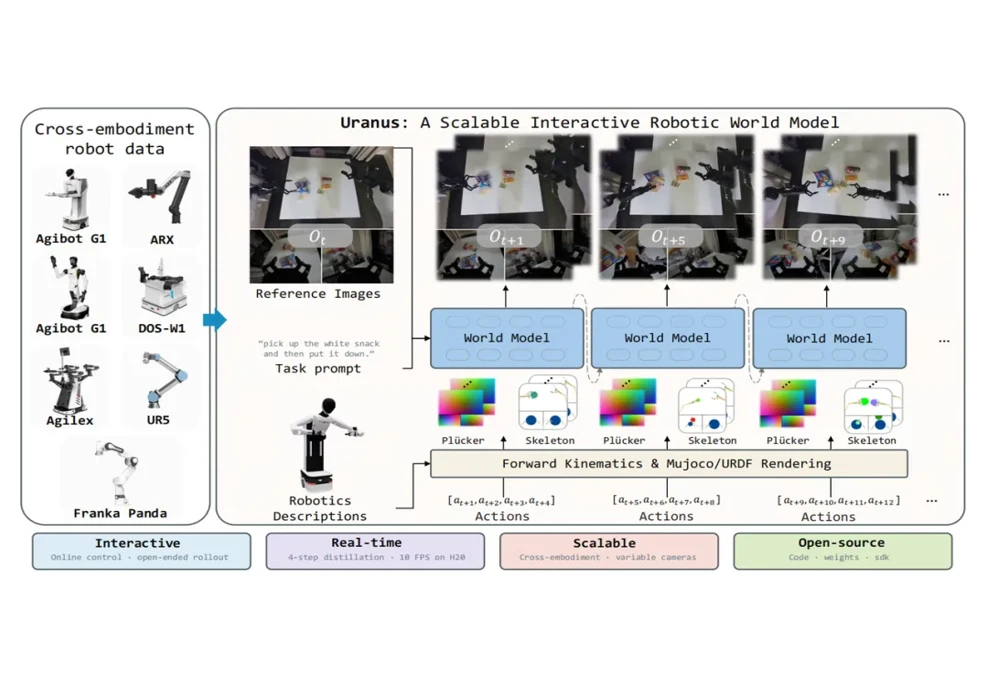
D-Robotics Open-Sources Uranus World Model Simulation Platform, Achieving 0.98 Correlation in RoboTwin Closed-Loop Evaluation
On October 27, the D-Robotics large model team open-sourced the Uranus technical report alongside its inference code, SDK, and model weights, offering 100 early access slots to developers and researchers worldwide.
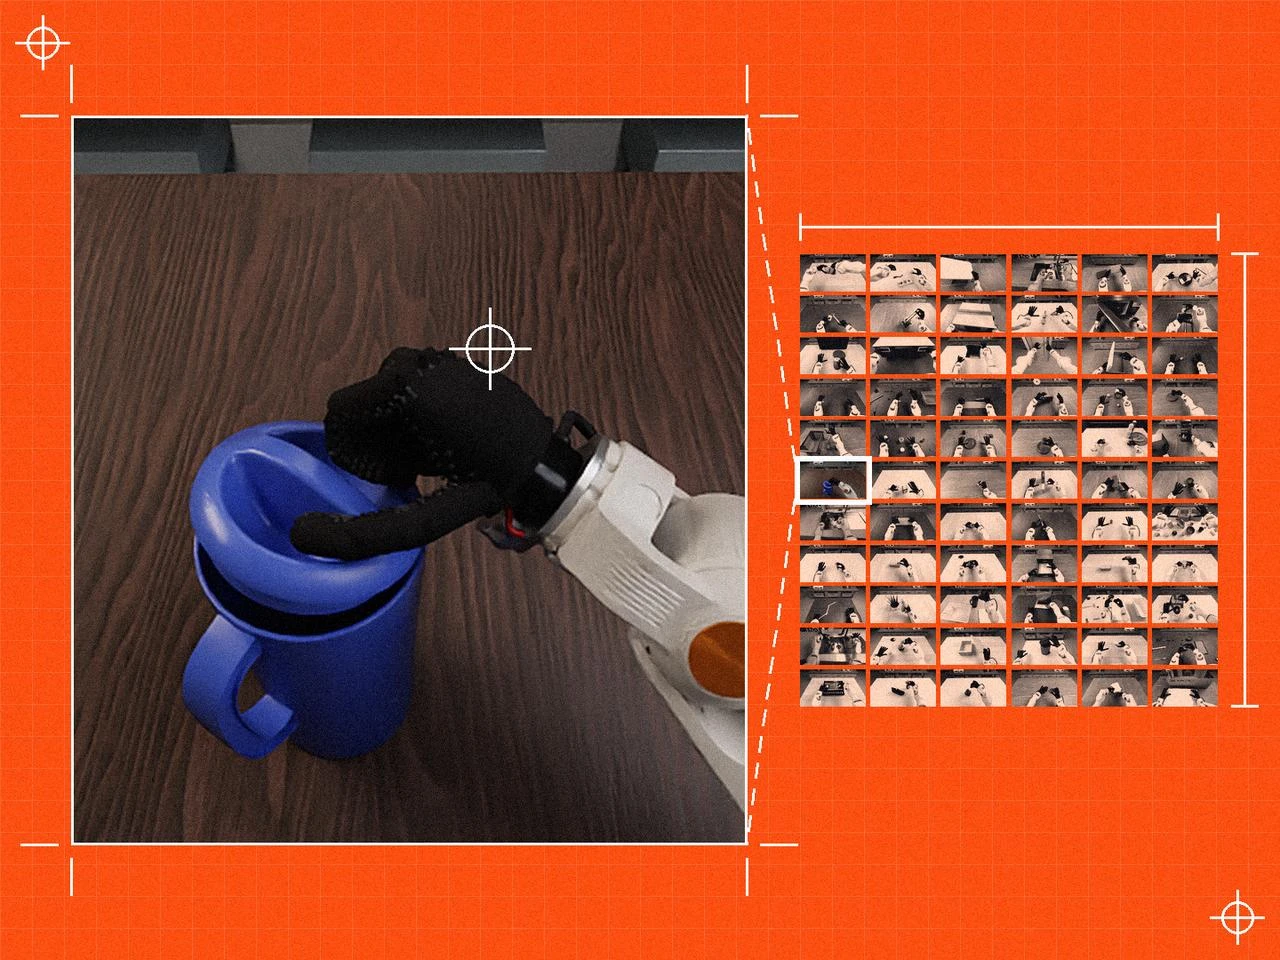
Tsinghua University Releases HandsOn Simulation Benchmark for Dexterous Manipulation with 18,000 Demonstrations
Most mainstream robot manipulation benchmarks focus on two-finger grippers, leaving five-finger dexterous hands under-evaluated with inconsistent metrics. To address this, researchers from Tsinghua University, Beijing University of Posts and Telecommunications, Natural Will, and Peking University have introduced HandsOn, a large-scale simulation benchmark featuring 66 tasks and 18,000 human teleoperation demonstrations.
Shihang Intelligence's CEORION Marine Foundation Model Completes CAC Filing for Underwater Operations
Shihang Intelligence announced that its CEORION marine general foundation model has completed filing with the Cyberspace Administration of China. Built on a Language-World-Action Model architecture, the system integrates multimodal sensor data to enable underwater robots to perceive, plan, and execute tasks within a single framework.
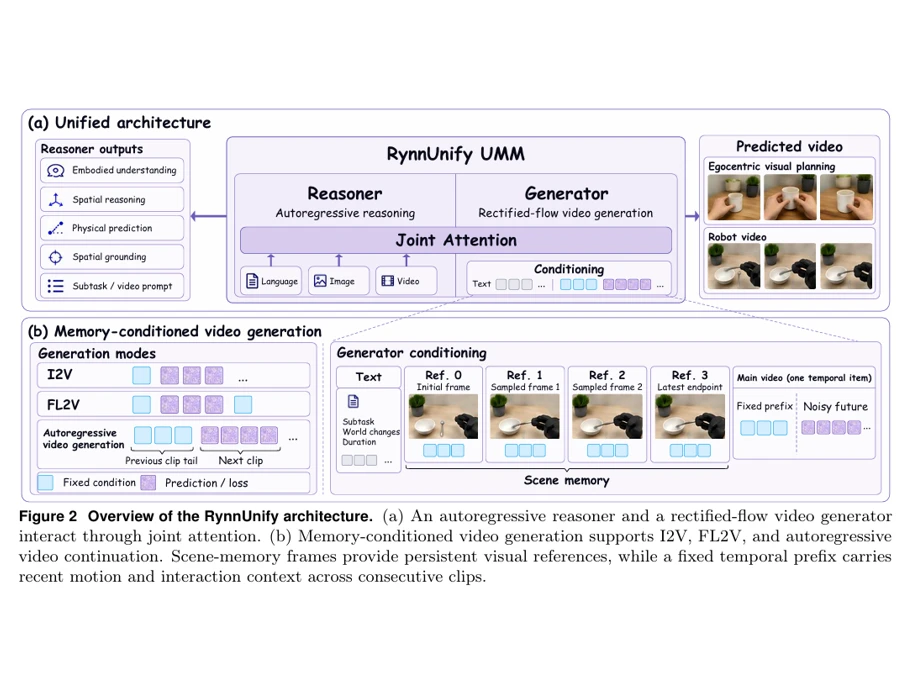
Alibaba DAMO Academy Introduces RynnUnify, a 16B Unified Embodied Model Pairing 8B Reasoning with 8B Video Generation
On October 23, Alibaba DAMO Academy and Hupan Lab published a paper on RynnUnify, a 16-billion-parameter unified embodied model that uses an 8B reasoning module and an 8B video generator to predict future scene changes and guide sequential robotic actions.

Nature Will Debuts Natura-1, a 50B-Parameter Embodied Foundation Model Trained on One Million Hours of Human Experience
On October 13, Nature Will—founded by Ding Ning, assistant professor and doctoral supervisor at Tsinghua University's Department of Electronic Engineering—released Natura-1, its first general-purpose embodied foundation model, along with a technical report. The 50-billion-parameter mixture-of-experts model was pretrained on more than one million hours of first-person human video and can drive a 20-DOF dexterous hand within a 100-millisecond control loop.
RoboMIND Open-Source Dataset Surpasses 50 Million Downloads, Latest 10 Million Reached in 18 Days
The Beijing Humanoid Robot Innovation Center announced on October 26 that the open-source dataset RoboMIND has exceeded 50 million global downloads. The latest 10 million downloads were achieved in just 18 days, accelerating significantly from the 223 days required for the first 10 million and 39 days for the second.
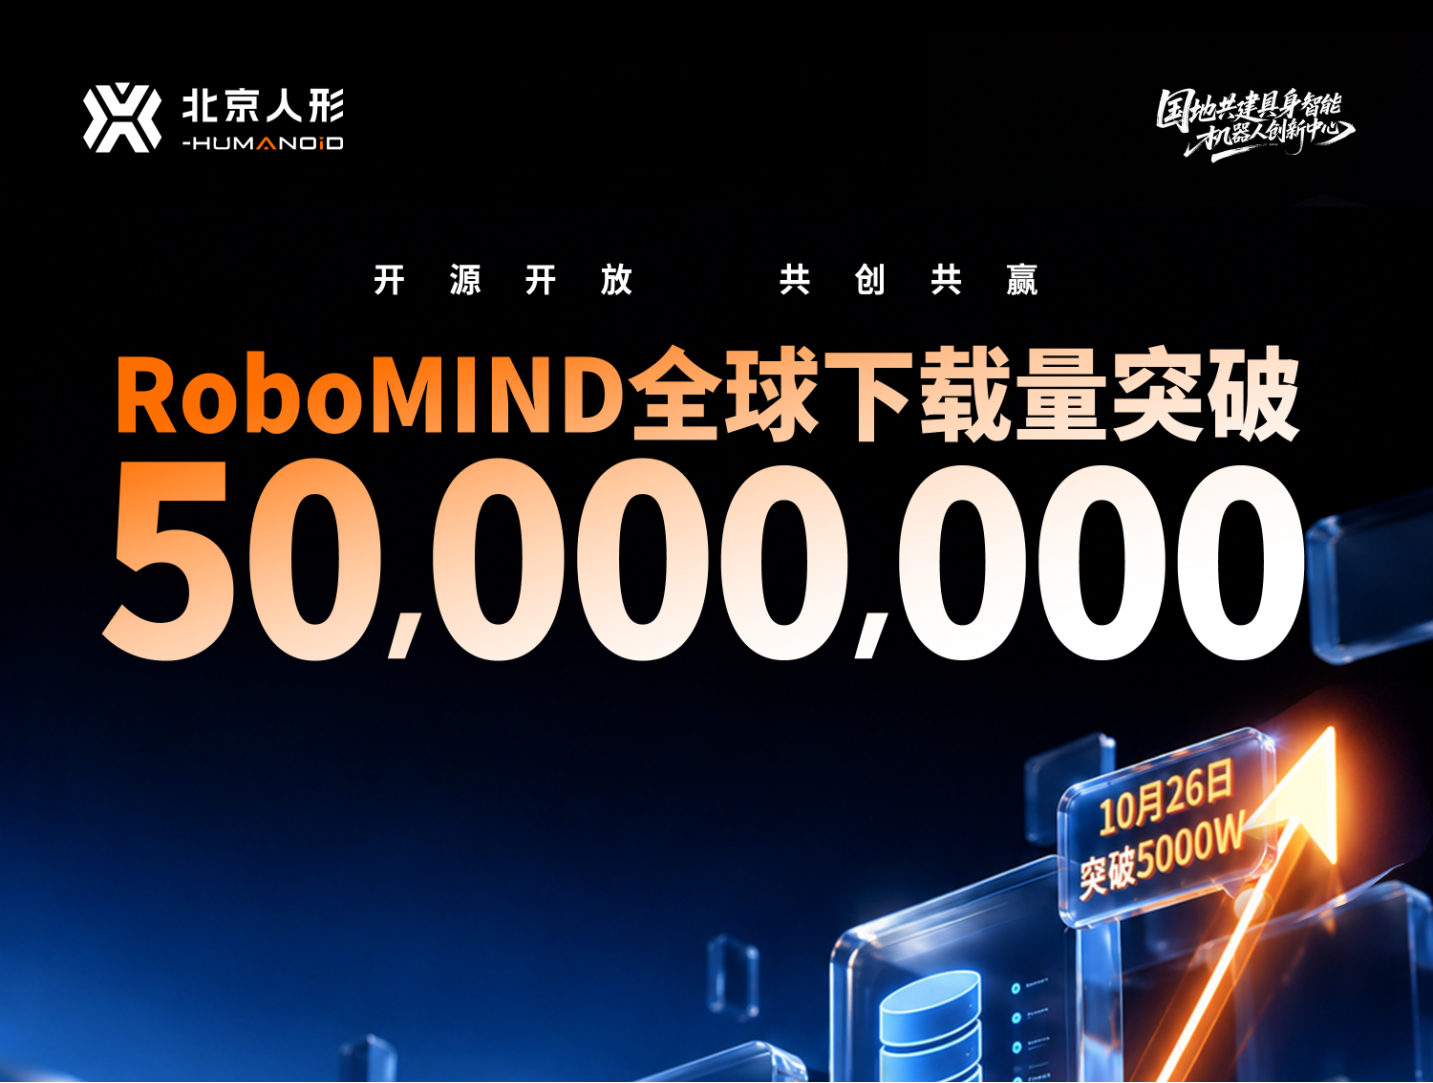
RoboMIND Downloads Surpass 50 Million, With the Latest 10 Million Achieved in Just 18 Days
The Beijing Innovation Center of Humanoid Robotics announced that its open-source dataset, RoboMIND, has exceeded 50 million global downloads. The latest 10 million downloads were achieved in just 18 days, reflecting rapid adoption as the dataset expands to over 400,000 trajectories.
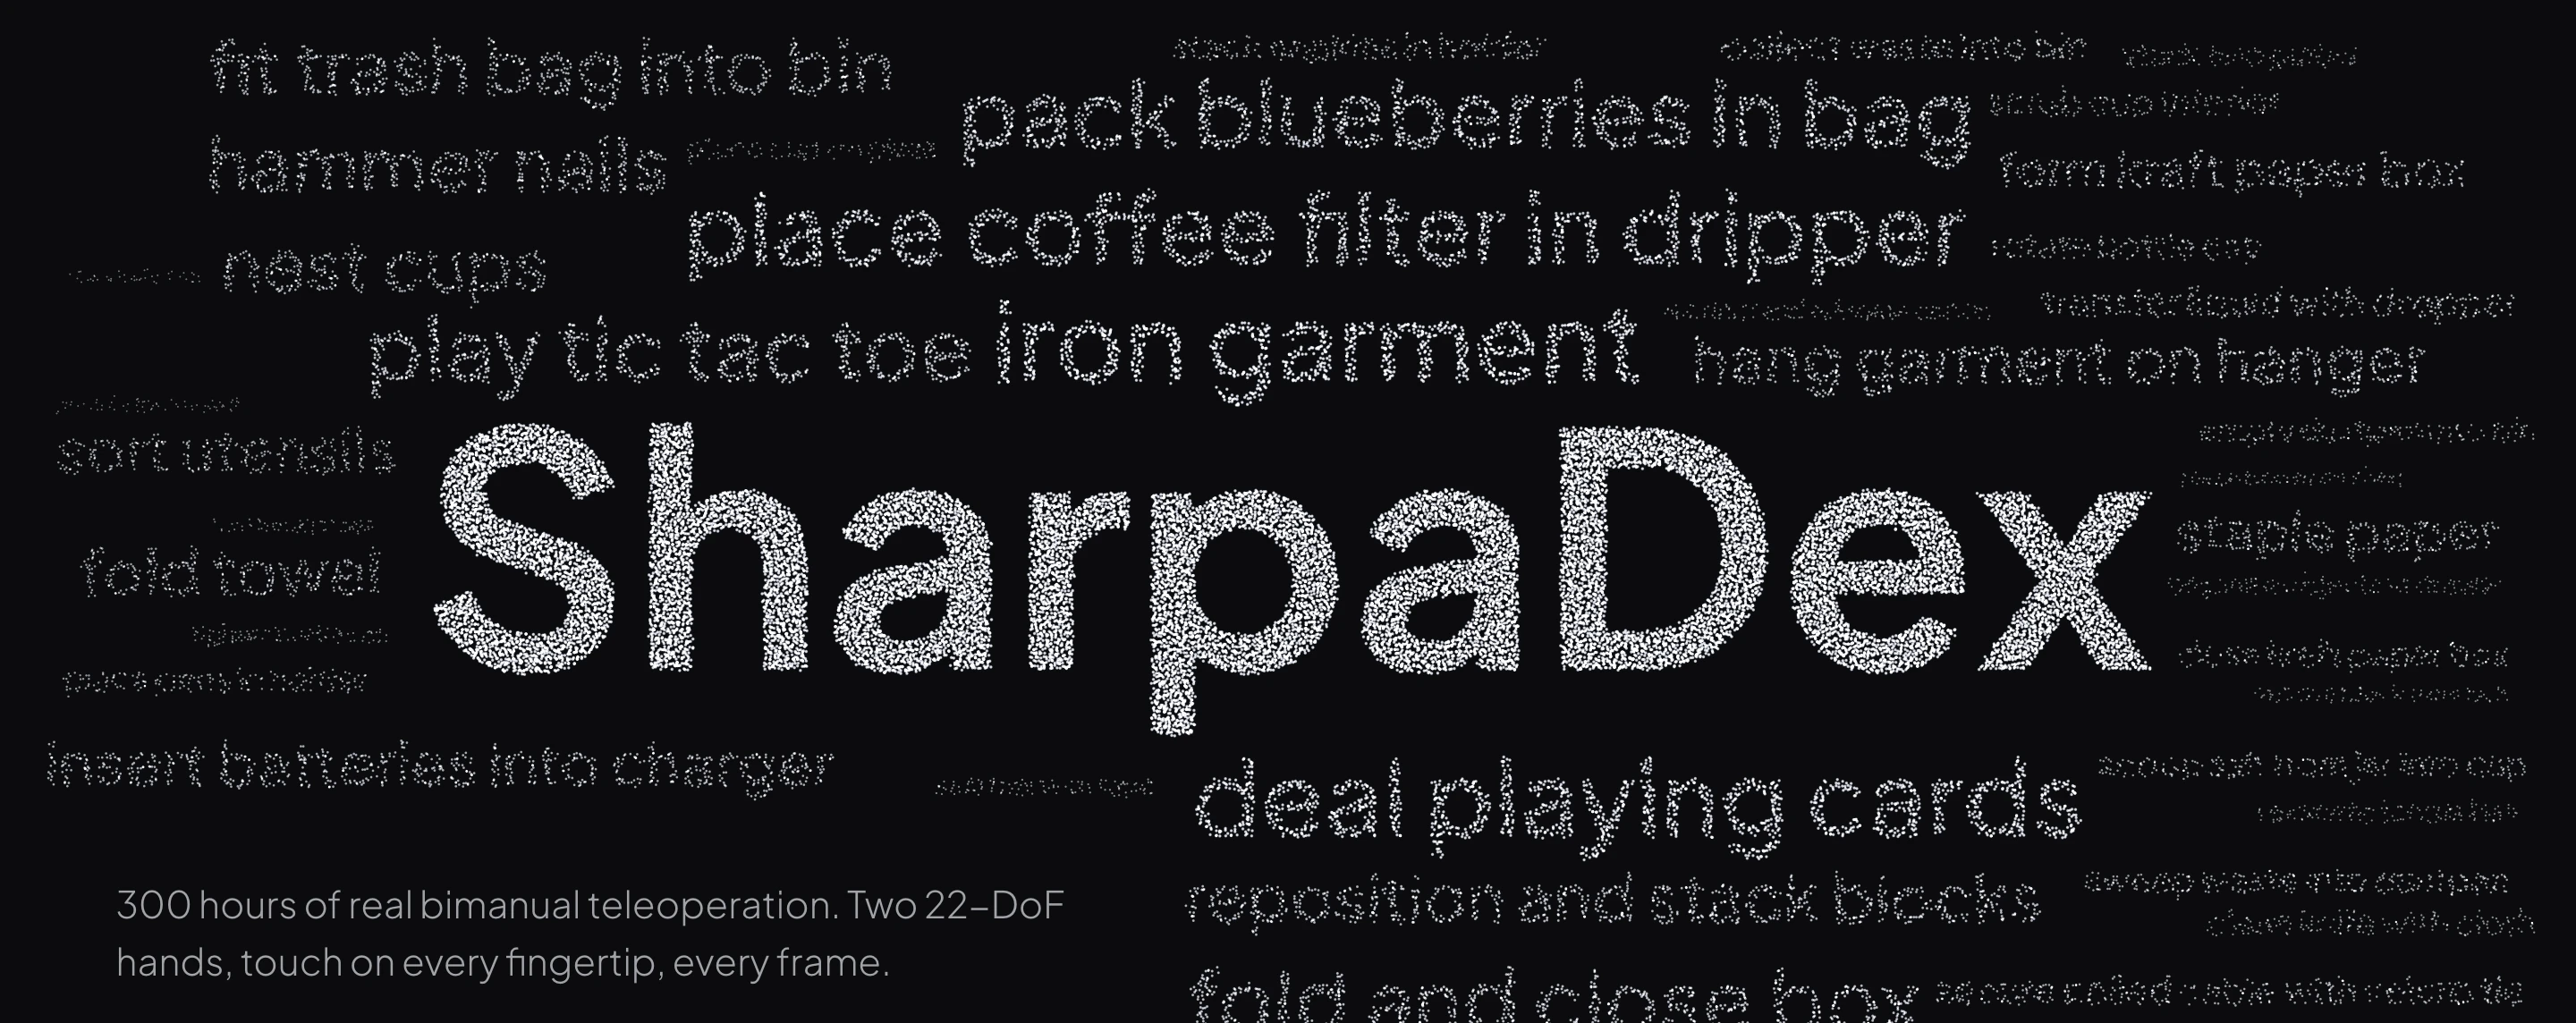
Sharpa Open-Sources SharpaDex v1.0 Dataset Featuring Approximately 300 Hours of Real-World Tactile Manipulation Data Across 59 Tasks
On October 22, Sharpa open-sourced the SharpaDex v1.0 dexterous manipulation dataset. The dataset comprises approximately 300 hours of real-robot manipulation data, 28,993 demonstrations, and 32,396,172 frames, covering 59 manipulation tasks.