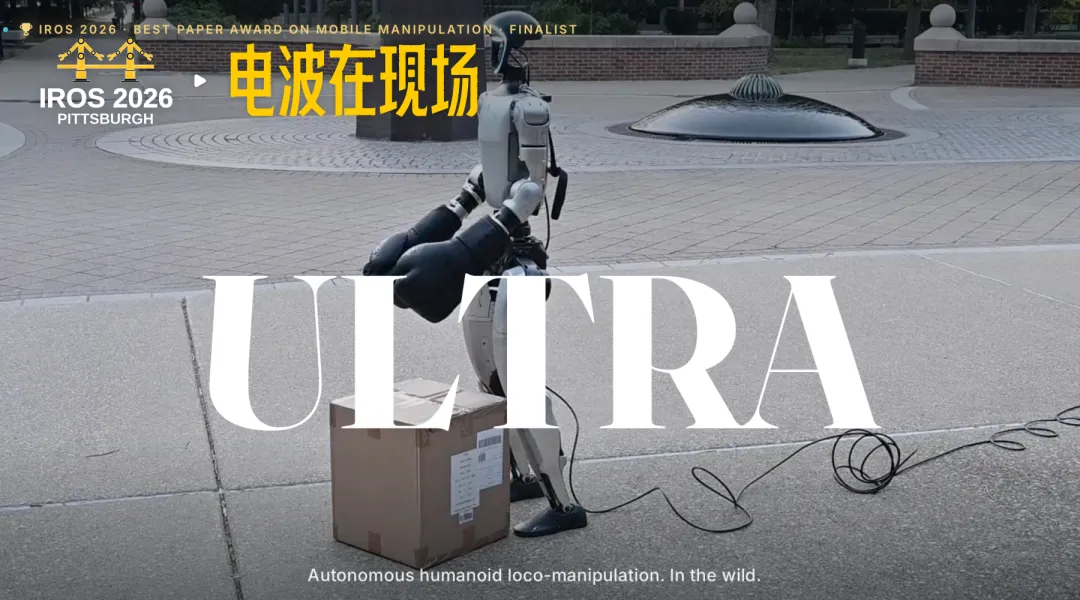
ULTRA: Toward Autonomous Whole-Body Movement and Manipulation
At IROS 2026, Xialin He and Sirui Xu from UIUC presented ULTRA, a unified multimodal control framework that enables humanoid robots to learn whole-body loco-manipulation through physical simulation and reinforcement learning.