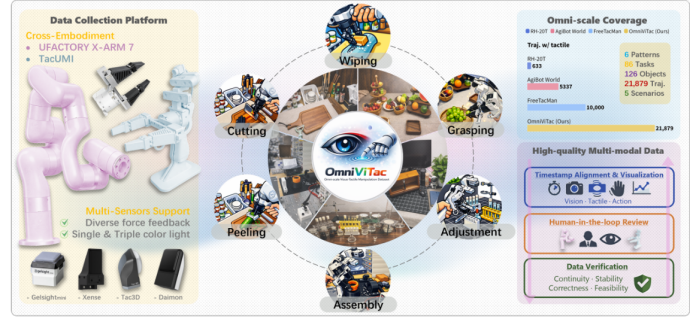
TARS together with Six Institutions Unveil OmniVTA Tactile-Visual World Model
TARS, in collaboration with six institutions including NUS and Tsinghua University, releases the OmniVTA framework and OmniViTac dataset, enabling robots to transition from passive perception to active tactile prediction and closed-loop control for dexterous manipulation.