

Dexterous Manipulation
4 related stories
Sharpa Open-Sources SharpaDex v1.0 Dataset Featuring Approximately 300 Hours of Real-World Tactile Manipulation Data Across 59 Tasks
On October 22, Sharpa open-sourced the SharpaDex v1.0 dexterous manipulation dataset. The dataset comprises approximately 300 hours of real-robot manipulation data, 28,993 demonstrations, and 32,396,172 frames, covering 59 manipulation tasks.
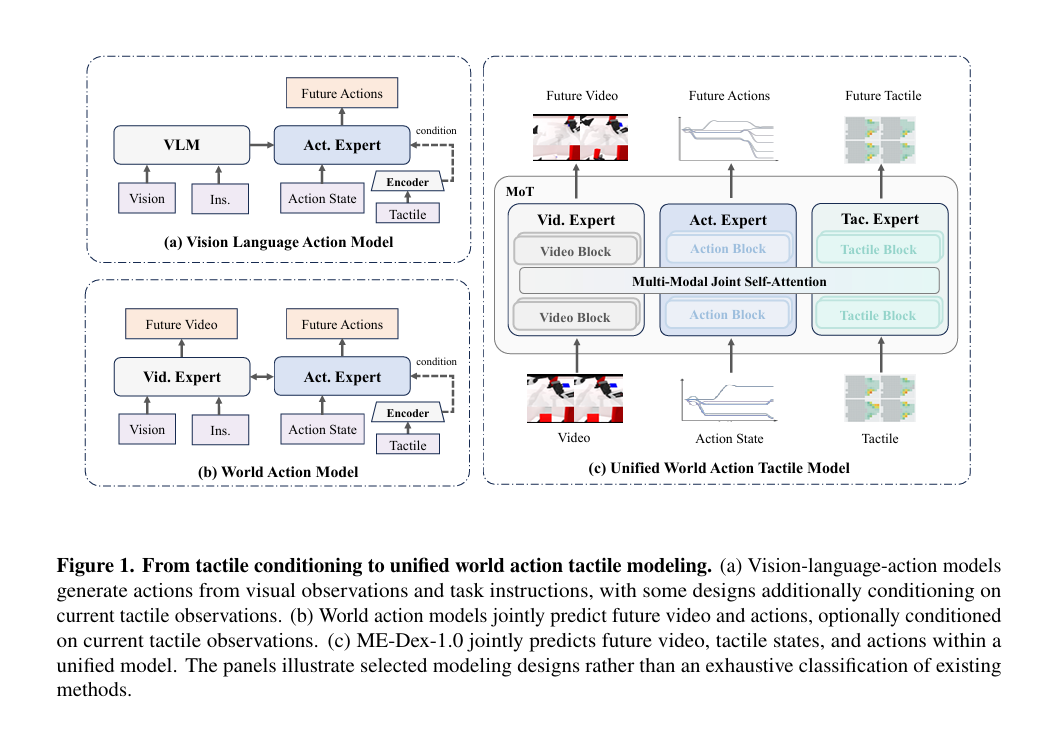
Li Auto's ME-Dex 1.0 Predicts Future Tactile States Alongside Visual Observations
Li Auto’s foundation model team released ME-Dex 1.0, a world action model that treats tactile sensing as a parallel prediction target to video. By aligning heterogeneous tactile data from five different hands into a unified representation, the system significantly improves success rates in high-contact dexterous manipulation tasks.
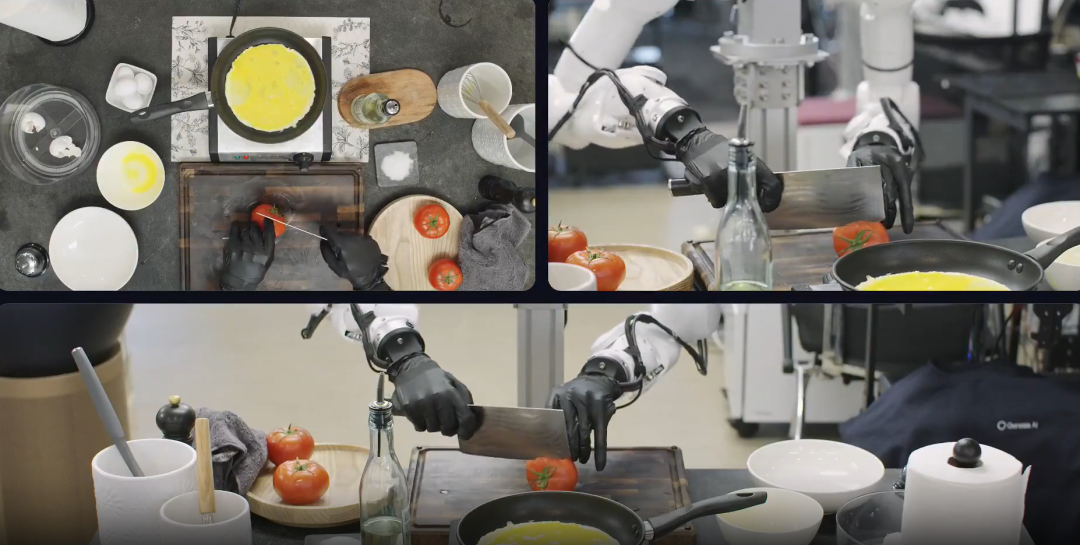
Genesis AI Unveils GENE-26.5, a Full-Stack Embodied AI System for Dexterous Manipulation
Genesis AI releases GENE-26.5, a full-stack Embodied AI system enabling robots to perform complex dexterous tasks like cooking and piano playing, proving that hardware and control systems are as critical as the model itself.
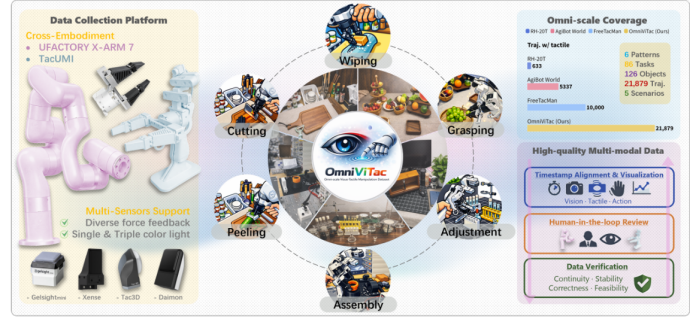
TARS together with Six Institutions Unveil OmniVTA Tactile-Visual World Model
TARS, in collaboration with six institutions including NUS and Tsinghua University, releases the OmniVTA framework and OmniViTac dataset, enabling robots to transition from passive perception to active tactile prediction and closed-loop control for dexterous manipulation.