

Data
8 related stories
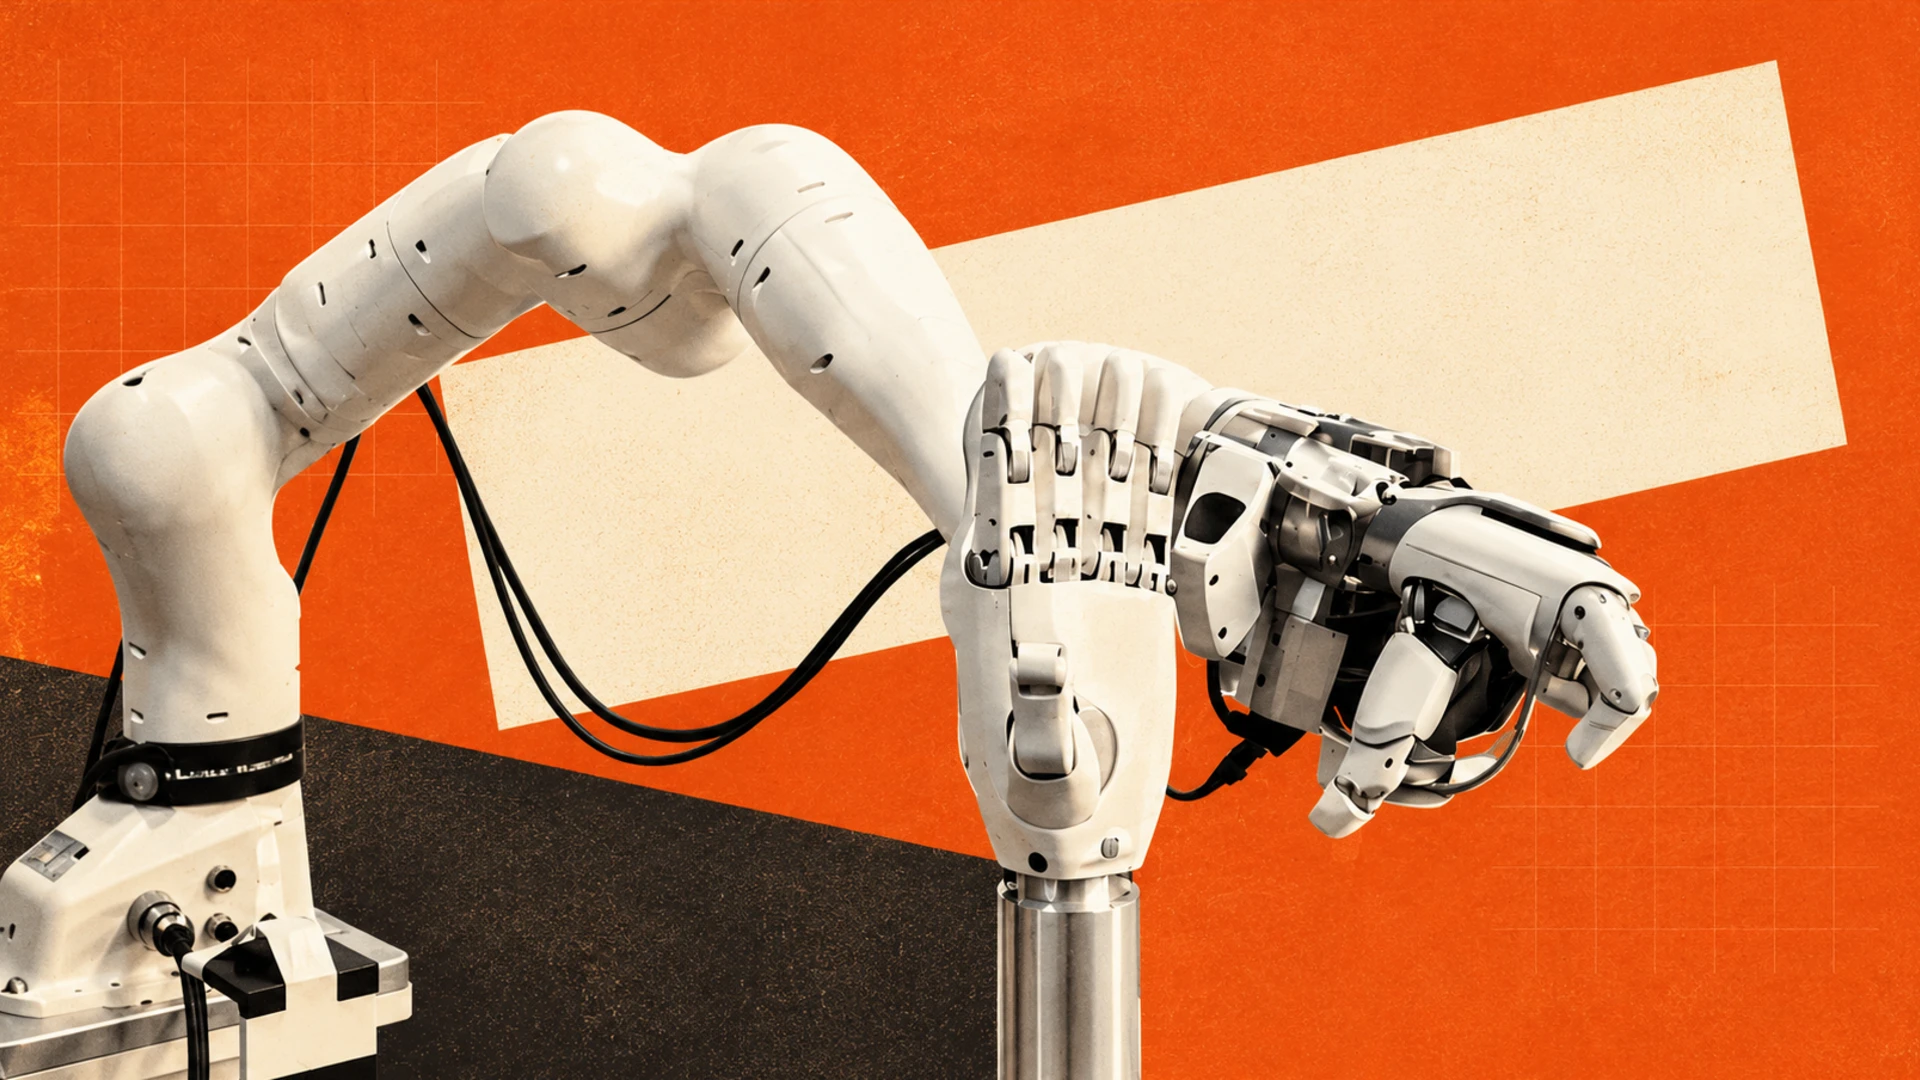
AGILINK Cuts Dexterous Hand Failure Rate to 0.5% for Industrial Deployment
At AgiBot's Innovation Day on October 29, AGILINK demonstrated a production testing station via a cross-city link, where a dexterous hand used a screw gun to test another unit awaiting factory release. At the company's joint manufacturing base with Wolong in Shaoxing, the robot executes 72 operational steps, including material loading, barcode scanning, clamping, screw tightening, equipment activation, and unloading.

Nature Will Debuts Natura-1, a 50B-Parameter Embodied Foundation Model Trained on One Million Hours of Human Experience
On October 13, Nature Will—founded by Ding Ning, assistant professor and doctoral supervisor at Tsinghua University's Department of Electronic Engineering—released Natura-1, its first general-purpose embodied foundation model, along with a technical report. The 50-billion-parameter mixture-of-experts model was pretrained on more than one million hours of first-person human video and can drive a 20-DOF dexterous hand within a 100-millisecond control loop.
RoboMIND Open-Source Dataset Surpasses 50 Million Downloads, Latest 10 Million Reached in 18 Days
The Beijing Humanoid Robot Innovation Center announced on October 26 that the open-source dataset RoboMIND has exceeded 50 million global downloads. The latest 10 million downloads were achieved in just 18 days, accelerating significantly from the 223 days required for the first 10 million and 39 days for the second.
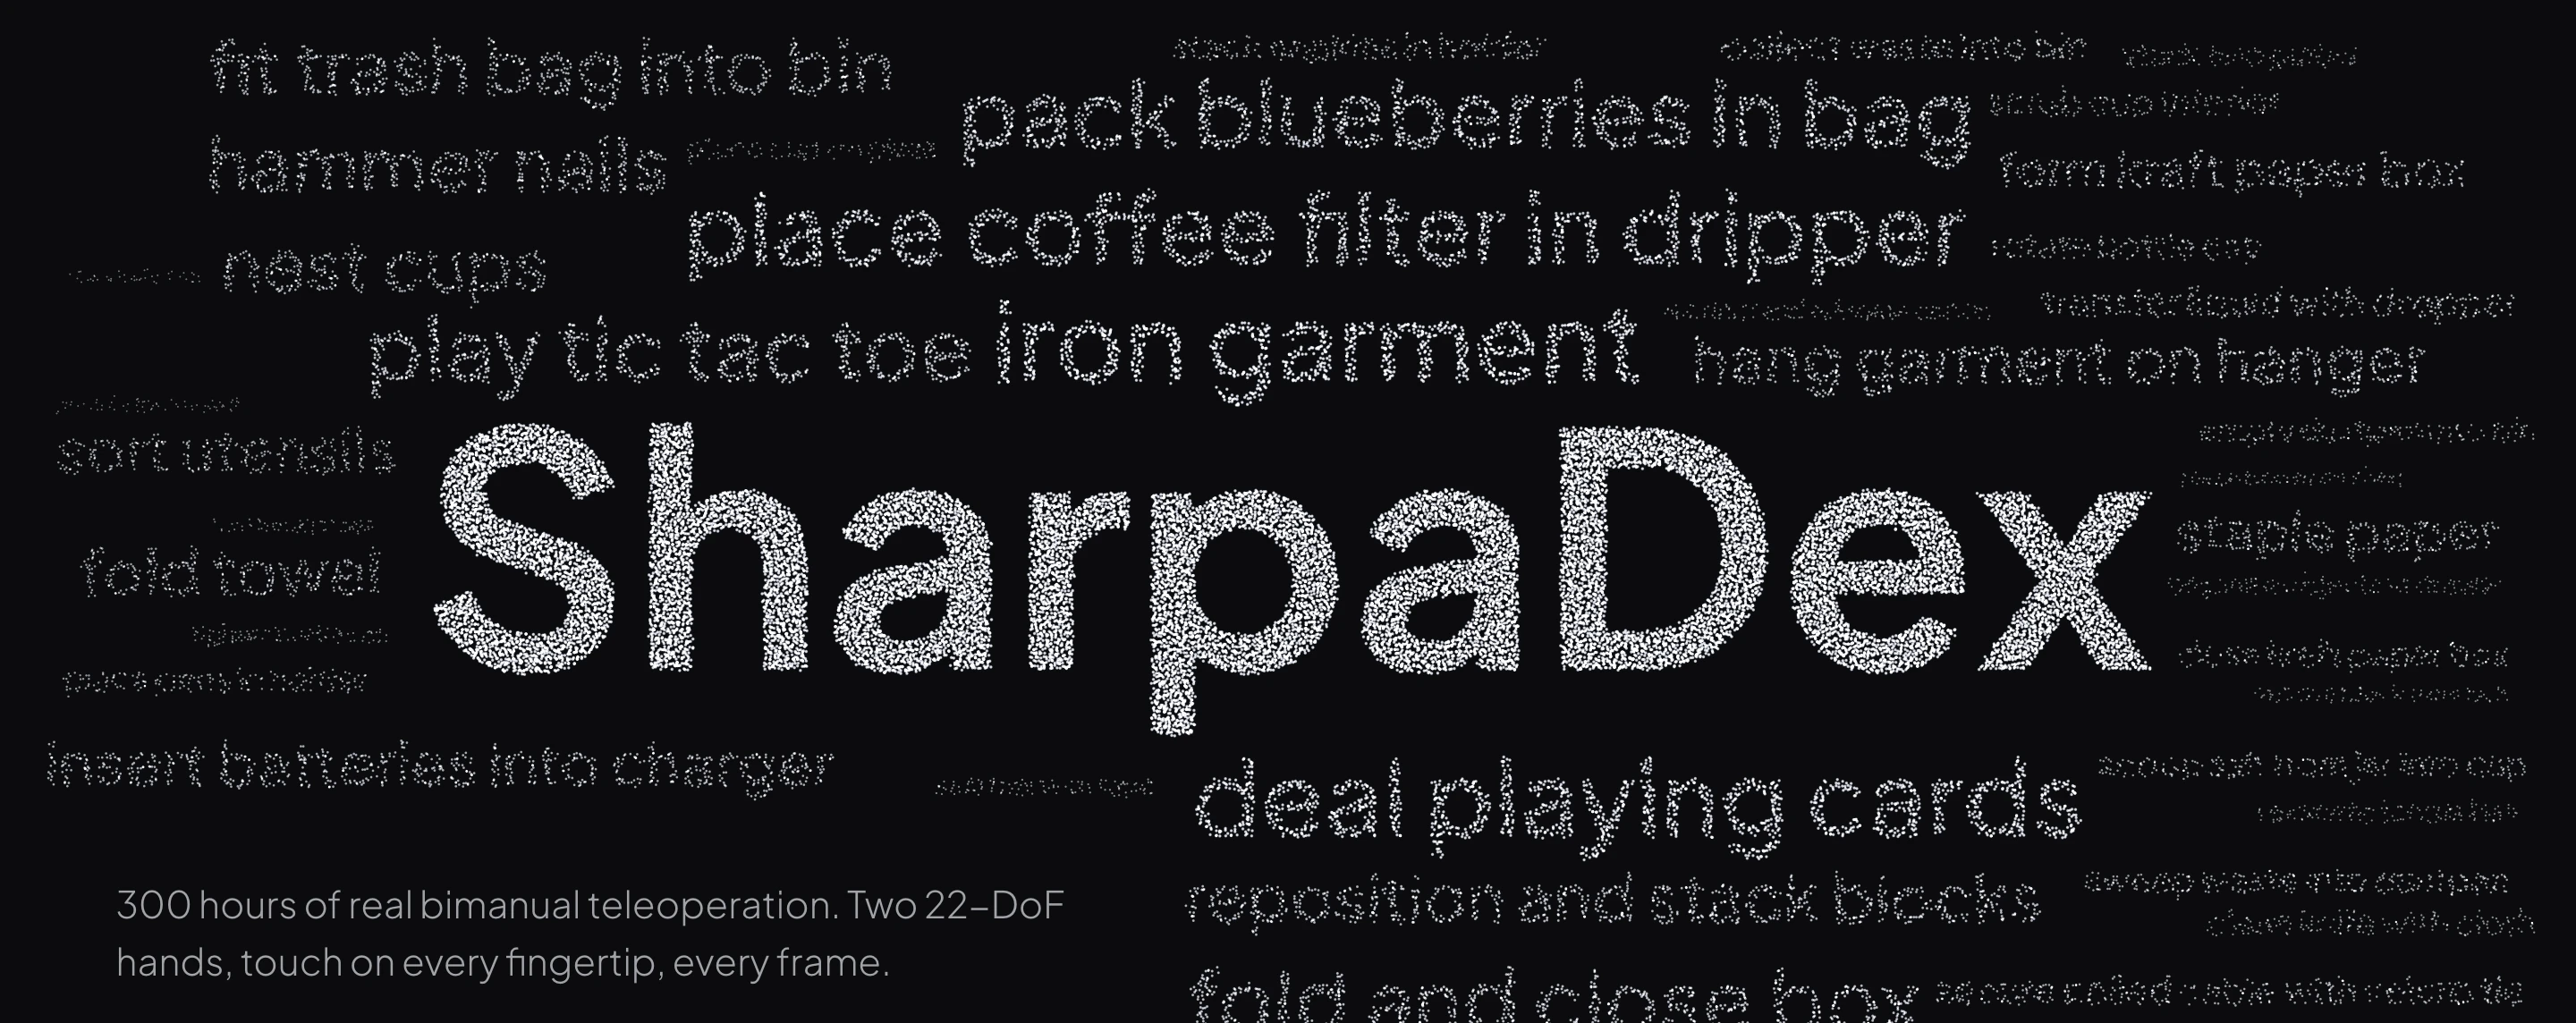
Sharpa Open-Sources SharpaDex v1.0 Dataset Featuring Approximately 300 Hours of Real-World Tactile Manipulation Data Across 59 Tasks
On October 22, Sharpa open-sourced the SharpaDex v1.0 dexterous manipulation dataset. The dataset comprises approximately 300 hours of real-robot manipulation data, 28,993 demonstrations, and 32,396,172 frames, covering 59 manipulation tasks.
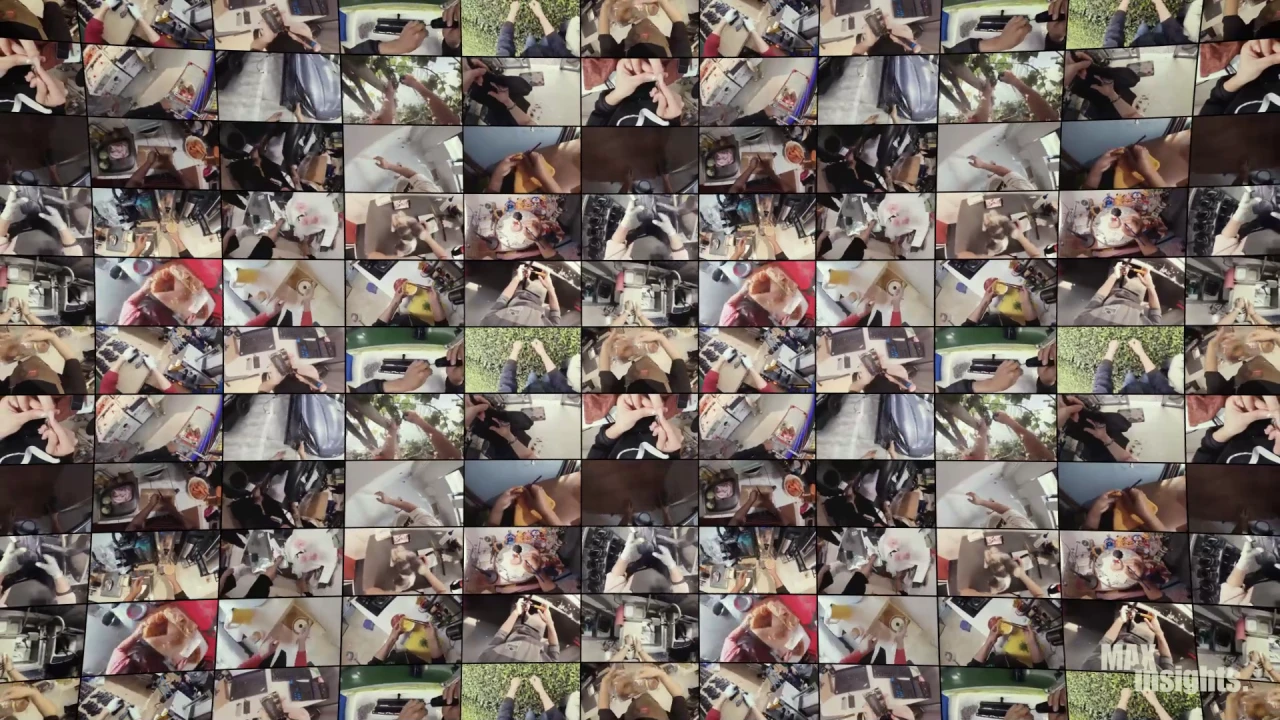
Maxinsights Raises $30 Million Seed Round Led by Peak XV to Scale Robot Training Data
On October 22, Santa Clara-based Maxinsights closed a $30 million seed round led by Peak XV, with participation from Tola Capital, South Park Commons, Yince Capital, and Alumni Ventures, to scale its pipeline of real-world human demonstration data for robot training.
 1:52
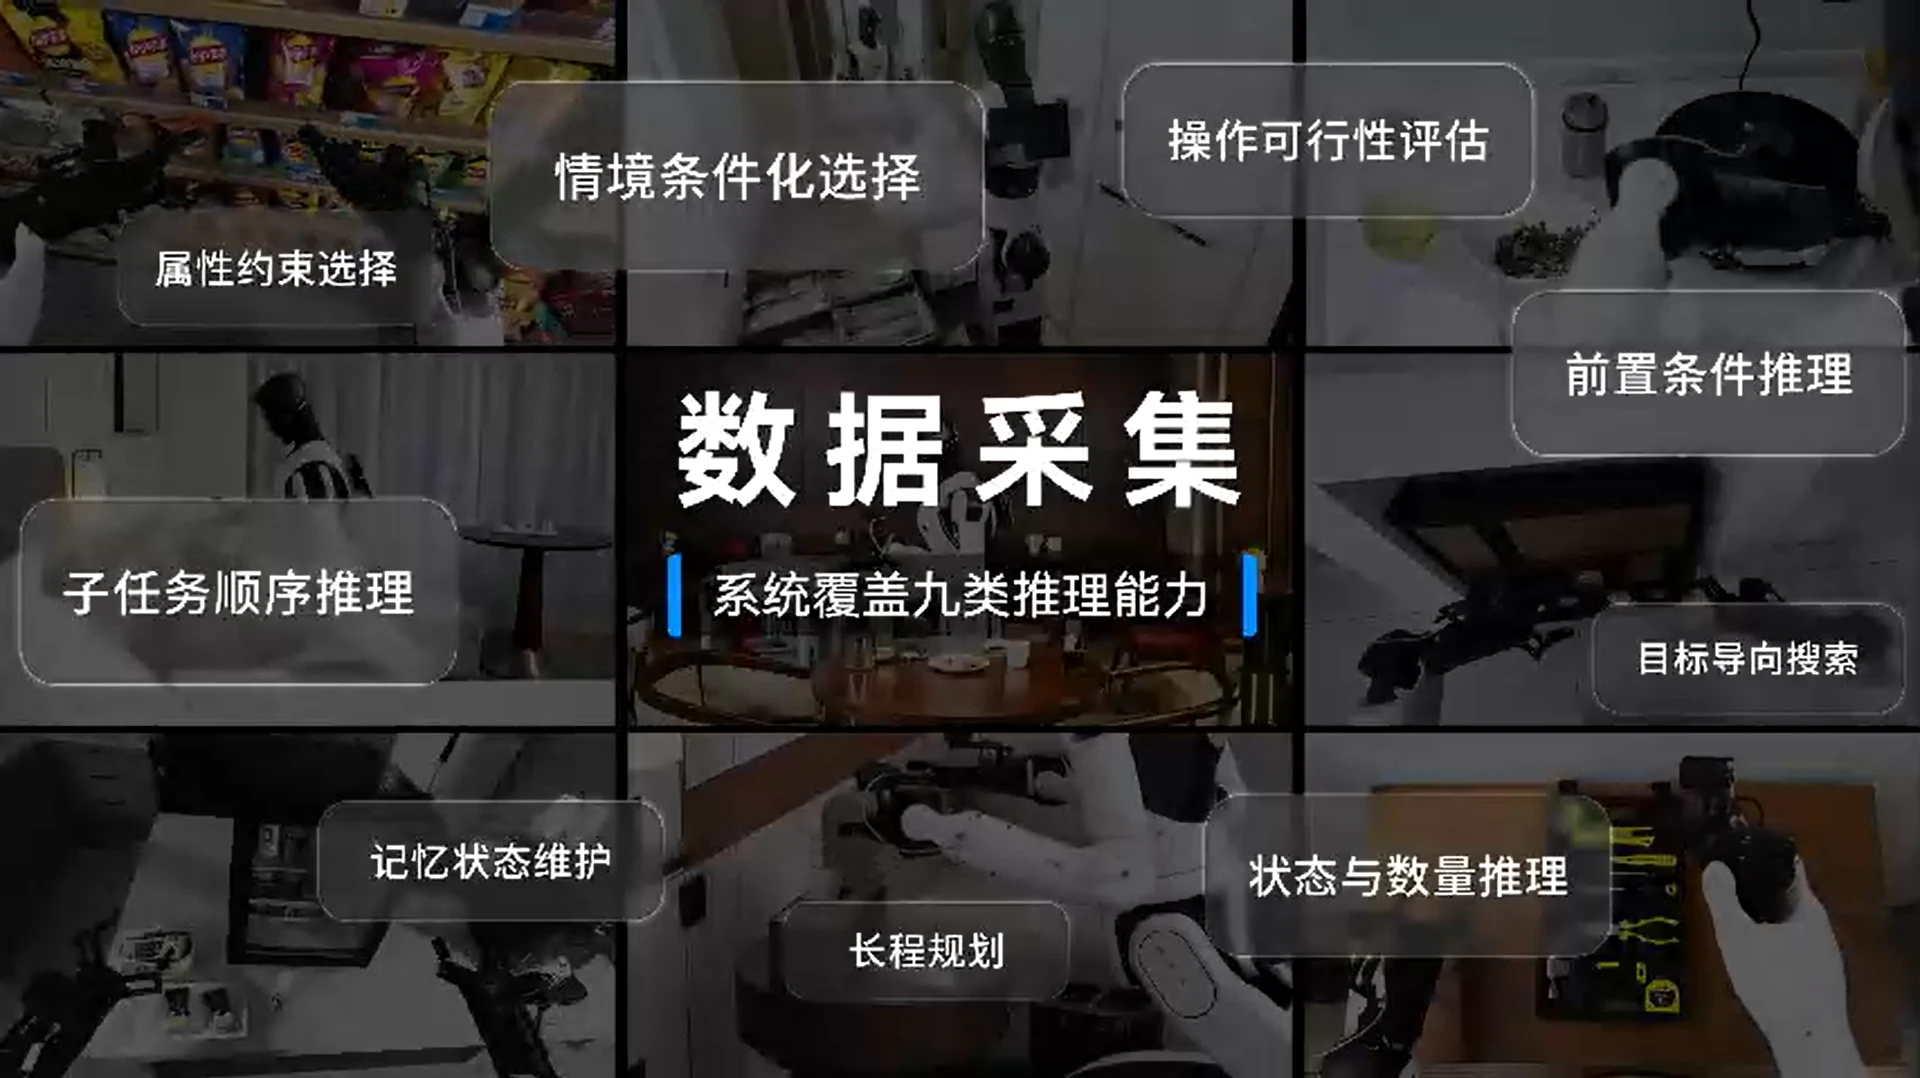
AgiBot Open-Sources AGIBOT WORLD 2026 Embodied Reasoning Dataset Covering Nine Scenarios
On October 22, AgiBot open-sourced the fourth installment of the AGIBOT WORLD 2026 dataset, focusing on embodied reasoning as the first release in its AI WAVE series. The dataset covers nine logical reasoning scenarios and provides both high-level question answering and low-level action trajectories, enabling robots to make decisions and execute operations based on task goals, environmental conditions, and execution history.
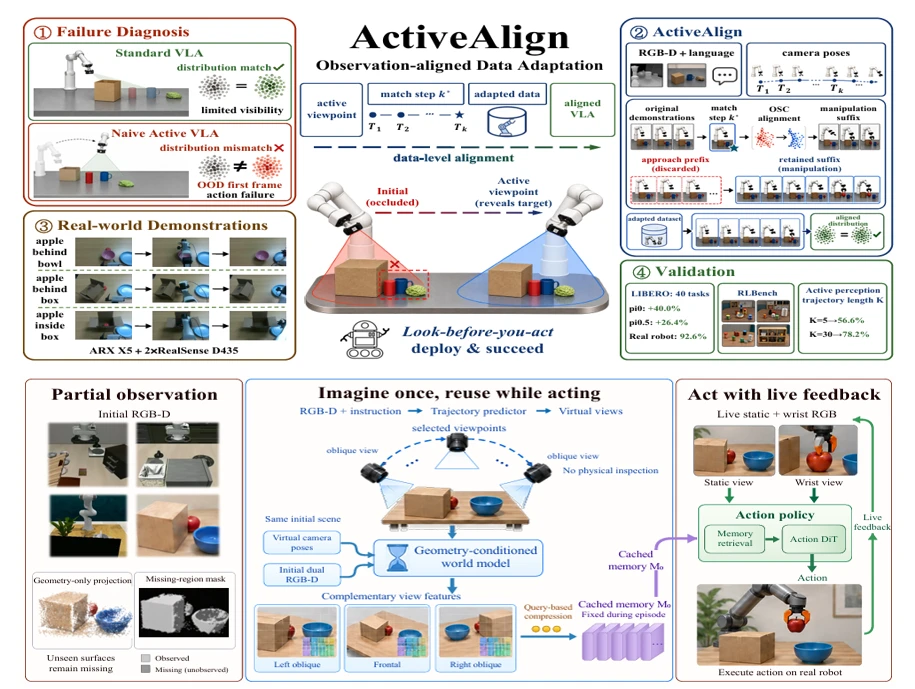
Fudan Team Bridges Active Perception and Vision-Language-Action Models to Overcome Viewpoint Shifts
Two papers from Fudan University introduce ActiveAlign and AWAM, which align training data and representations with active camera movements to prevent distribution shifts in vision-language-action models when robots adjust their viewpoints to overcome occlusions.
In Conversation with Saturday Robotics Founder Junfan Zhu: “By the Time a Robotics Paper Is Published, Its Approach May Already Be Out of Date”
How Junfan Zhu is building a cross-disciplinary robotics research community in the Bay Area while working on better ways to evaluate AI systems in the physical world, and why he thinks robotics has yet to have its benchmark moment.