

Manipulation
5 related stories
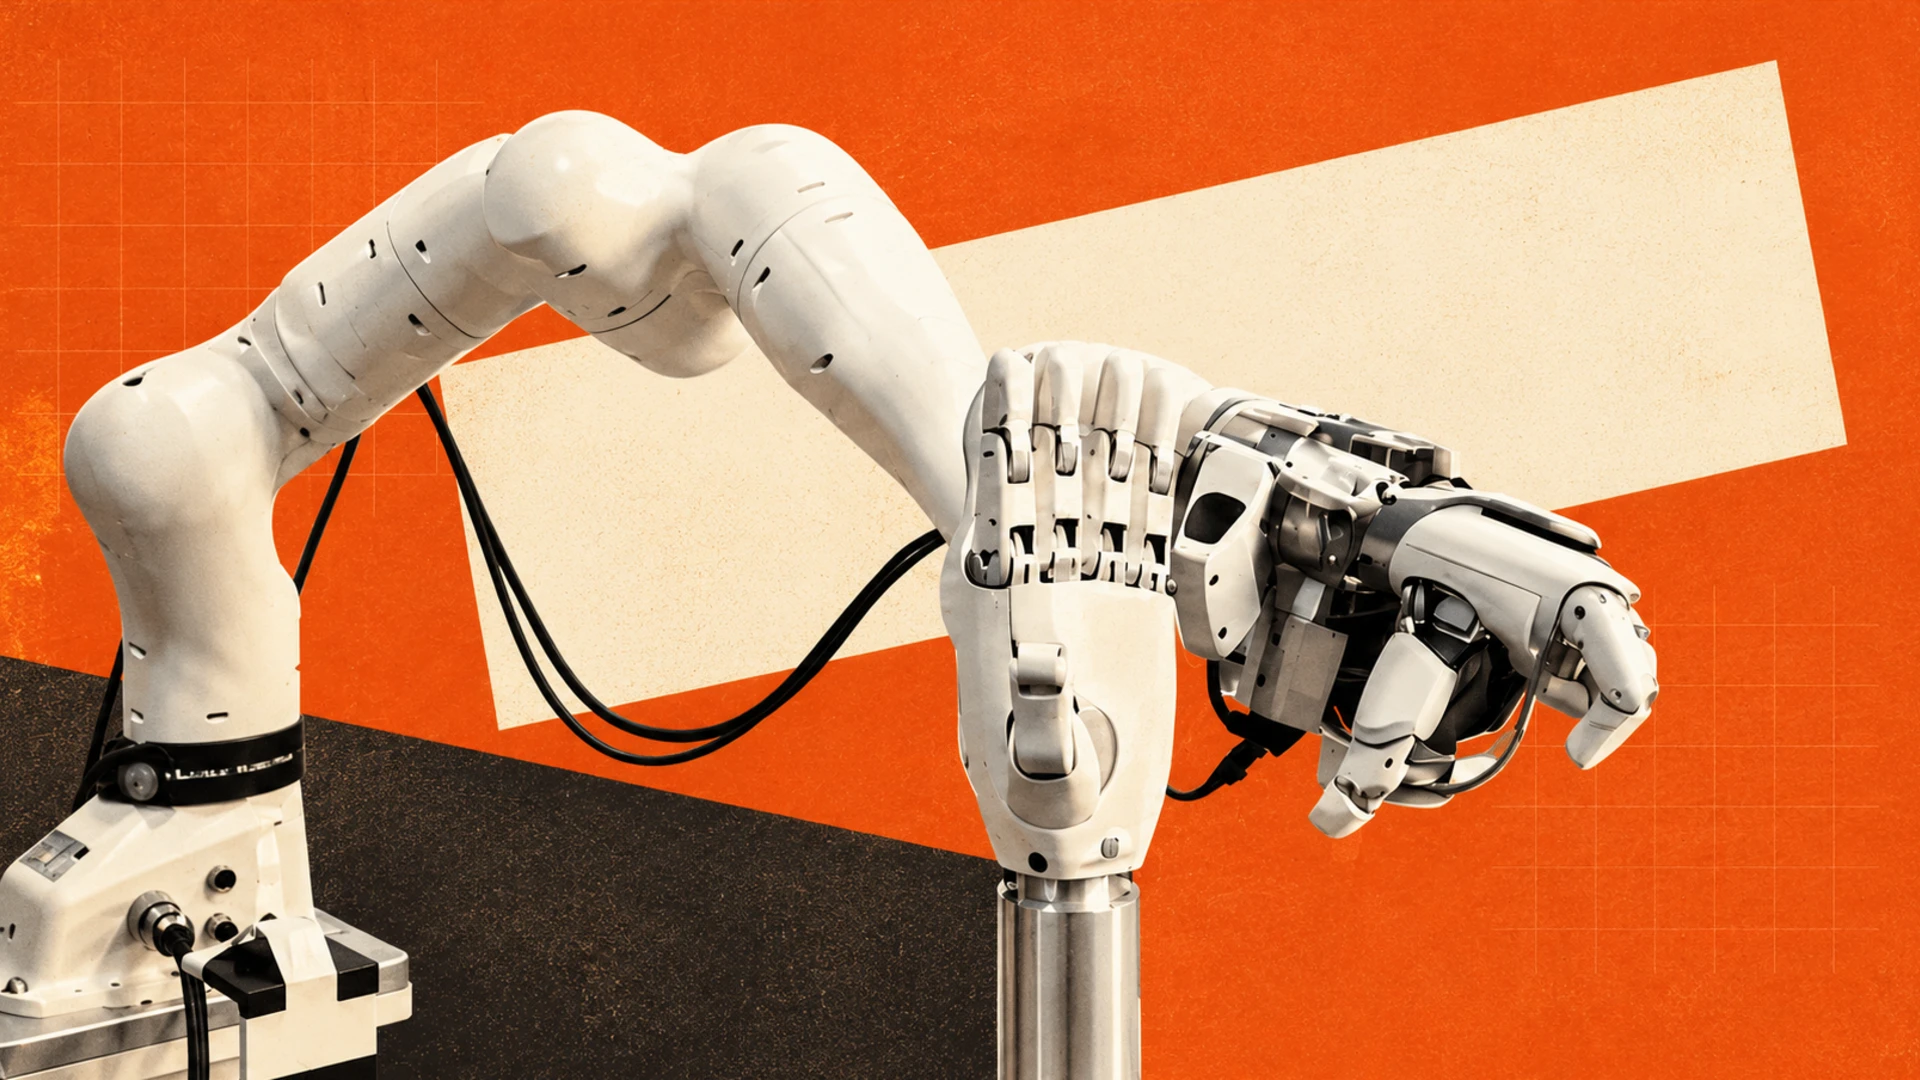
AGILINK Cuts Dexterous Hand Failure Rate to 0.5% for Industrial Deployment
At AgiBot's Innovation Day on October 29, AGILINK demonstrated a production testing station via a cross-city link, where a dexterous hand used a screw gun to test another unit awaiting factory release. At the company's joint manufacturing base with Wolong in Shaoxing, the robot executes 72 operational steps, including material loading, barcode scanning, clamping, screw tightening, equipment activation, and unloading.
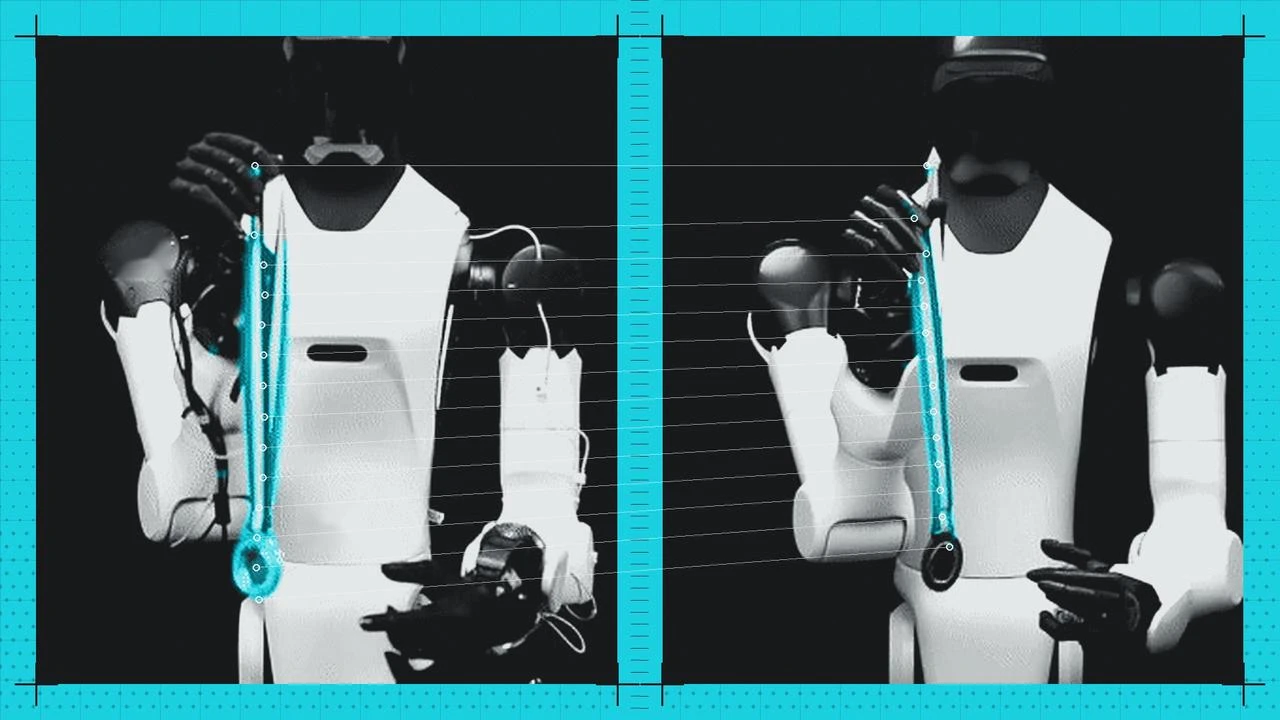
AgiBot Upgrades Genie Sim to Unify Robot Training and Evaluation via Flexible-Body Simulation
Folding a towel or tightening a drawstring bag is simple for humans but challenging for robots, as fabrics and ropes continuously deform and contact friction alters subsequent manipulation conditions. If simulation fails to replicate these dynamics, robots may perform well virtually but fail in real-world deployment.
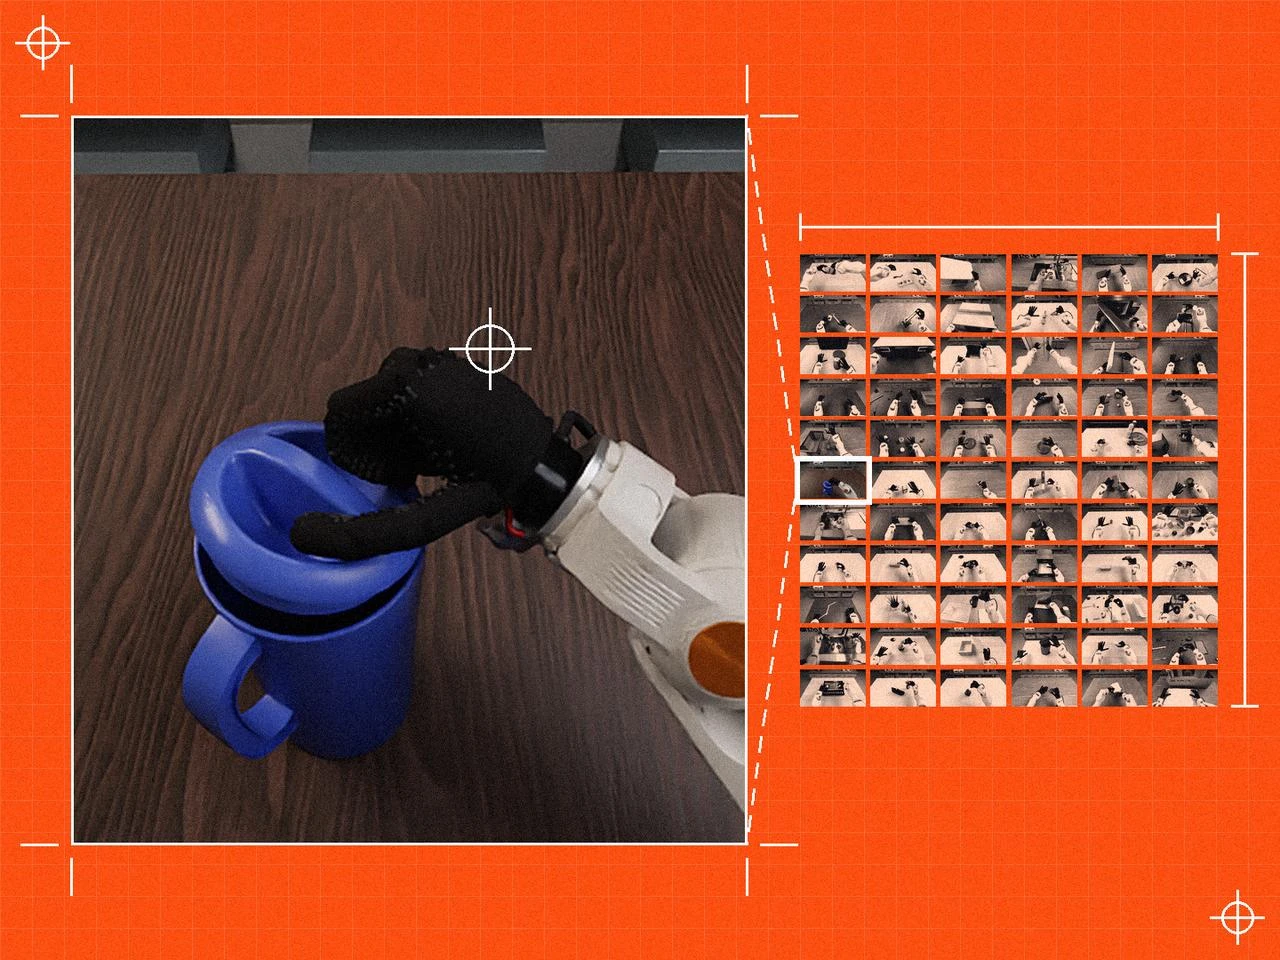
Tsinghua University Releases HandsOn Simulation Benchmark for Dexterous Manipulation with 18,000 Demonstrations
Most mainstream robot manipulation benchmarks focus on two-finger grippers, leaving five-finger dexterous hands under-evaluated with inconsistent metrics. To address this, researchers from Tsinghua University, Beijing University of Posts and Telecommunications, Natural Will, and Peking University have introduced HandsOn, a large-scale simulation benchmark featuring 66 tasks and 18,000 human teleoperation demonstrations.
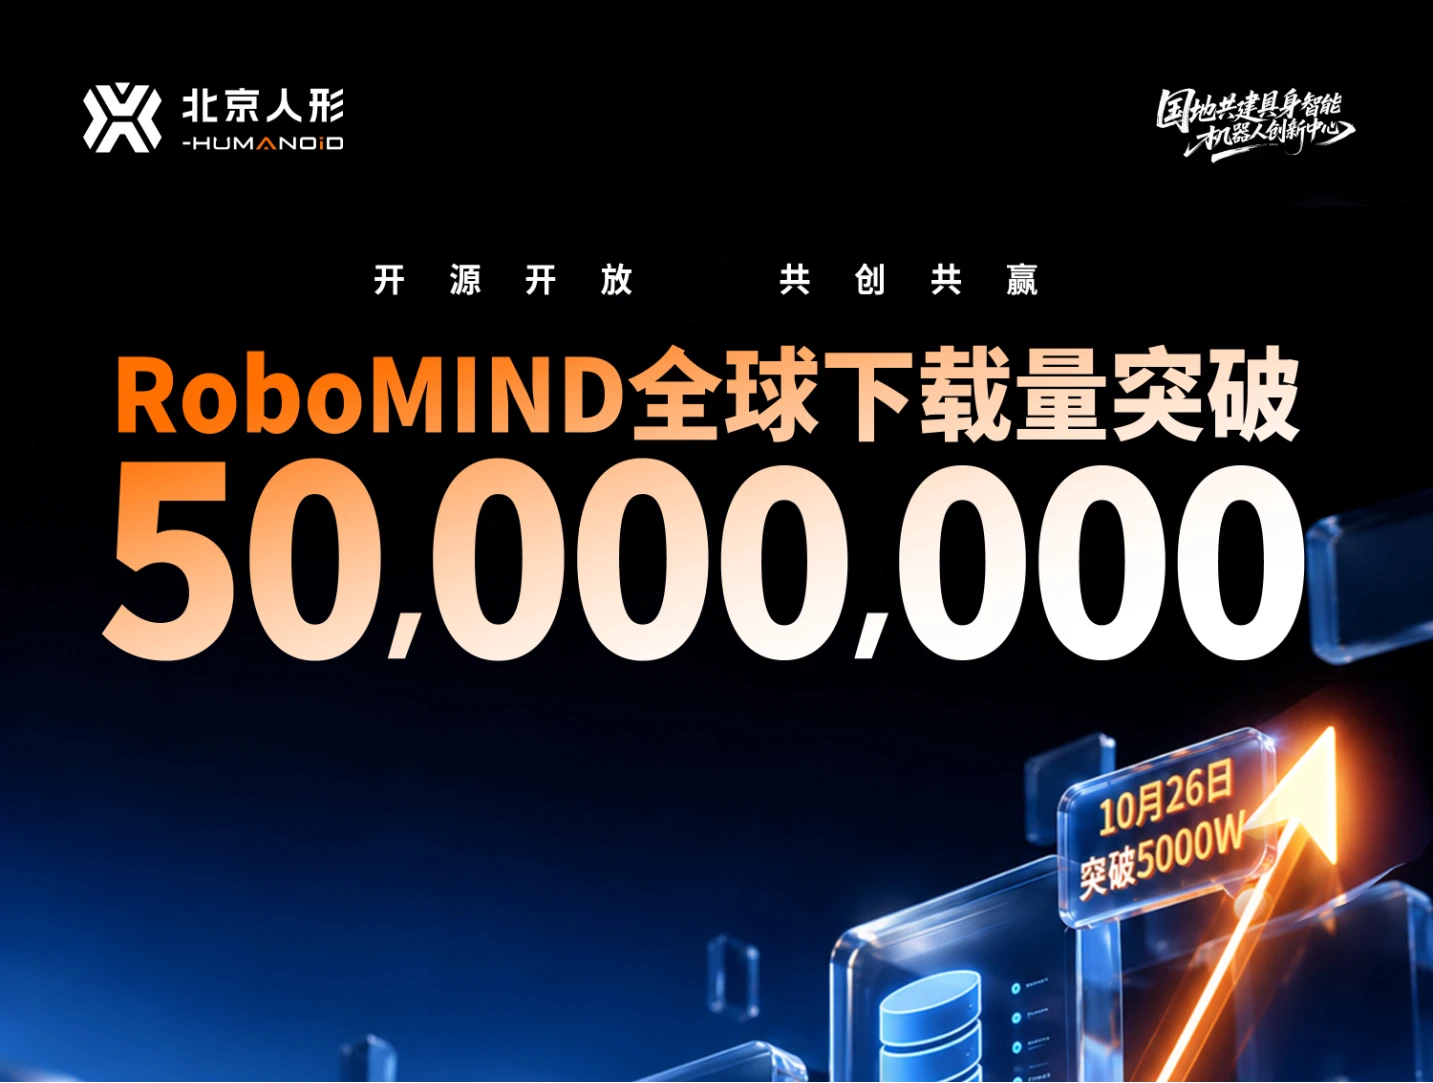
RoboMIND Open-Source Dataset Surpasses 50 Million Downloads, Latest 10 Million Reached in 18 Days
The Beijing Humanoid Robot Innovation Center announced on October 26 that the open-source dataset RoboMIND has exceeded 50 million global downloads. The latest 10 million downloads were achieved in just 18 days, accelerating significantly from the 223 days required for the first 10 million and 39 days for the second.
Sharpa Open-Sources SharpaDex v1.0 Dataset Featuring Approximately 300 Hours of Real-World Tactile Manipulation Data Across 59 Tasks
On October 22, Sharpa open-sourced the SharpaDex v1.0 dexterous manipulation dataset. The dataset comprises approximately 300 hours of real-robot manipulation data, 28,993 demonstrations, and 32,396,172 frames, covering 59 manipulation tasks.