

Simulation
3 related stories
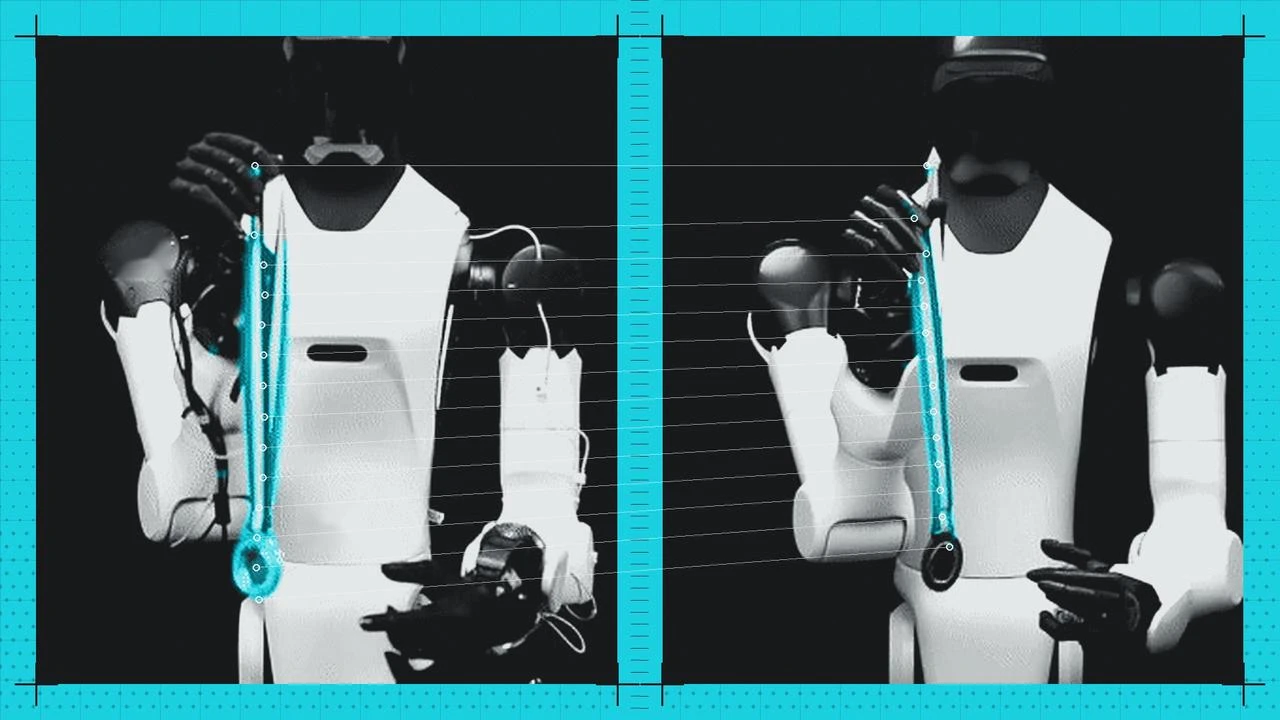
AgiBot Upgrades Genie Sim to Unify Robot Training and Evaluation via Flexible-Body Simulation
Folding a towel or tightening a drawstring bag is simple for humans but challenging for robots, as fabrics and ropes continuously deform and contact friction alters subsequent manipulation conditions. If simulation fails to replicate these dynamics, robots may perform well virtually but fail in real-world deployment.
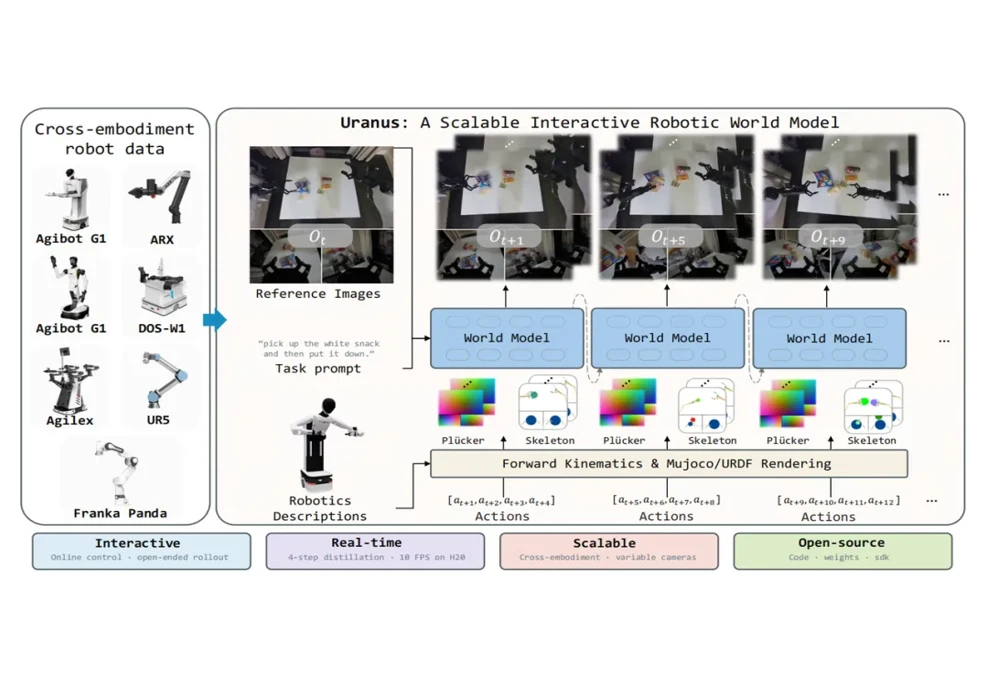
D-Robotics Open-Sources Uranus World Model Simulation Platform, Achieving 0.98 Correlation in RoboTwin Closed-Loop Evaluation
On October 27, the D-Robotics large model team open-sourced the Uranus technical report alongside its inference code, SDK, and model weights, offering 100 early access slots to developers and researchers worldwide.
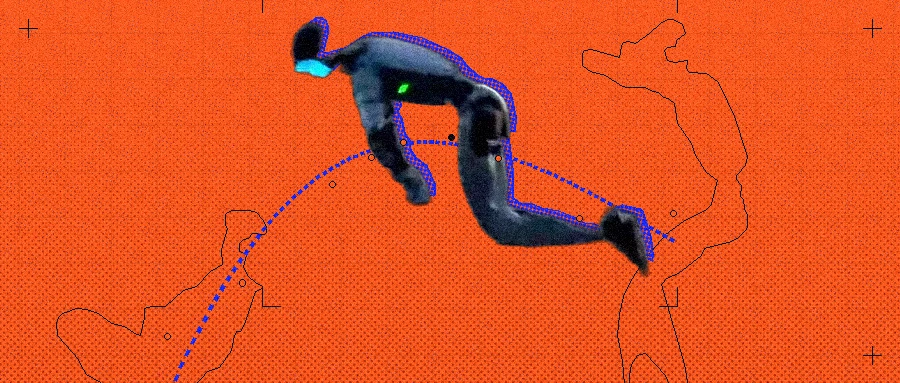
UC Berkeley's SuperMimic Slashes Compute for Humanoid Whole-Body Control
Accepted as an oral paper at CoRL 2026, the SuperMimic framework uses a differentiable world model to train humanoid whole-body control on a single GPU in three hours, outperforming previous methods that required massive GPU clusters.