

Policy
3 related stories
AgiBot's Rollback Method Uses World Model 'Rewind' to Surpass Human Averages in 8 Hours of Real-Robot Training
AgiBot, Beihang University, and the National University of Singapore introduced Rollback, a policy improvement method that backtracks within a world model to explore alternative actions. Trained on a single real robot for eight hours, the approach outperformed human baselines in ball tossing and tabletop curling by eliminating costly physical scene resets.
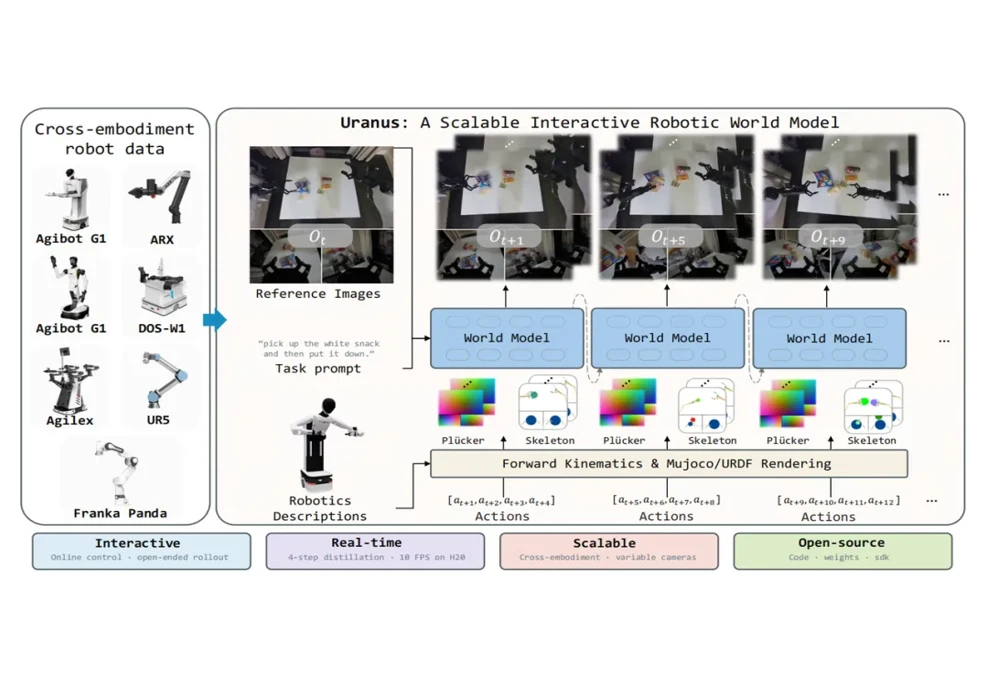
D-Robotics Open-Sources Uranus World Model Simulation Platform, Achieving 0.98 Correlation in RoboTwin Closed-Loop Evaluation
On October 27, the D-Robotics large model team open-sourced the Uranus technical report alongside its inference code, SDK, and model weights, offering 100 early access slots to developers and researchers worldwide.
UC Berkeley's SuperMimic Slashes Compute for Humanoid Whole-Body Control
Accepted as an oral paper at CoRL 2026, the SuperMimic framework uses a differentiable world model to train humanoid whole-body control on a single GPU in three hours, outperforming previous methods that required massive GPU clusters.