

Motion
3 related stories
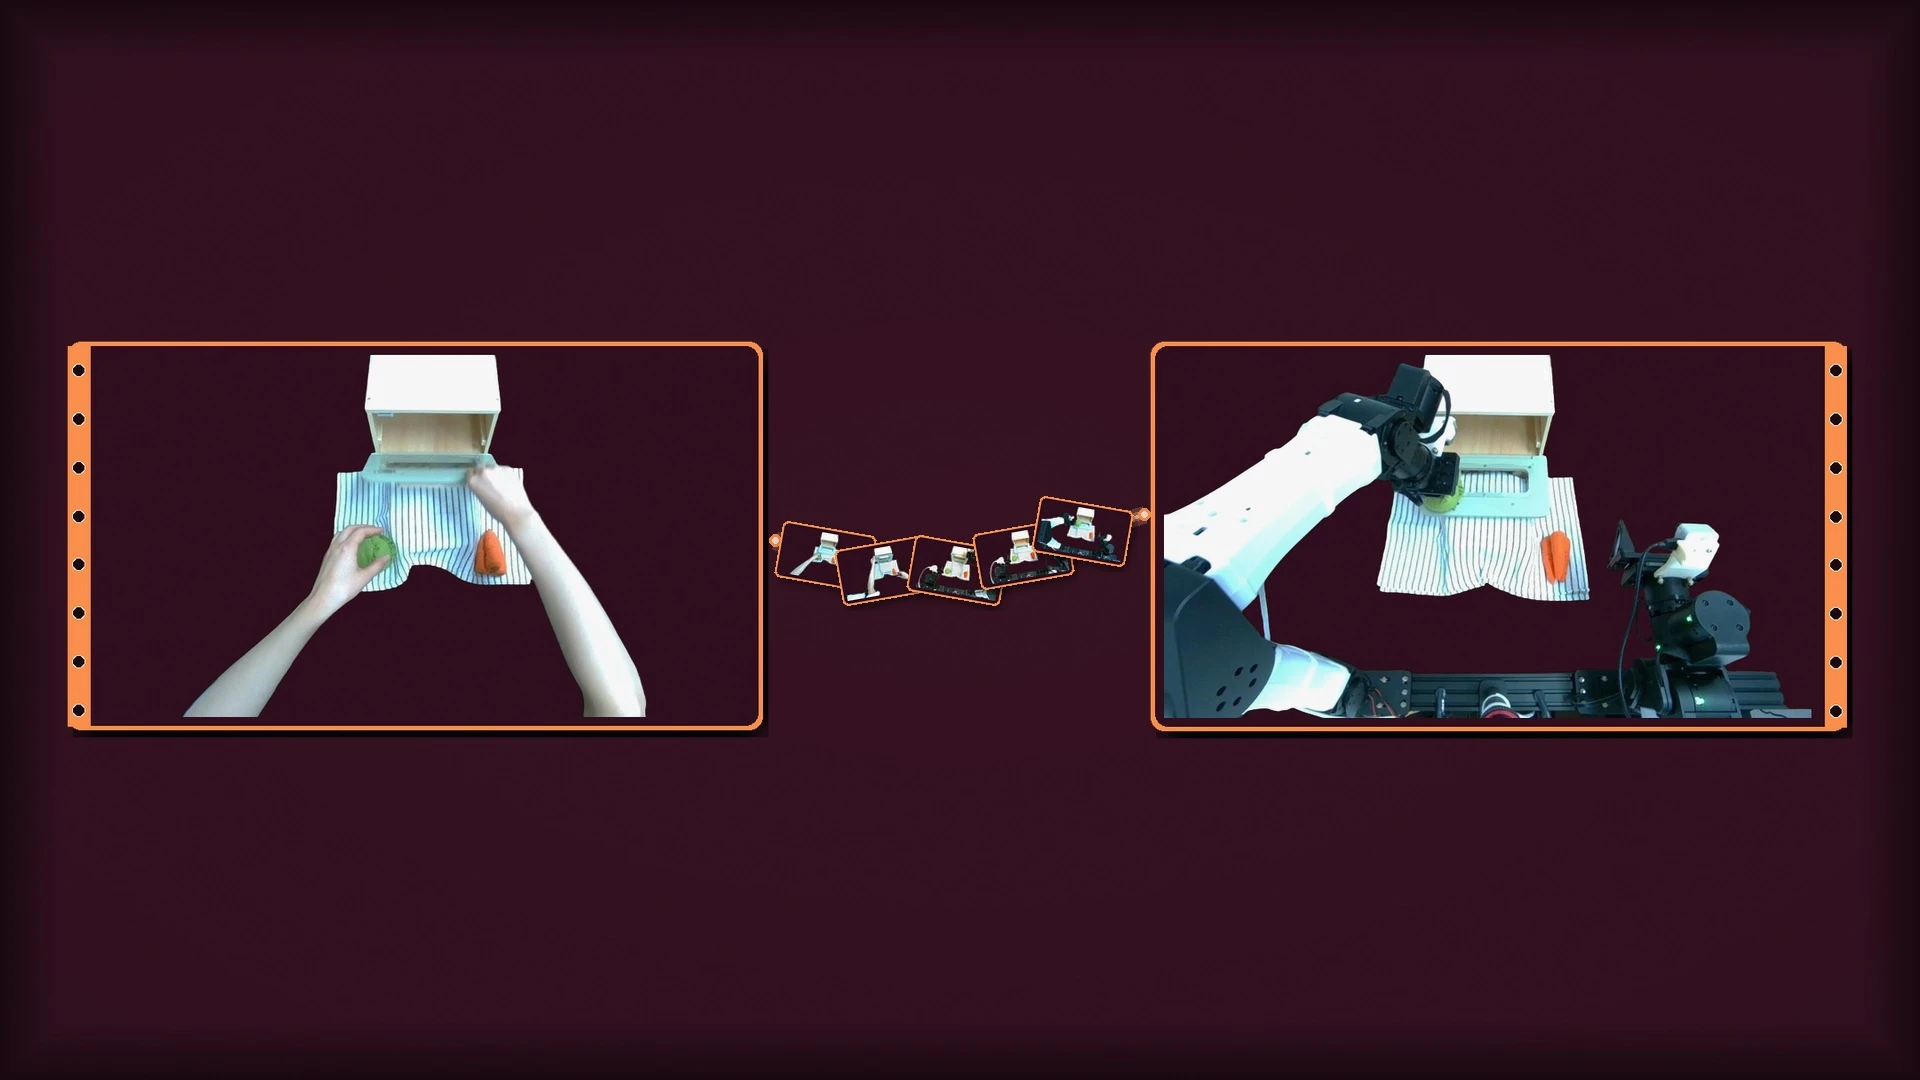
NVIDIA Proposes ThinkWorld to Train VLAs on Unannotated Human Videos via Chain-of-Dynamics and Imagined Futures
NVIDIA and KAIST introduce ThinkWorld, a vision-language action framework that leverages chain-of-dynamics reasoning and imagined future states to extract training signals from unannotated human videos for robot policy learning.
Sharpa Open-Sources SharpaDex v1.0 Dataset Featuring Approximately 300 Hours of Real-World Tactile Manipulation Data Across 59 Tasks
On October 22, Sharpa open-sourced the SharpaDex v1.0 dexterous manipulation dataset. The dataset comprises approximately 300 hours of real-robot manipulation data, 28,993 demonstrations, and 32,396,172 frames, covering 59 manipulation tasks.
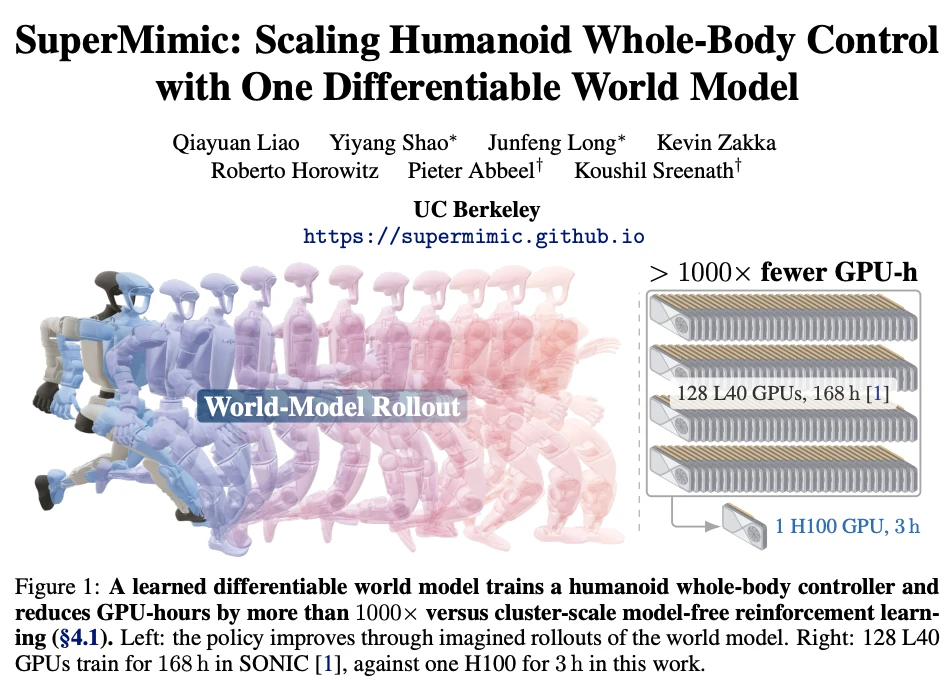
UC Berkeley's SuperMimic Trains Humanoid Whole-Body Control on a Single GPU in 3 Hours, Surpassing 128-GPU Baseline
A UC Berkeley team introduced SuperMimic, a framework that uses a single differentiable world model to scale humanoid whole-body control. The approach trains on a single NVIDIA H100 GPU in 3 hours to outperform the SONIC baseline, which required 128 NVIDIA L40 GPUs over 7 days, reducing GPU-hour costs by more than 1,000 times.