

VLA
3 related stories
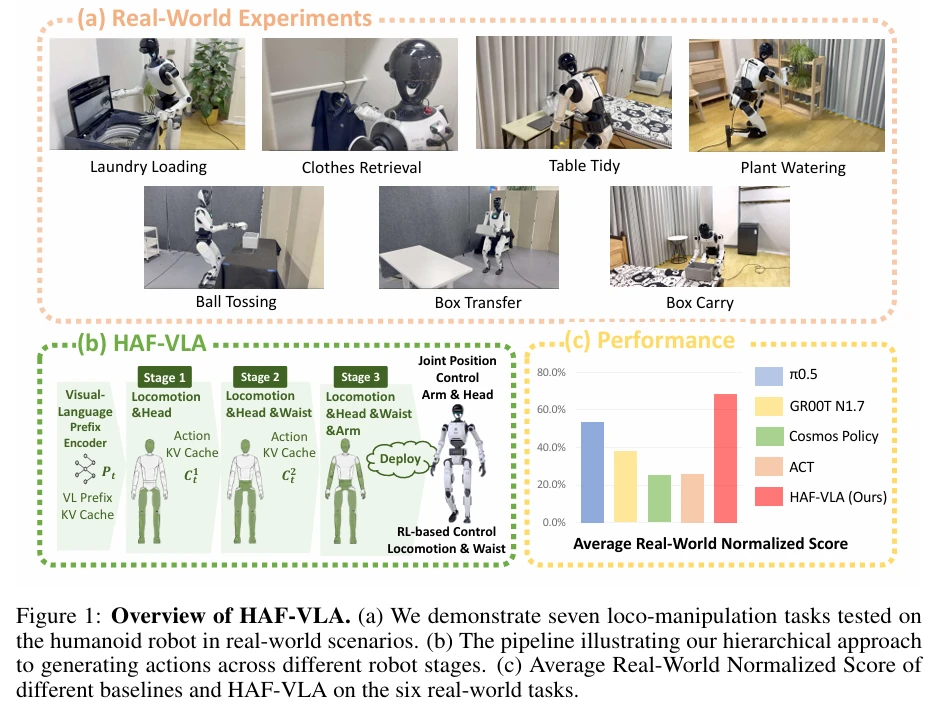
HAF-VLA Enables Hierarchical Generation of Coordinated Full-Body Actions in Humanoid Robots
A joint team from Peking University, Tsinghua University, and other institutions has proposed HAF-VLA, a hierarchical framework that enables humanoid robots to generate coordinated full-body actions by sequentially planning movements along the kinematic chain to avoid compensatory instability.
TacVLA: Activating Tactile Tokens Only Upon Contact for Robust Manipulation
In an interview at IROS 2026, co-author Heng Zhang discusses TacVLA, a contact-aware tactile fusion method that uses a gating mechanism to activate tactile tokens only during physical contact, improving VLA manipulation robustness without adding unnecessary computational overhead.
Galaxea's Hang Zhao: The Next Embodied AI Scaling Goes Beyond Pre-Training
At the 2026 WRC Forum, Galaxea Chief Scientist Hang Zhao argues that Embodied AI's next scaling depends not just on pre-training data and models, but on continuous learning from real-world operations through post-training and real-robot reinforcement learning.