

Robotics
Robotics, embodied intelligence and real-world applications.
Tactile sensing emerges as the next critical data modality for robot learning at IROS 2026
At IROS 2026 in Pittsburgh, sessions on tactile sensing were fully packed, highlighting a critical gap: while vision records appearance and motion, it cannot capture contact physics. Researchers from MIT, Columbia University, and Amazon presented low-cost sensors and human-demonstration methods to scale tactile data collection.

Shanghai Jiao Tong University and LandSpace Team Release DynaForge to Turn Failed Robot Demonstrations into Training Data
Researchers from Shanghai Jiao Tong University and LandSpace have released DynaForge, a system that uses motion planning as a prior and residual learning to convert failed dynamic manipulation trajectories in simulation into valid training data for robot policies.
IROS Best Paper Finalist: Helping Robots Detect Glass for Safer Navigation
42HOW Robotics interviews co-first author Yu Jingwen on the Southern University of Science and Technology team’s RANSAC-based framework that fuses depth foundation models with sensor data to enable safe robot navigation through glass obstacles.
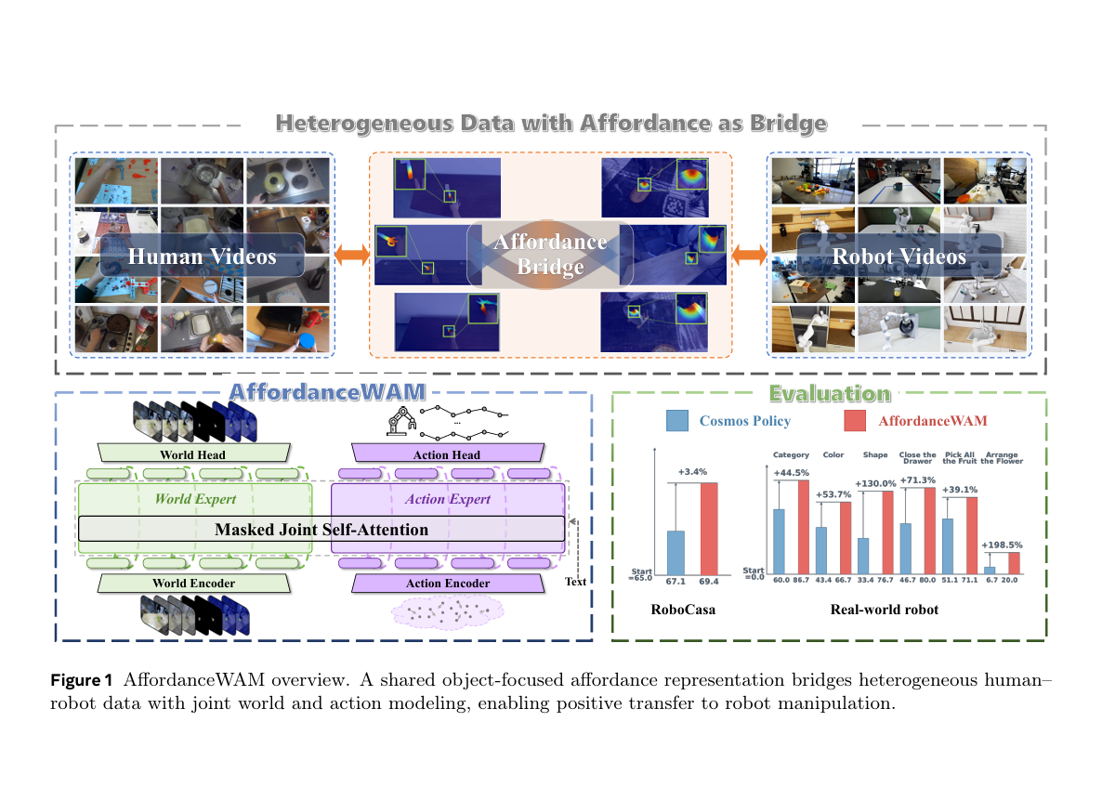
Five Universities and Knowin AI Release AffordanceWAM to Bridge Human Video and Robot Training via Affordance Prediction
A joint team from five universities and Knowin AI introduces AffordanceWAM, a world-action model that uses explicit affordance prediction to align human video data with robot training, resolving long-standing semantic mismatches in embodied AI.
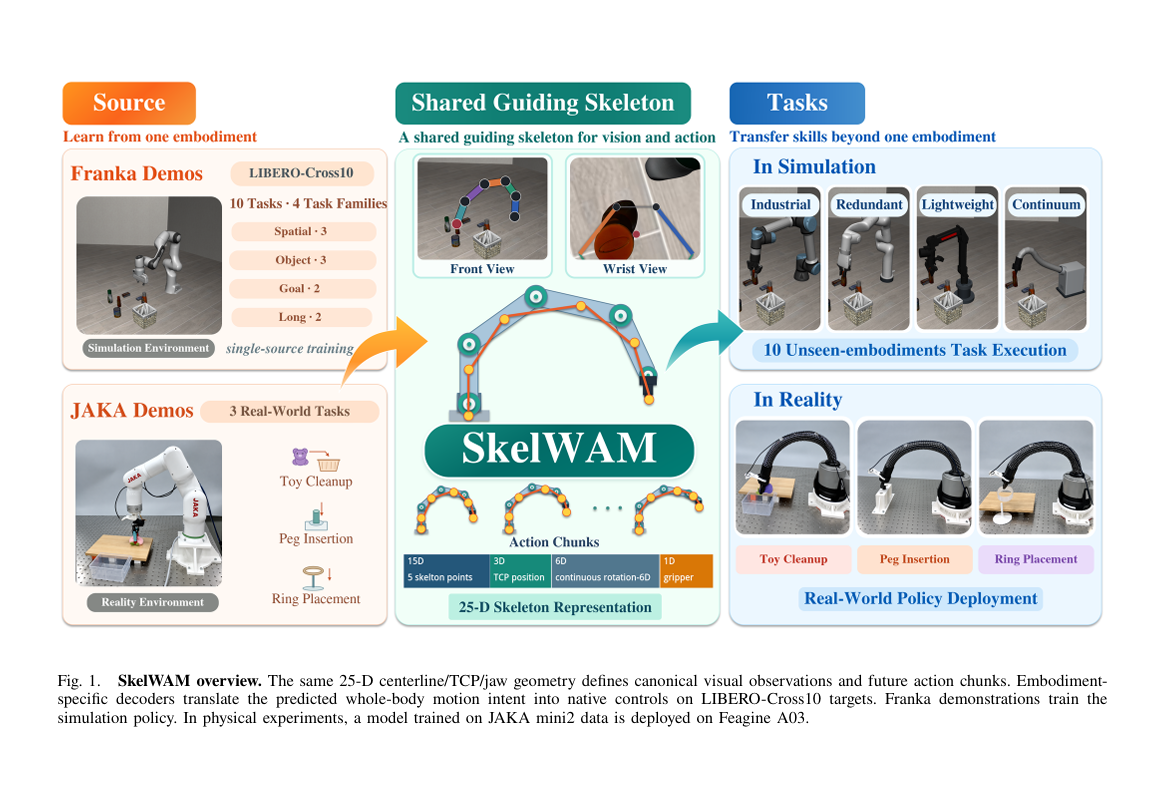
Tsinghua and Peking University Teams Release SkelWAM for Zero-Shot Cross-Embodiment Manipulation
Researchers from Tsinghua University and Peking University have introduced SkelWAM, a skeleton-guided world-action model that enables zero-shot transfer of manipulation policies across ten different robotic arm structures without retraining.
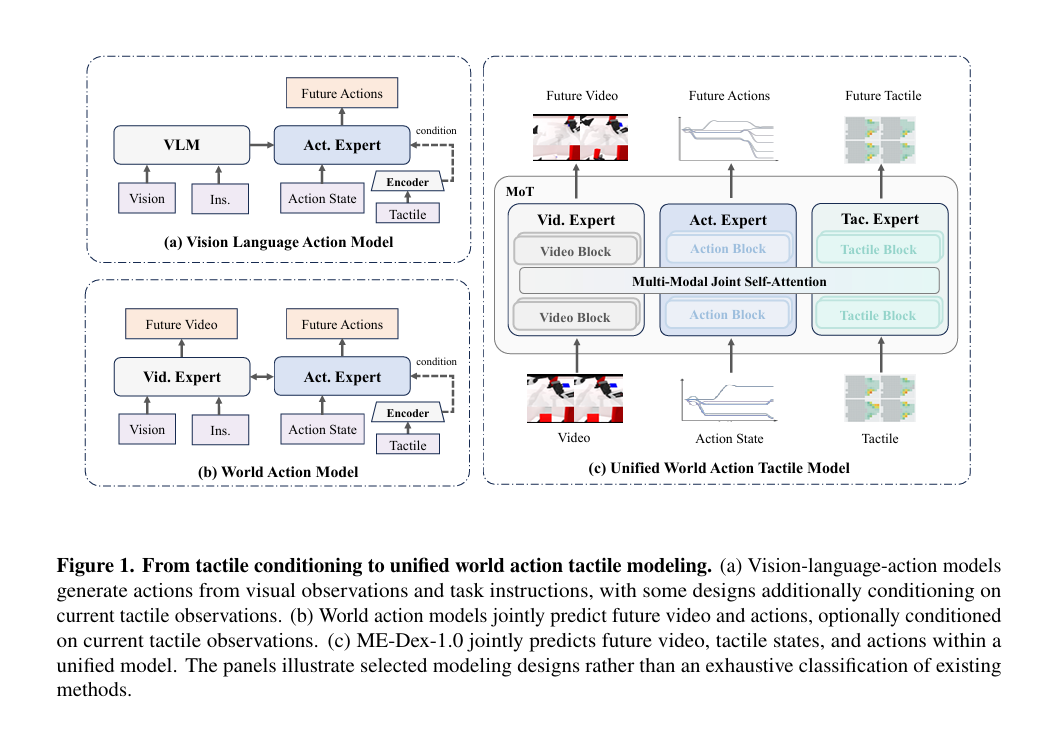
Li Auto's ME-Dex 1.0 Predicts Future Tactile States Alongside Visual Observations
Li Auto’s foundation model team released ME-Dex 1.0, a world action model that treats tactile sensing as a parallel prediction target to video. By aligning heterogeneous tactile data from five different hands into a unified representation, the system significantly improves success rates in high-contact dexterous manipulation tasks.
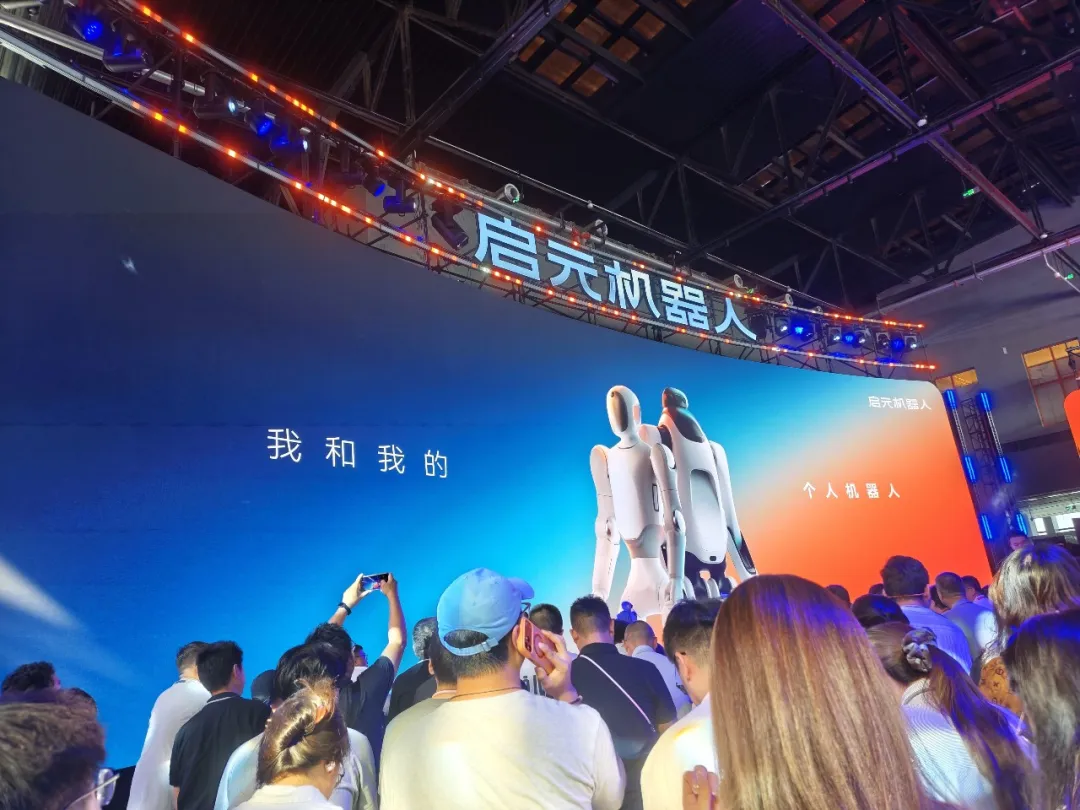
PrimeBot Launches Personal Robots at iPhone Price, Bets on AI as a Physical Terminal
Shangwei New Materials's PrimeBot released the Q1 and T1 humanoid robots starting at RMB 19,999, positioning them as personal AI terminals comparable in cost to high-end smartphones while aiming to build a developer ecosystem.
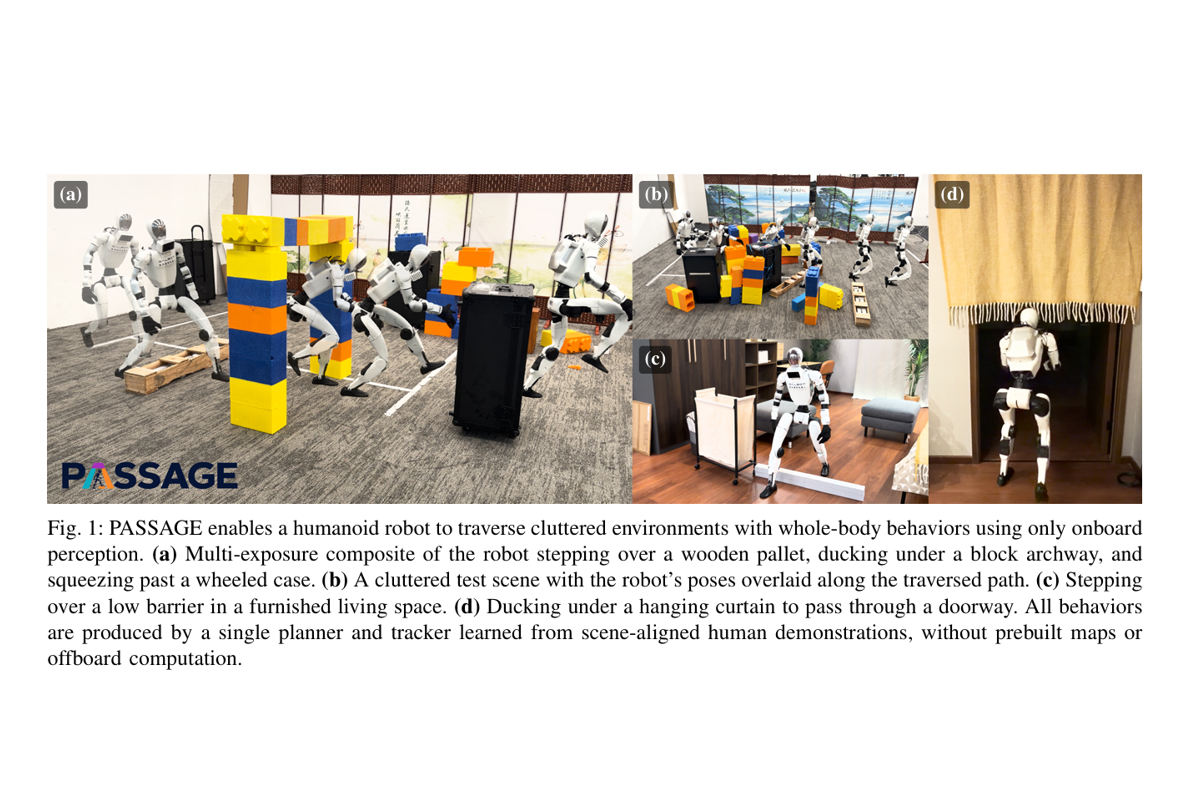
Tsinghua's Li Yi Team Releases PASSAGE for Humanoid Robots to Navigate Cluttered Environments
A joint team led by Tsinghua University released the PASSAGE paper on September 16, enabling humanoid robots to autonomously plan and execute traversal actions in cluttered spaces using 100 hours of scene-aligned motion data. Real-robot tests showed a 90% zero-contact success rate across 50 trials, with simulation results confirming that navigation performance scales with training data volume.

Sharpa Reveals RMB 4.5 Billion in Funding as North Robot Debuts in Real DQ Store
Sharpa, backed by 4.5 billion RMB in funding, deploys its North robot at a DQ store. Founder Li Yifan argues that true embodied AI requires completing full workflows, not just performing isolated dexterous tasks.
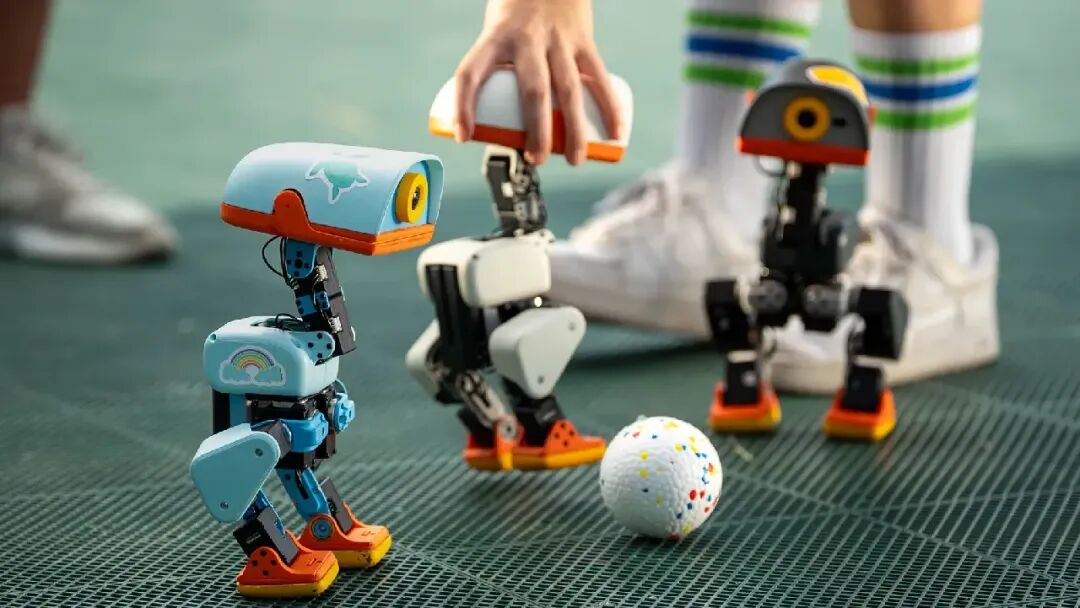
Hugging Face’s Pollen Robotics Launches $399 Microduck Robot for Embodied AI Training
Hugging Face’s Pollen Robotics has opened pre-orders for Microduck, a $399 bipedal robot designed as an affordable development platform for reinforcement learning and sim-to-real deployment.
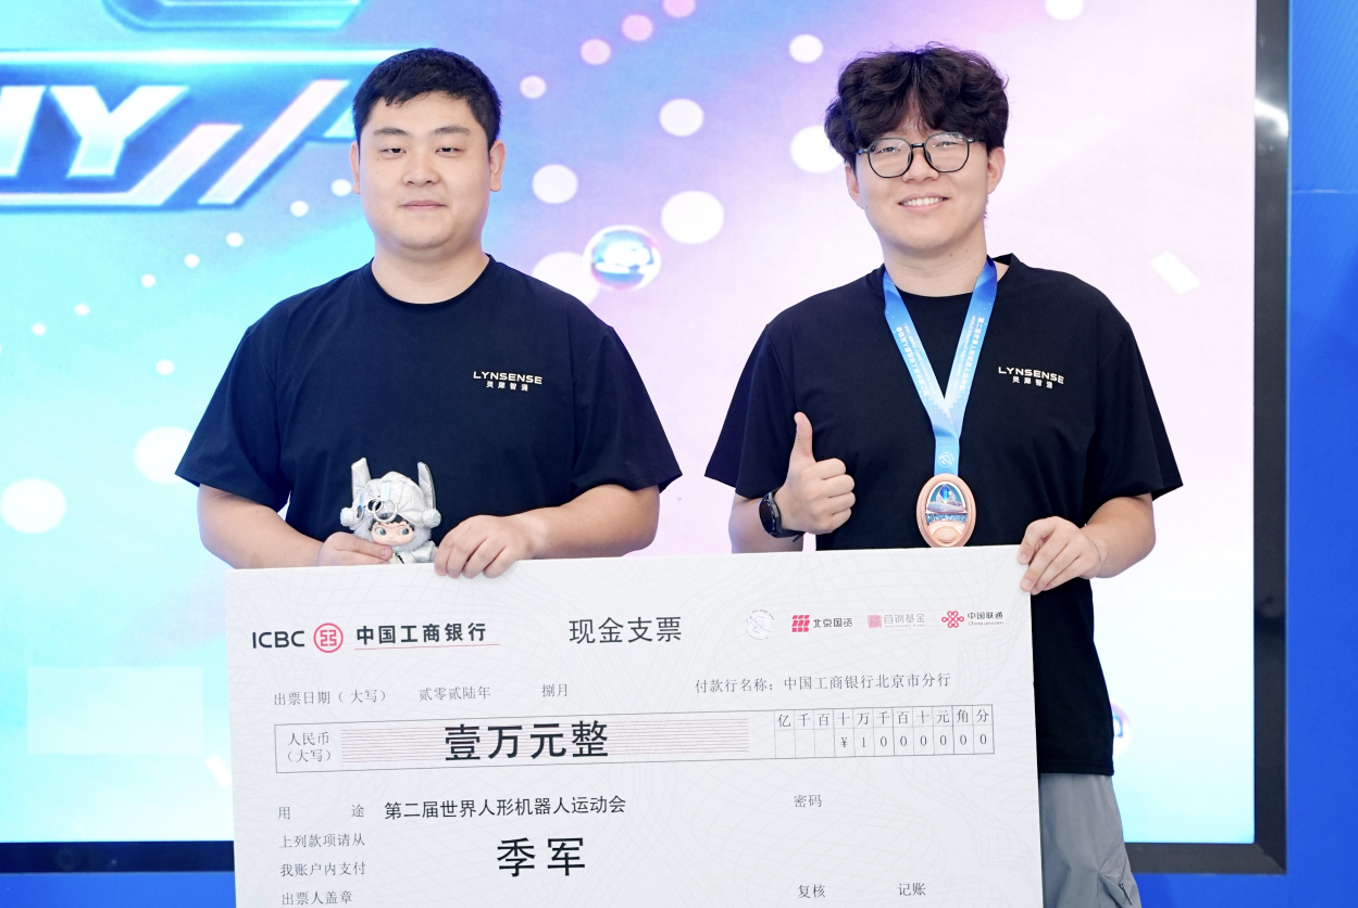
Newcomer Lingxi Zhiyong Ranks Top Three in World Humanoid Robot Games with ROSS Harness
Lingxi Zhiyong's robot achieved 160 points and ranked among the top three at the World Humanoid Robot Games. The company attributes this success to its self-developed ROSS Harness Agent, which bridges AI models and hardware execution.
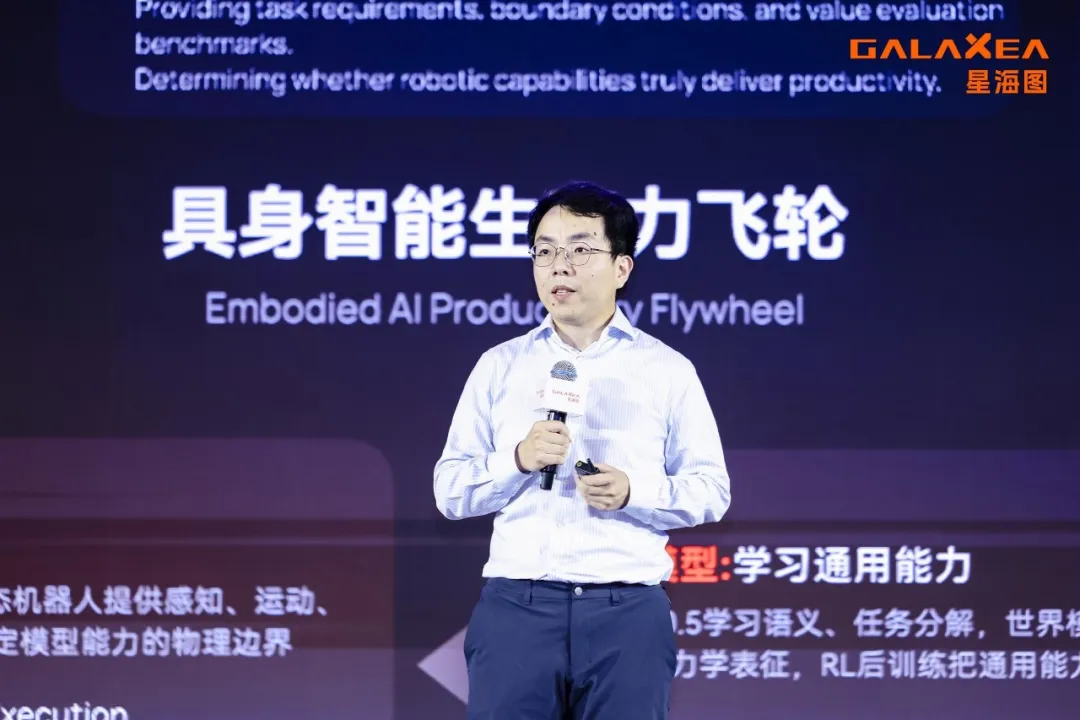
Galaxea's Hang Zhao: The Next Embodied AI Scaling Goes Beyond Pre-Training
At the 2026 WRC Forum, Galaxea Chief Scientist Hang Zhao argues that Embodied AI's next scaling depends not just on pre-training data and models, but on continuous learning from real-world operations through post-training and real-robot reinforcement learning.