

Robotics
Robotics, embodied intelligence and real-world applications.
Sharpa Open-Sources SharpaDex v1.0 Dataset Featuring Approximately 300 Hours of Real-World Tactile Manipulation Data Across 59 Tasks
On October 22, Sharpa open-sourced the SharpaDex v1.0 dexterous manipulation dataset. The dataset comprises approximately 300 hours of real-robot manipulation data, 28,993 demonstrations, and 32,396,172 frames, covering 59 manipulation tasks.
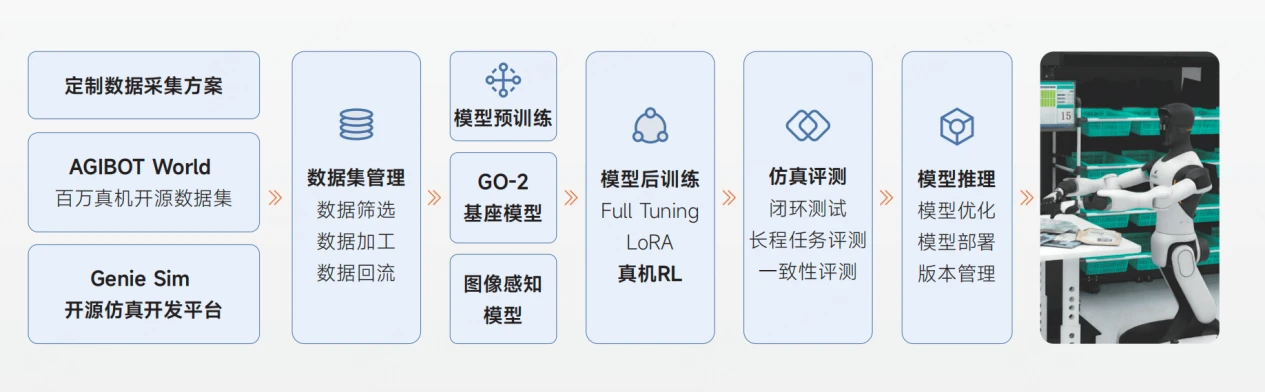
AgiBot Launches Genie Studio 2.0 to Validate Robot Deployment in New Scenarios in as Few as 7 Days
On October 23, AgiBot released Genie Studio 2.0, an all-in-one embodied AI operations platform and the second installment of its "AI WAVE" series. The platform comprises Flywheel, Agent, and Monitor modules, covering data collection, model training, simulation testing, task orchestration, and multi-robot operations.
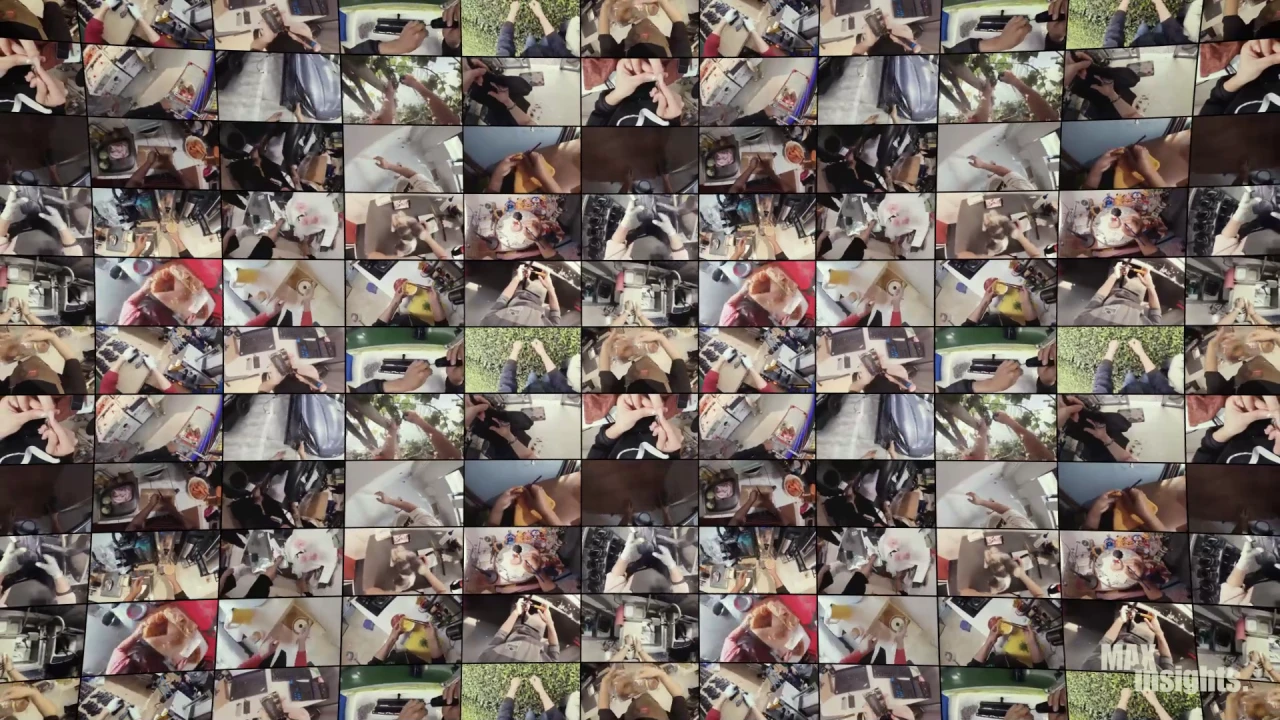
Maxinsights Raises $30 Million Seed Round Led by Peak XV to Scale Robot Training Data
On October 22, Santa Clara-based Maxinsights closed a $30 million seed round led by Peak XV, with participation from Tola Capital, South Park Commons, Yince Capital, and Alumni Ventures, to scale its pipeline of real-world human demonstration data for robot training.
UC Berkeley's SuperMimic Slashes Compute for Humanoid Whole-Body Control
Accepted as an oral paper at CoRL 2026, the SuperMimic framework uses a differentiable world model to train humanoid whole-body control on a single GPU in three hours, outperforming previous methods that required massive GPU clusters.
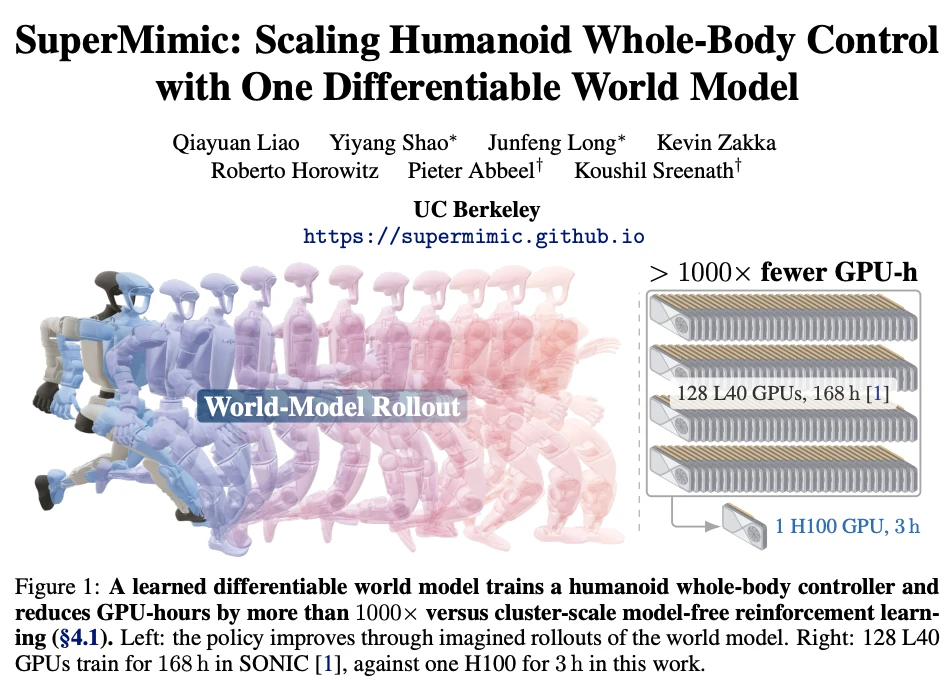
UC Berkeley's SuperMimic Trains Humanoid Whole-Body Control on a Single GPU in 3 Hours, Surpassing 128-GPU Baseline
A UC Berkeley team introduced SuperMimic, a framework that uses a single differentiable world model to scale humanoid whole-body control. The approach trains on a single NVIDIA H100 GPU in 3 hours to outperform the SONIC baseline, which required 128 NVIDIA L40 GPUs over 7 days, reducing GPU-hour costs by more than 1,000 times.
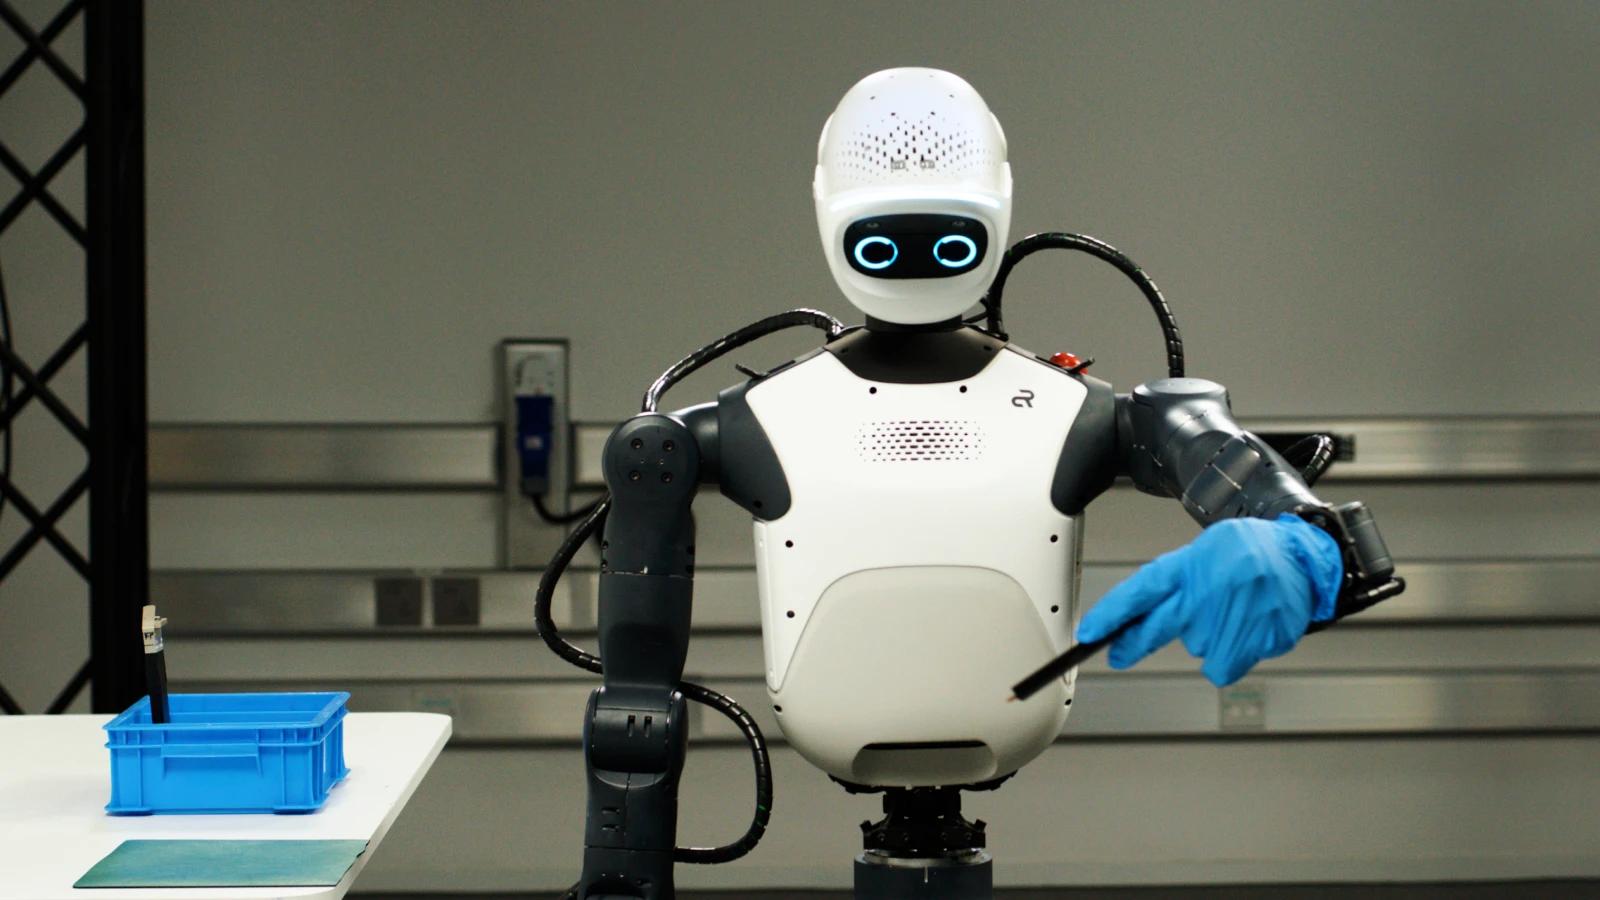
Agile Robots and NVIDIA Launch Agile ONE SN Reference Humanoid for Research Labs
On October 21, NVIDIA expanded its Isaac open robot development platform at GTC Berlin, while Munich-based Agile Robots and NVIDIA simultaneously introduced the Agile ONE SN, a ready-to-use reference humanoid robot targeting academic research.
Tesla Confirms Optimus Production and Early Ramp in Q3 Earnings
In its third-quarter 2026 earnings report released on October 21, Tesla confirmed that the first production-quality Optimus humanoid robots have rolled off the line at its Fremont factory, marking the start of an early ramp for the California project.
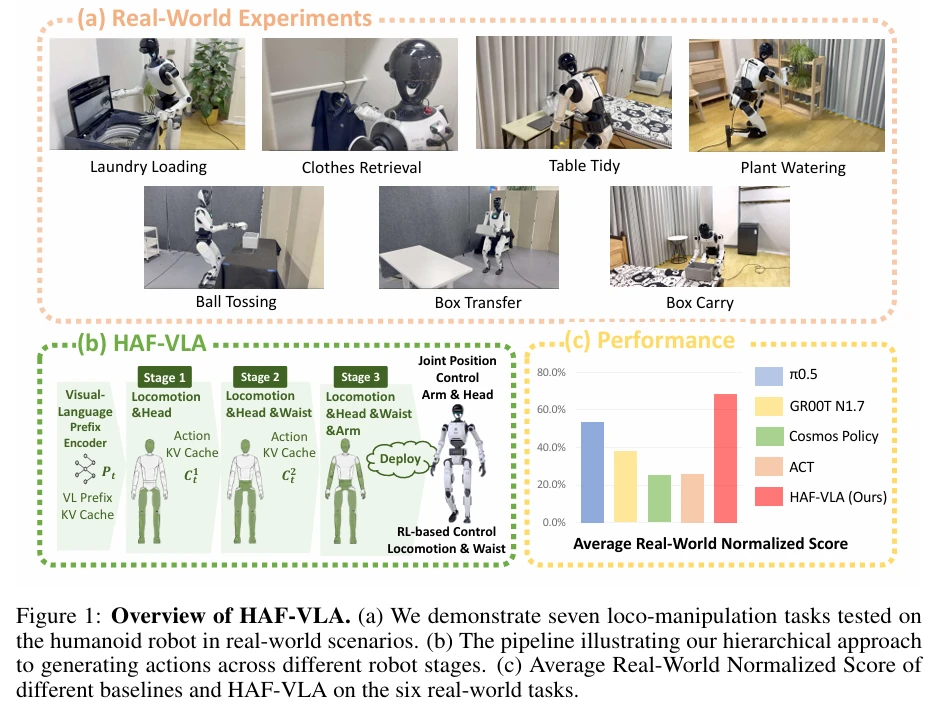
HAF-VLA Enables Hierarchical Generation of Coordinated Full-Body Actions in Humanoid Robots
A joint team from Peking University, Tsinghua University, and other institutions has proposed HAF-VLA, a hierarchical framework that enables humanoid robots to generate coordinated full-body actions by sequentially planning movements along the kinematic chain to avoid compensatory instability.
Dream Labs Raises USD 90 Million in Seed Funding, Debuts Robot Foundation Model Dream-1
On October 19, robotics AI startup Dream Labs announced the close of a USD 90 million seed round alongside the launch of its robot foundation model, Dream-1, and a public API.
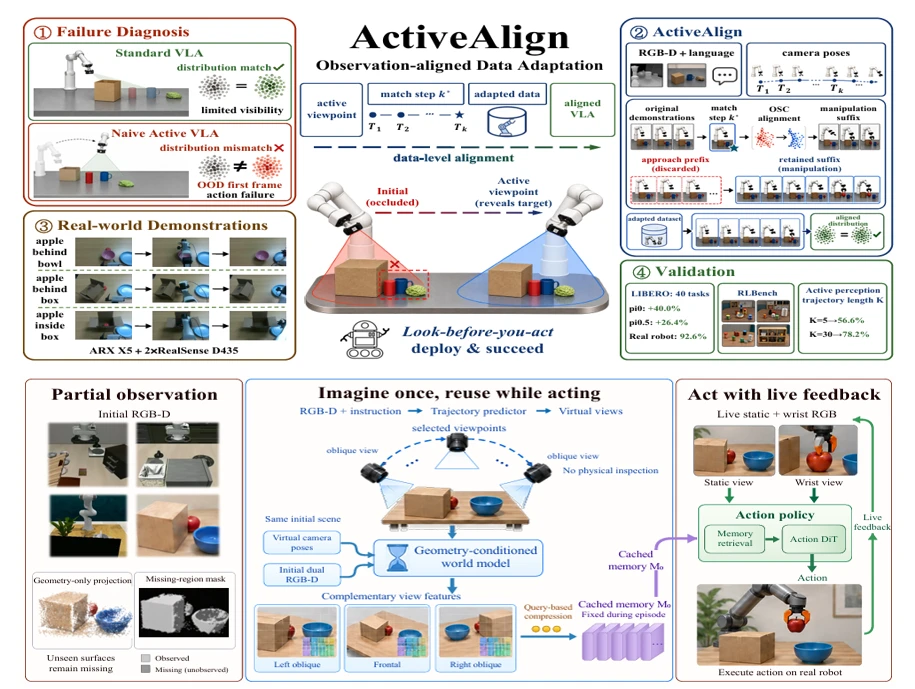
Fudan Team Bridges Active Perception and Vision-Language-Action Models to Overcome Viewpoint Shifts
Two papers from Fudan University introduce ActiveAlign and AWAM, which align training data and representations with active camera movements to prevent distribution shifts in vision-language-action models when robots adjust their viewpoints to overcome occlusions.
In Conversation with Saturday Robotics Founder Junfan Zhu: “By the Time a Robotics Paper Is Published, Its Approach May Already Be Out of Date”
How Junfan Zhu is building a cross-disciplinary robotics research community in the Bay Area while working on better ways to evaluate AI systems in the physical world, and why he thinks robotics has yet to have its benchmark moment.
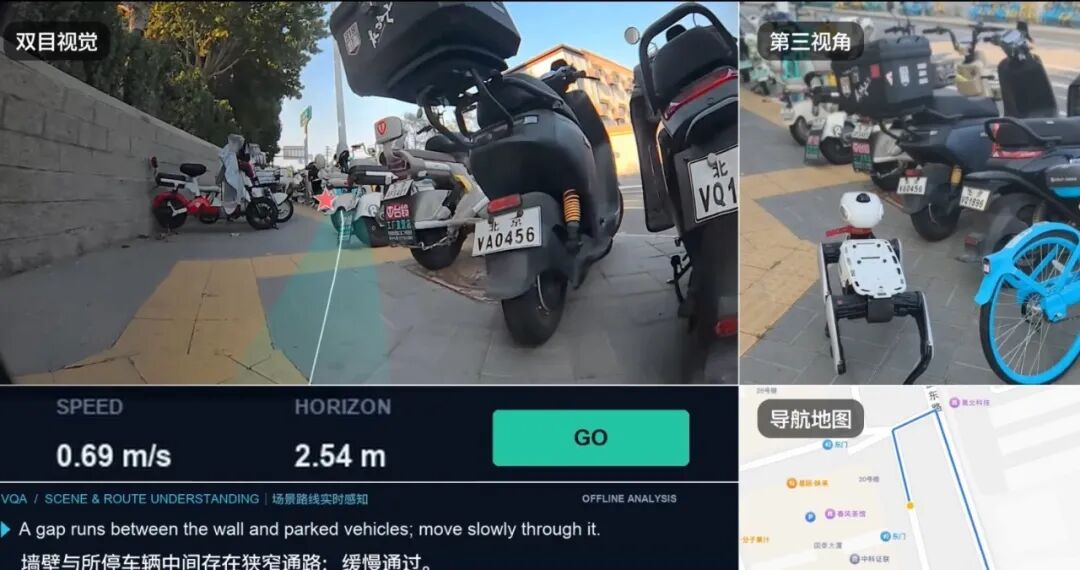
Robots Can Run Marathons, So Why Is It Still So Hard to Reach the Front Desk?
Vita Dynamics introduces VbotNav-0, an asynchronous cloud-edge navigation framework that enables robots to seamlessly transition from outdoor streets to indoor environments using unified route tokens and a three-tier decision architecture.