

Multimodal Data
2 related stories
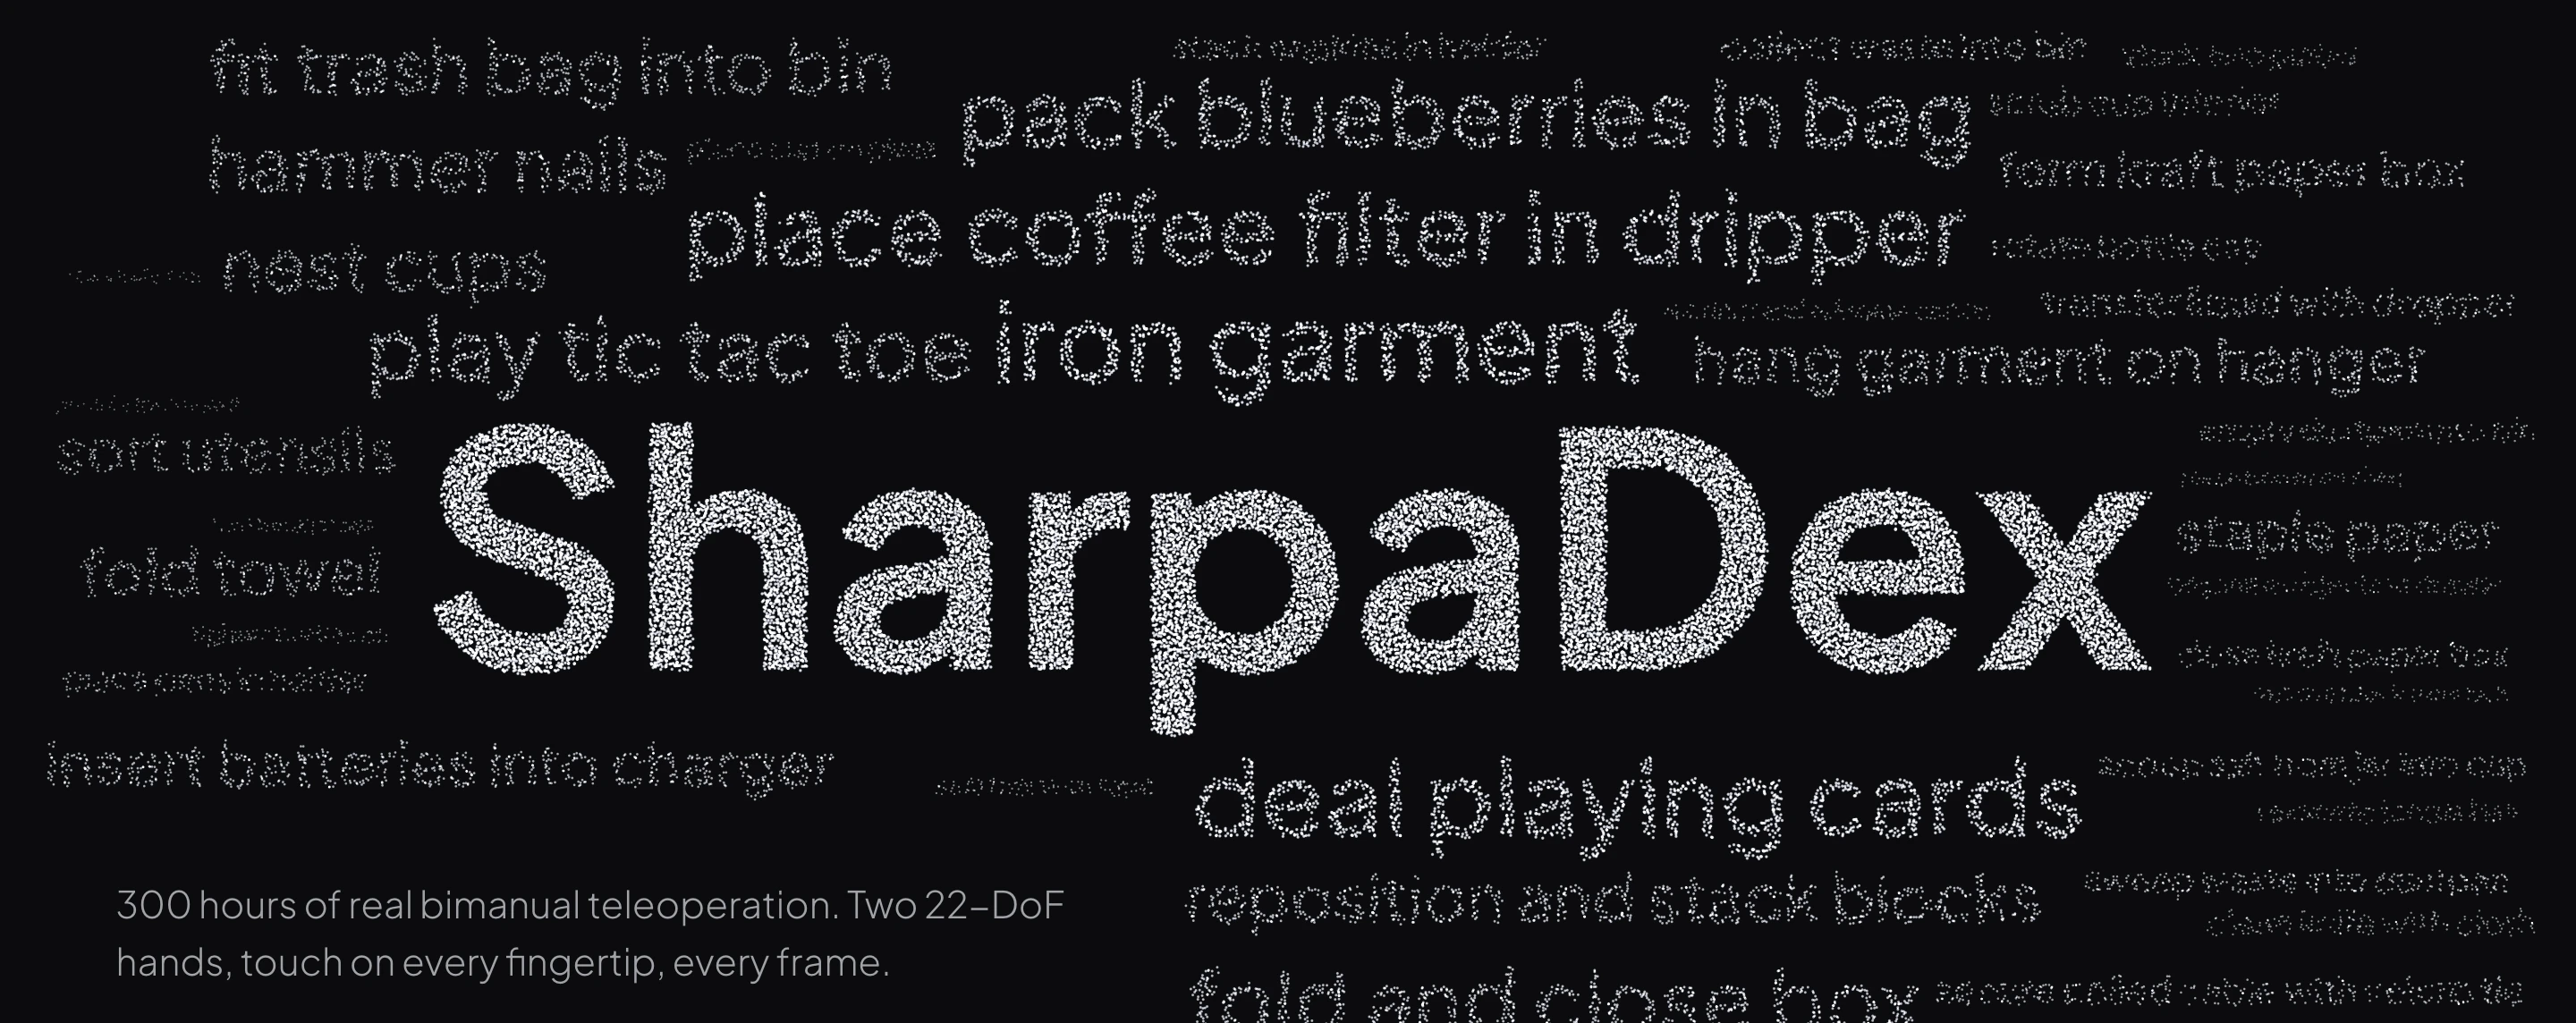
Sharpa Open-Sources SharpaDex v1.0 Dataset Featuring Approximately 300 Hours of Real-World Tactile Manipulation Data Across 59 Tasks
On October 22, Sharpa open-sourced the SharpaDex v1.0 dexterous manipulation dataset. The dataset comprises approximately 300 hours of real-robot manipulation data, 28,993 demonstrations, and 32,396,172 frames, covering 59 manipulation tasks.
Tactile sensing emerges as the next critical data modality for robot learning at IROS 2026
At IROS 2026 in Pittsburgh, sessions on tactile sensing were fully packed, highlighting a critical gap: while vision records appearance and motion, it cannot capture contact physics. Researchers from MIT, Columbia University, and Amazon presented low-cost sensors and human-demonstration methods to scale tactile data collection.