

Robot Manipulation
3 related stories
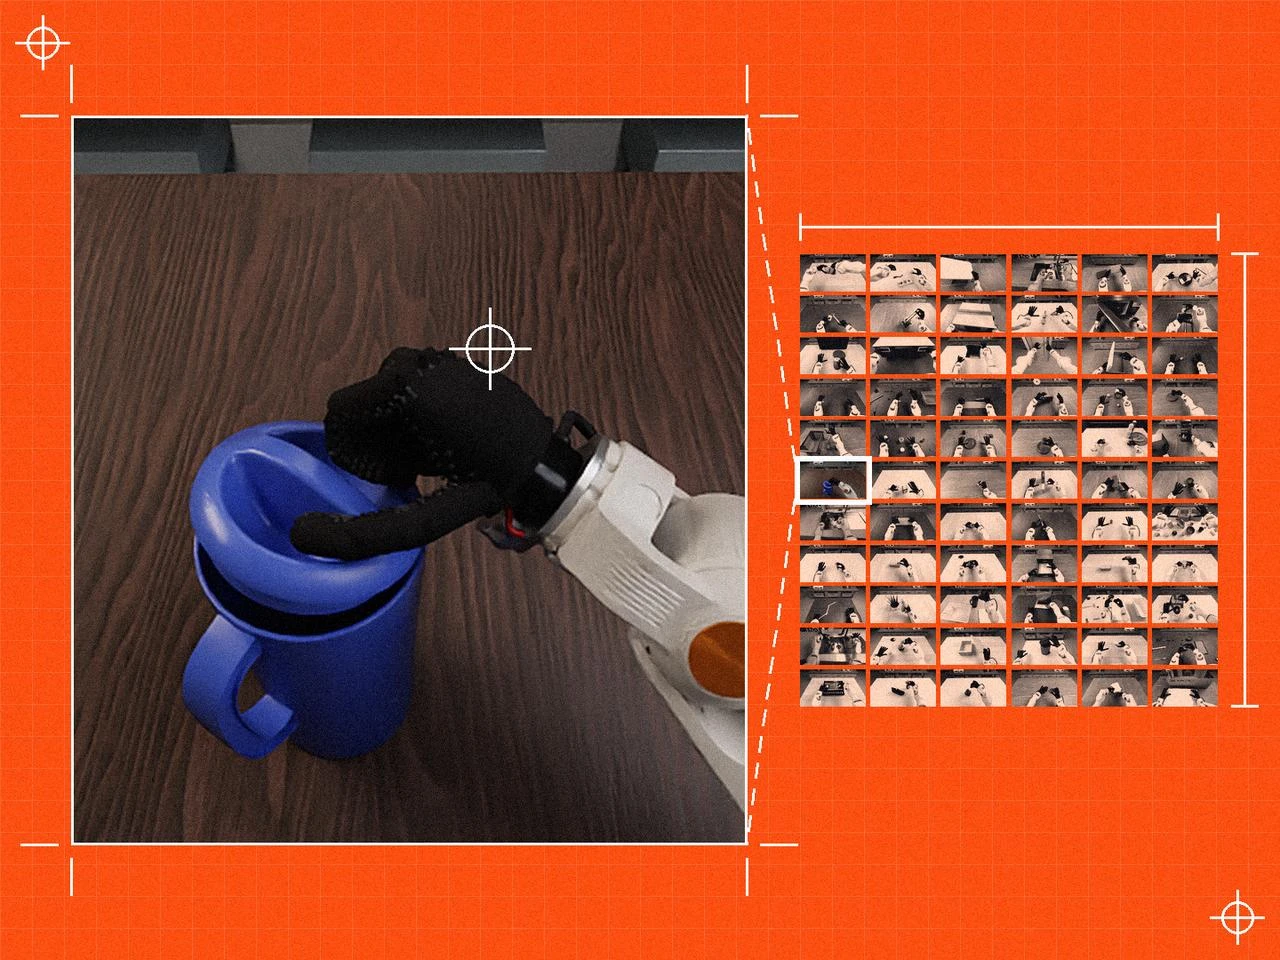
Tsinghua University Releases HandsOn Simulation Benchmark for Dexterous Manipulation with 18,000 Demonstrations
Most mainstream robot manipulation benchmarks focus on two-finger grippers, leaving five-finger dexterous hands under-evaluated with inconsistent metrics. To address this, researchers from Tsinghua University, Beijing University of Posts and Telecommunications, Natural Will, and Peking University have introduced HandsOn, a large-scale simulation benchmark featuring 66 tasks and 18,000 human teleoperation demonstrations.
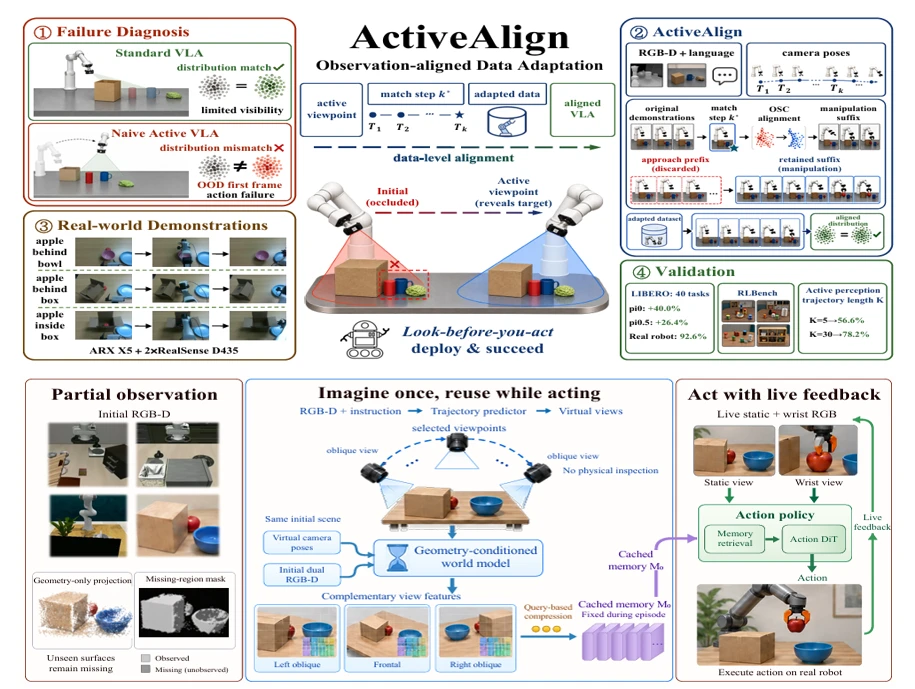
Fudan Team Bridges Active Perception and Vision-Language-Action Models to Overcome Viewpoint Shifts
Two papers from Fudan University introduce ActiveAlign and AWAM, which align training data and representations with active camera movements to prevent distribution shifts in vision-language-action models when robots adjust their viewpoints to overcome occlusions.
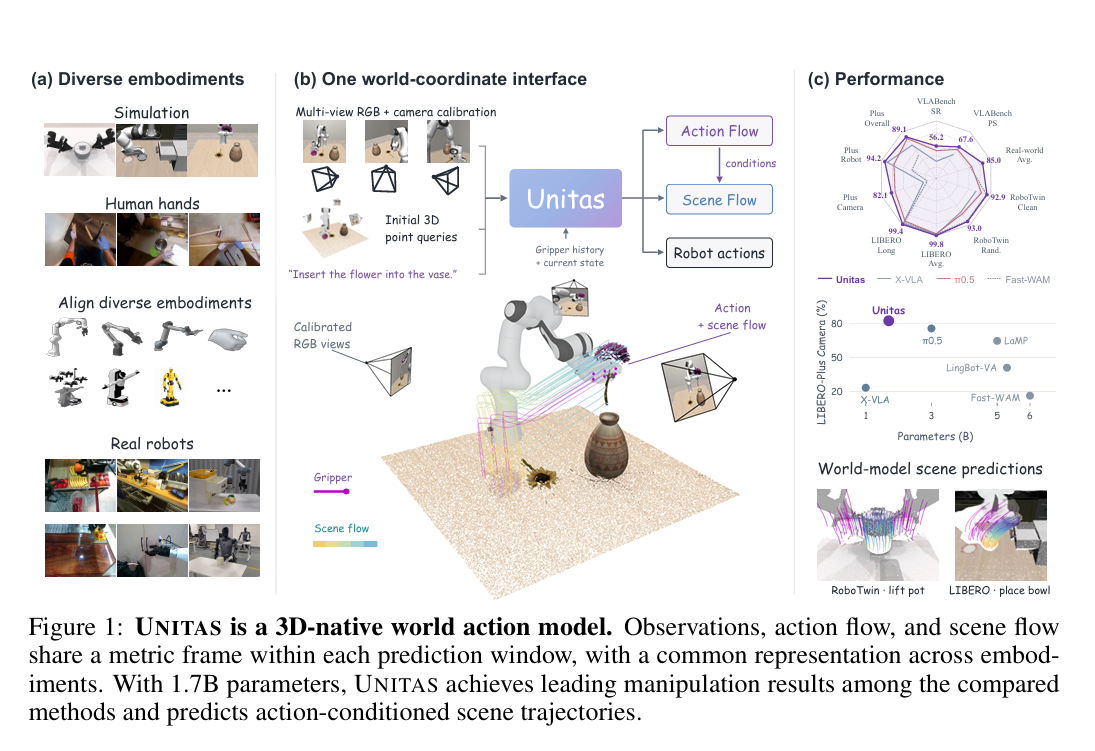
Kui Jia Team's New Work: Enabling World Action Models to Truly Understand 3D Space
A joint team led by Kui Jia has published UNITAS, a world action model that unifies observation, action, and scene changes in a shared metric 3D coordinate system. The 1.7B-parameter model achieves 99.8% task success on the LIBERO benchmark and reduces displacement prediction error by 35% compared to PointWorld.