

Robotics
36 related stories
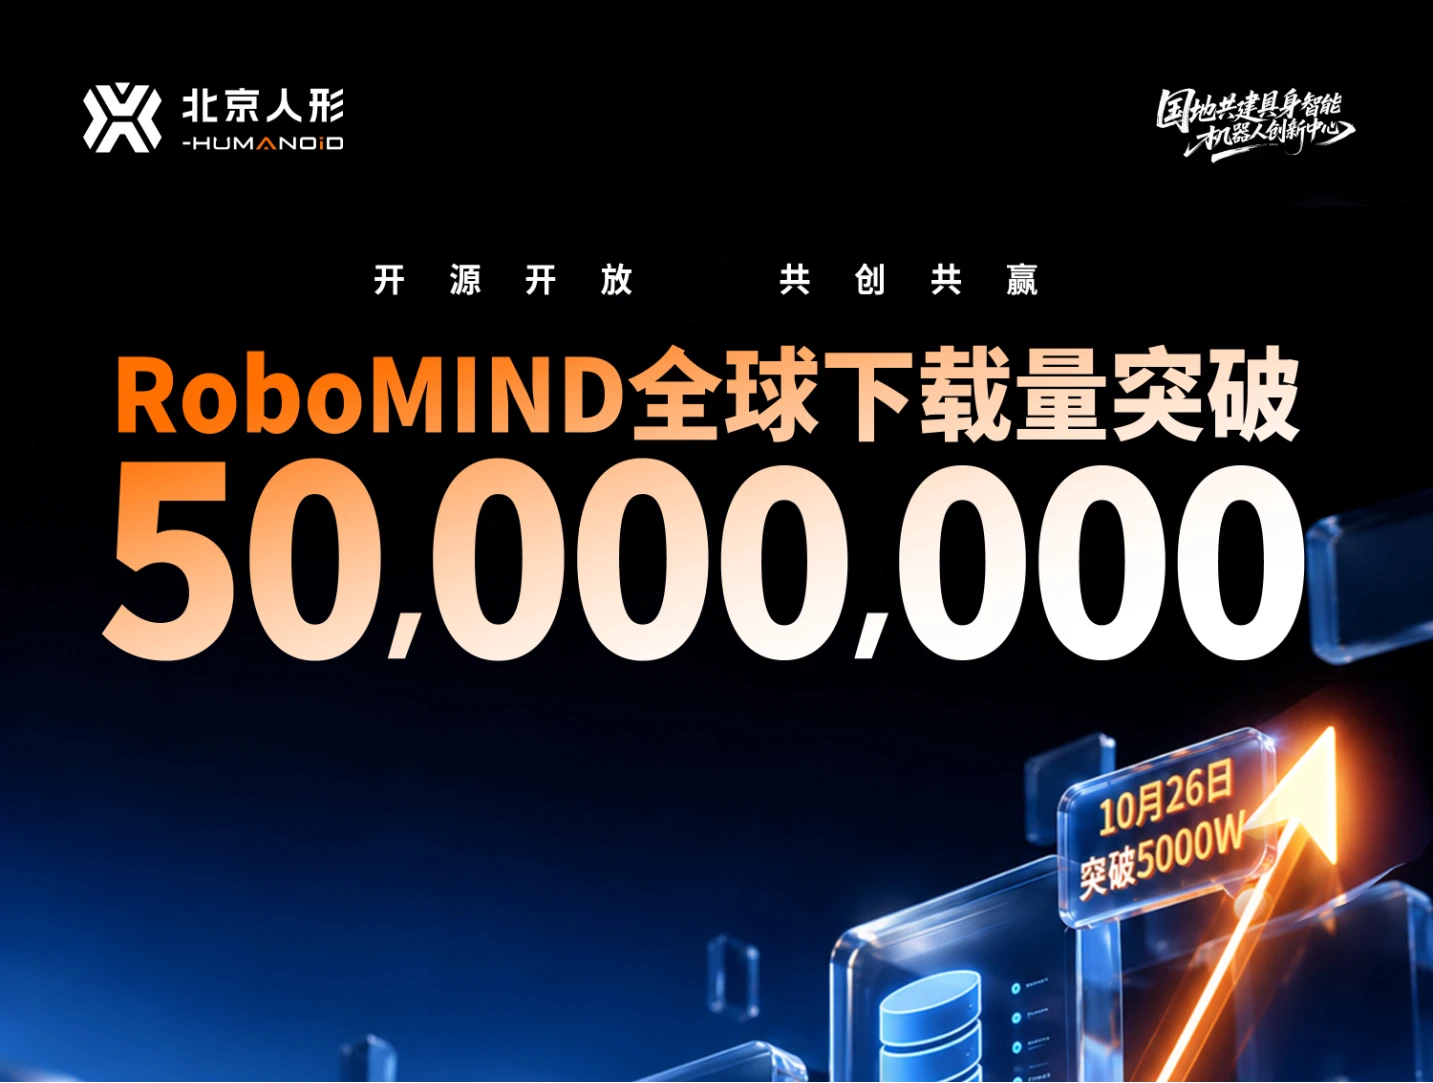
RoboMIND Open-Source Dataset Surpasses 50 Million Downloads, Latest 10 Million Reached in 18 Days
The Beijing Humanoid Robot Innovation Center announced on October 26 that the open-source dataset RoboMIND has exceeded 50 million global downloads. The latest 10 million downloads were achieved in just 18 days, accelerating significantly from the 223 days required for the first 10 million and 39 days for the second.
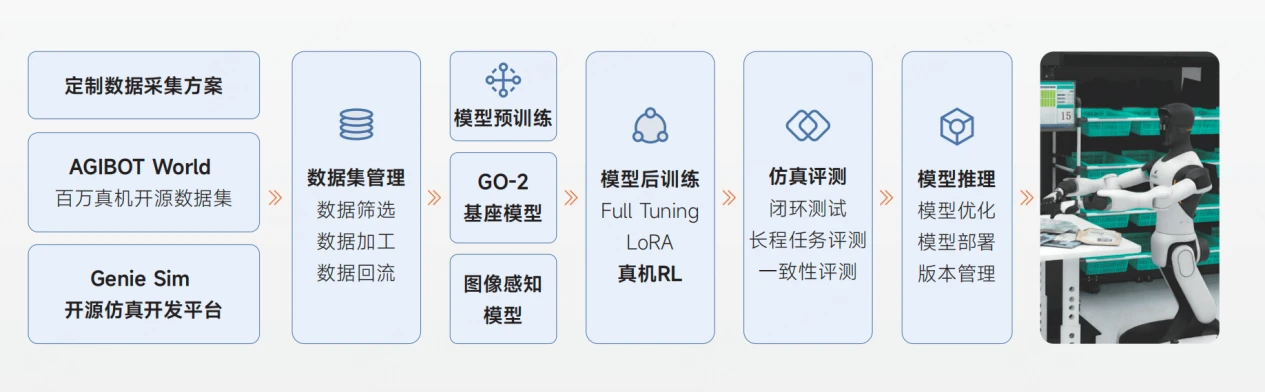
AgiBot Launches Genie Studio 2.0 to Validate Robot Deployment in New Scenarios in as Few as 7 Days
On October 23, AgiBot released Genie Studio 2.0, an all-in-one embodied AI operations platform and the second installment of its "AI WAVE" series. The platform comprises Flywheel, Agent, and Monitor modules, covering data collection, model training, simulation testing, task orchestration, and multi-robot operations.
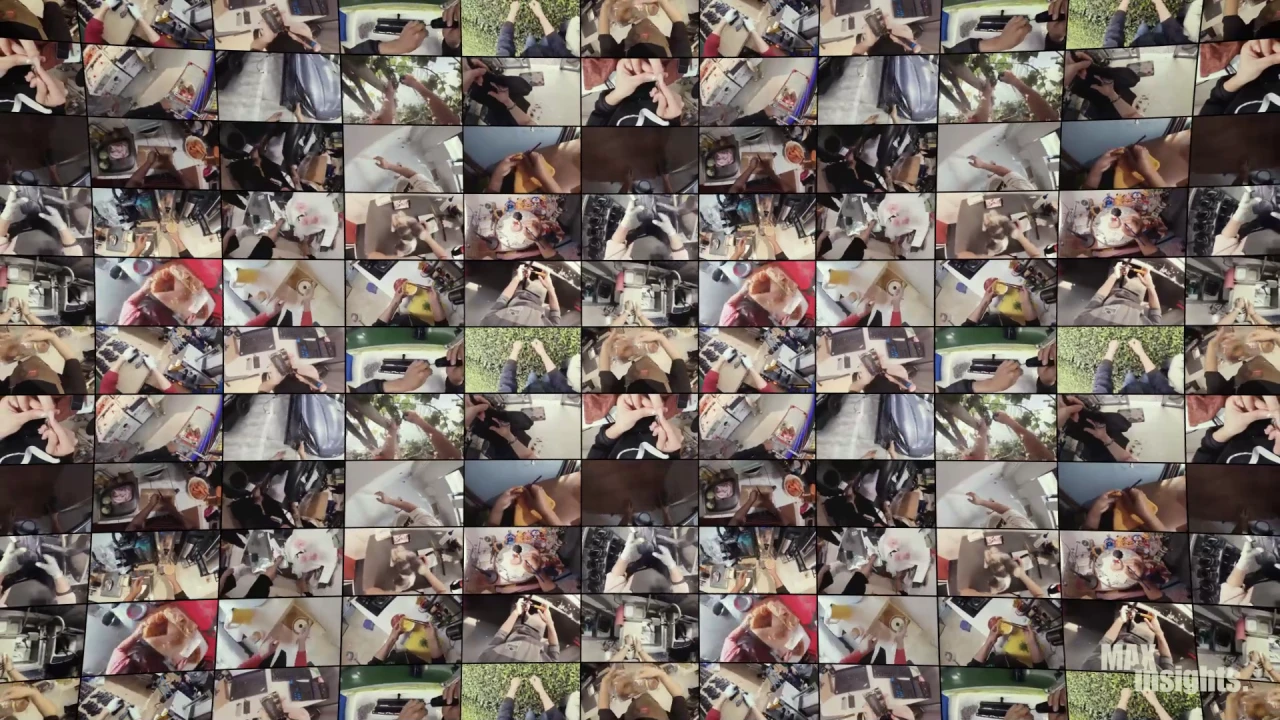
Maxinsights Raises $30 Million Seed Round Led by Peak XV to Scale Robot Training Data
On October 22, Santa Clara-based Maxinsights closed a $30 million seed round led by Peak XV, with participation from Tola Capital, South Park Commons, Yince Capital, and Alumni Ventures, to scale its pipeline of real-world human demonstration data for robot training.
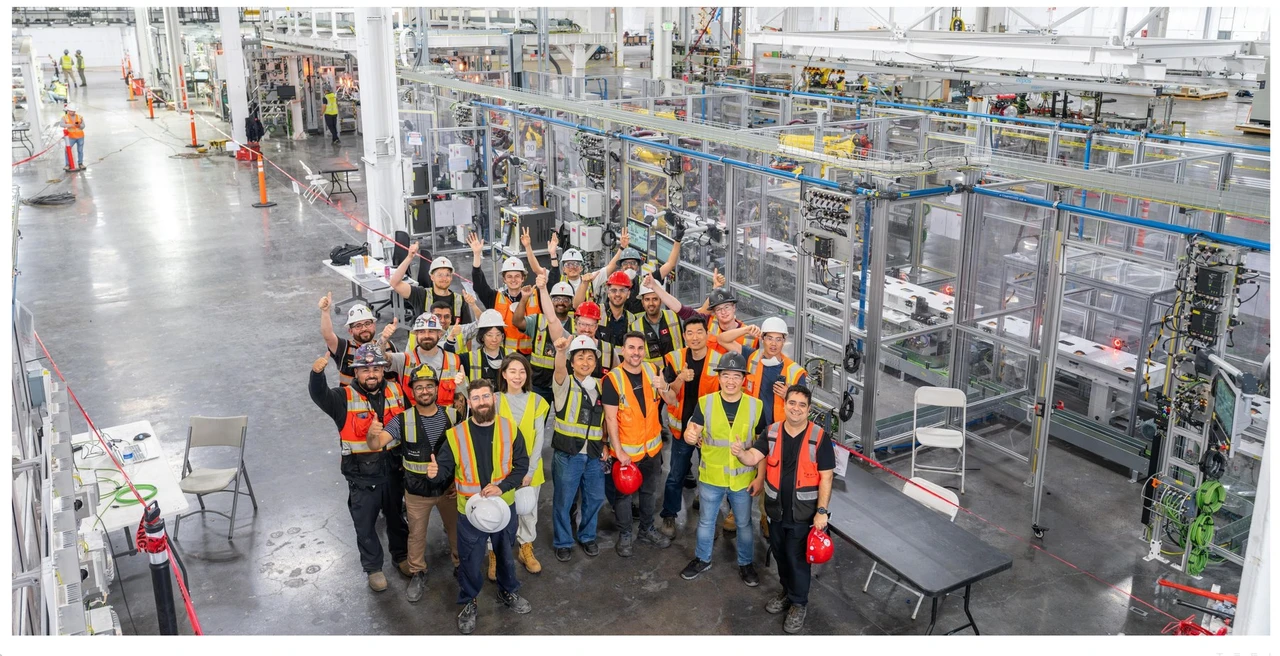
Tesla Begins Optimus Production; Musk Says Reaching 20,000 Units a Week Will Take at Least a Year
Tesla's third-quarter 2026 shareholder letter confirms Optimus has entered early high-volume production at the Fremont factory, marking the first units to meet mass-production quality standards, though the company notes that hardware and manufacturing processes will continue to iterate as it approaches commercial readiness.
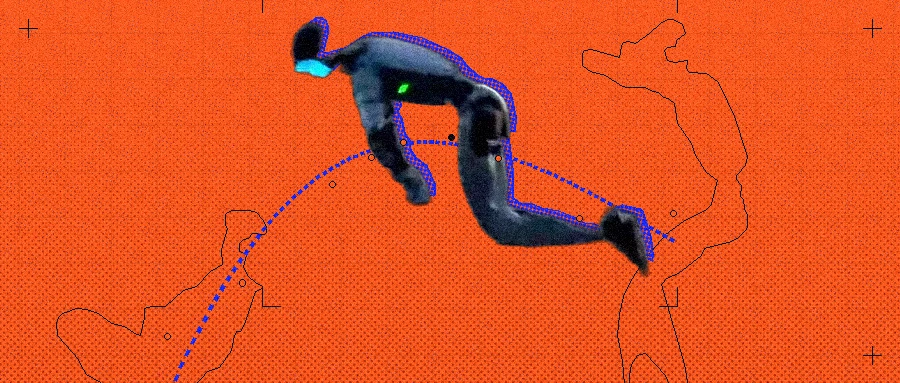
UC Berkeley's SuperMimic Slashes Compute for Humanoid Whole-Body Control
Accepted as an oral paper at CoRL 2026, the SuperMimic framework uses a differentiable world model to train humanoid whole-body control on a single GPU in three hours, outperforming previous methods that required massive GPU clusters.
Beyond the Hardware Sale: Can Robot Integrators Turn a Profit?
While robot manufacturers focus on hardware sales, system integrators are tasked with making these machines actually work on the factory floor. However, turning a profit from this secondary development is proving difficult, with a single palletizing project requiring over RMB 1 million in combined hardware and software investment.
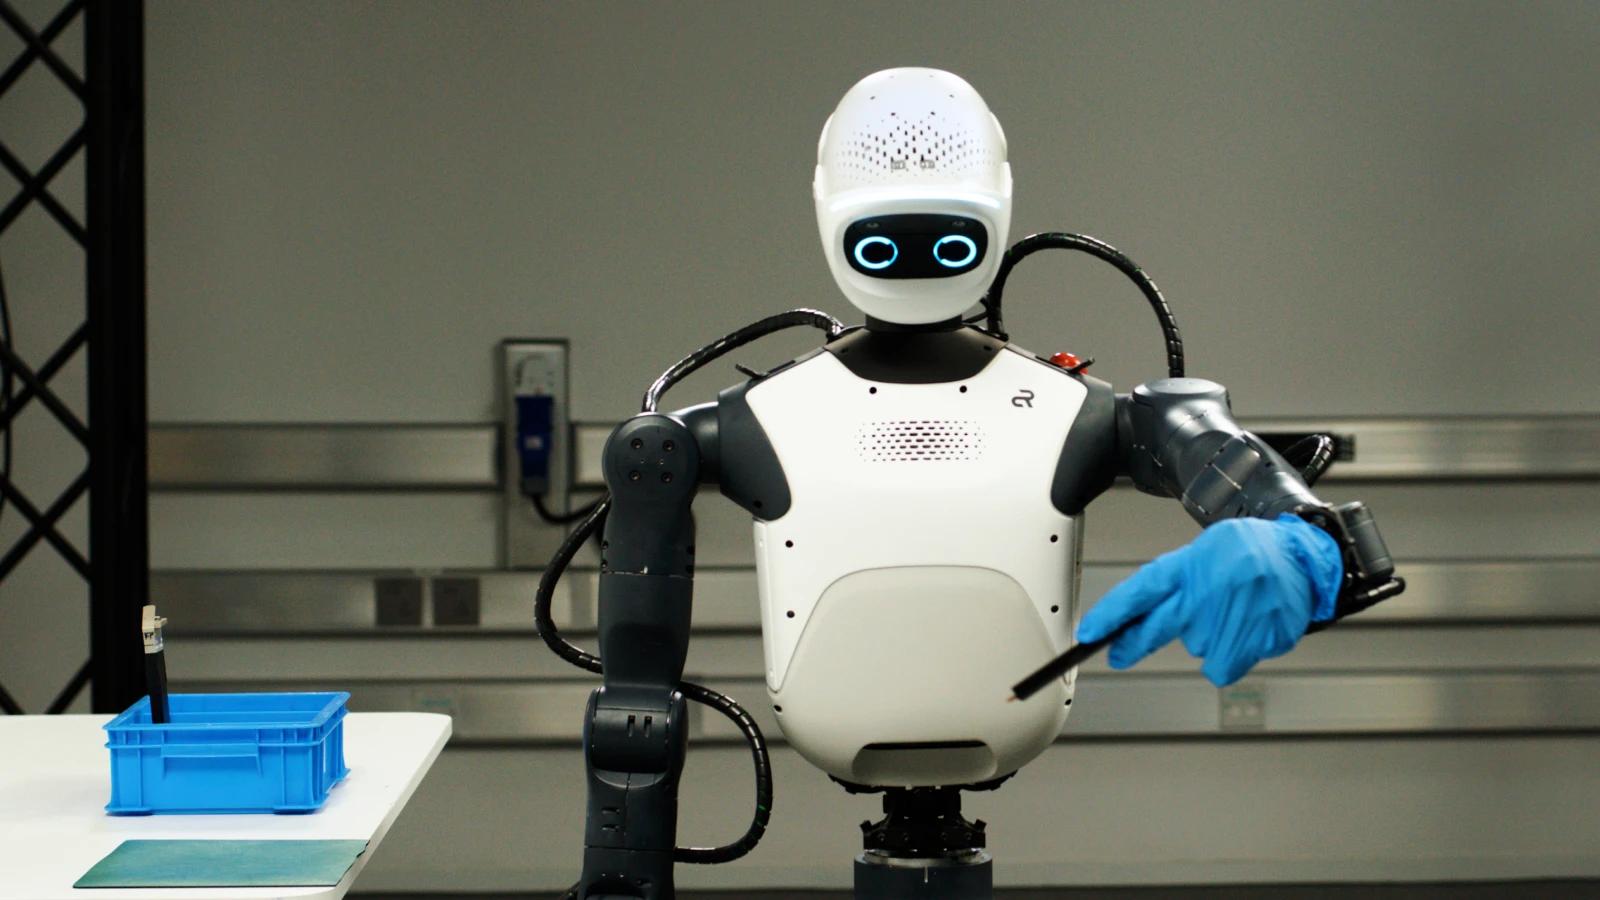
Agile Robots and NVIDIA Launch Agile ONE SN Reference Humanoid for Research Labs
On October 21, NVIDIA expanded its Isaac open robot development platform at GTC Berlin, while Munich-based Agile Robots and NVIDIA simultaneously introduced the Agile ONE SN, a ready-to-use reference humanoid robot targeting academic research.
Tesla Confirms Optimus Production and Early Ramp in Q3 Earnings
In its third-quarter 2026 earnings report released on October 21, Tesla confirmed that the first production-quality Optimus humanoid robots have rolled off the line at its Fremont factory, marking the start of an early ramp for the California project.
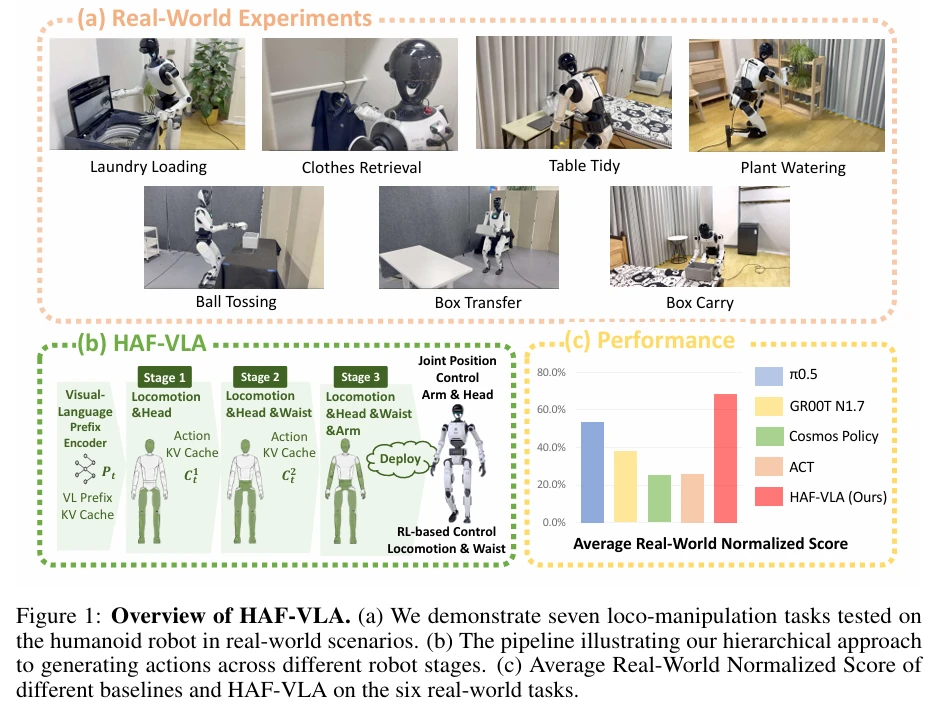
HAF-VLA Enables Hierarchical Generation of Coordinated Full-Body Actions in Humanoid Robots
A joint team from Peking University, Tsinghua University, and other institutions has proposed HAF-VLA, a hierarchical framework that enables humanoid robots to generate coordinated full-body actions by sequentially planning movements along the kinematic chain to avoid compensatory instability.
Dream Labs Raises USD 90 Million in Seed Funding, Debuts Robot Foundation Model Dream-1
On October 19, robotics AI startup Dream Labs announced the close of a USD 90 million seed round alongside the launch of its robot foundation model, Dream-1, and a public API.
In Conversation with Saturday Robotics Founder Junfan Zhu: “By the Time a Robotics Paper Is Published, Its Approach May Already Be Out of Date”
How Junfan Zhu is building a cross-disciplinary robotics research community in the Bay Area while working on better ways to evaluate AI systems in the physical world, and why he thinks robotics has yet to have its benchmark moment.
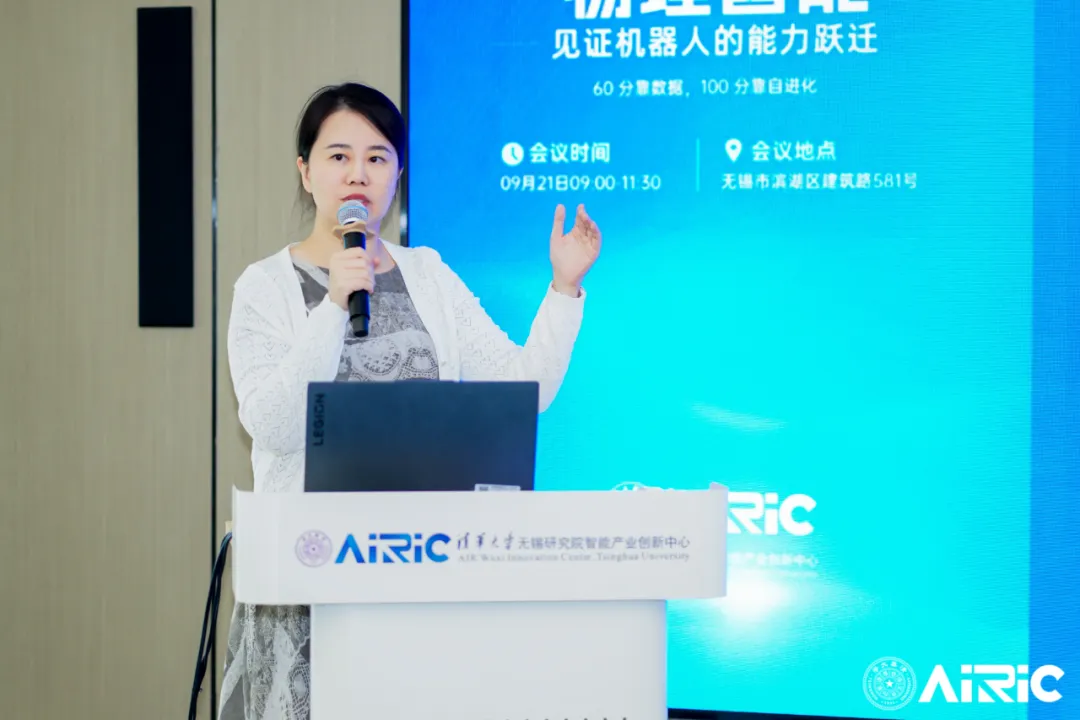
Tsinghua’s Cao Ting Unveils Zeva-Ego Model for Physical Self-Evolution via Causal Learning
At a Tsinghua University event, Zhang Ya Qin introduced Physical Self-Improvement (PSI), while Professor Cao Ting unveiled the Zeva-Ego model and ICCL framework to enable robots that learn causal relationships from real-world interaction.