

Whole-Body Control
3 related stories
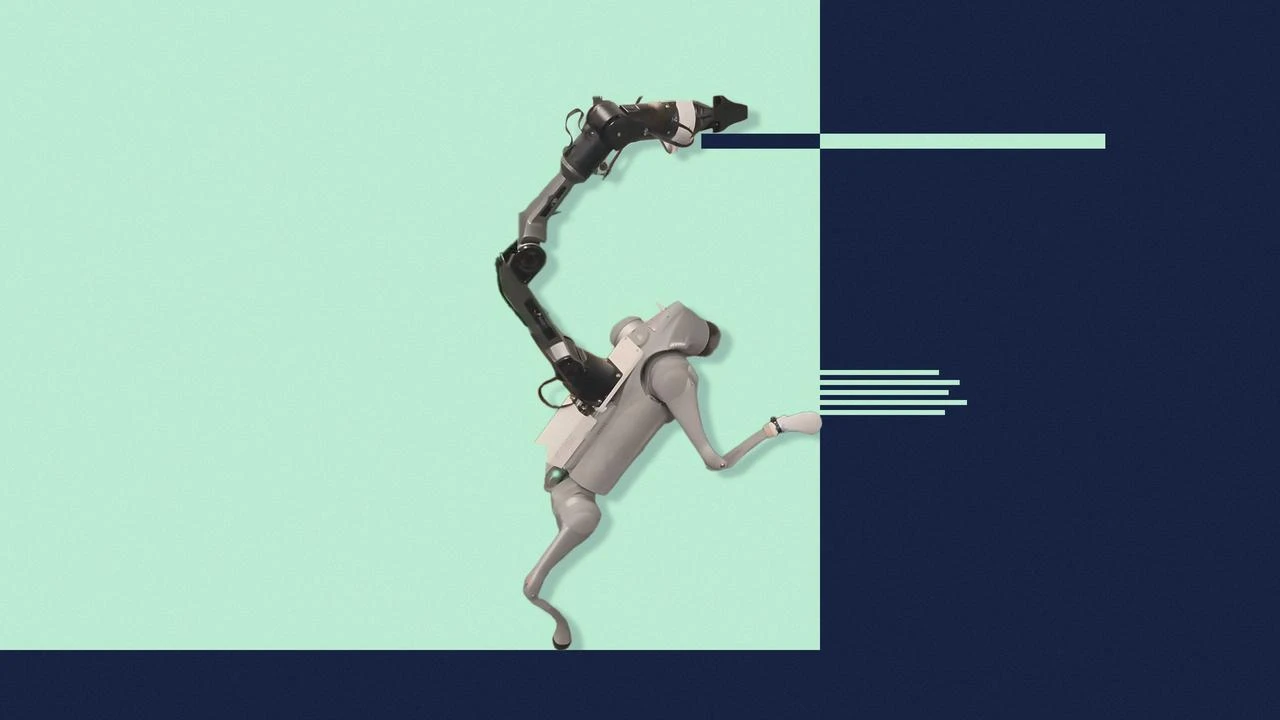
Carnegie Mellon Researchers Introduce ELEVATE Framework to Help Quadrupeds Acquire New Controllers from Task Failures
Quadruped robots with manipulators face a hard limit when required motions are absent from pre-trained libraries. The new ELEVATE framework enables these robots to autonomously diagnose missing physical capabilities during task failures and train new whole-body controllers using reinforcement learning.
UC Berkeley's SuperMimic Slashes Compute for Humanoid Whole-Body Control
Accepted as an oral paper at CoRL 2026, the SuperMimic framework uses a differentiable world model to train humanoid whole-body control on a single GPU in three hours, outperforming previous methods that required massive GPU clusters.
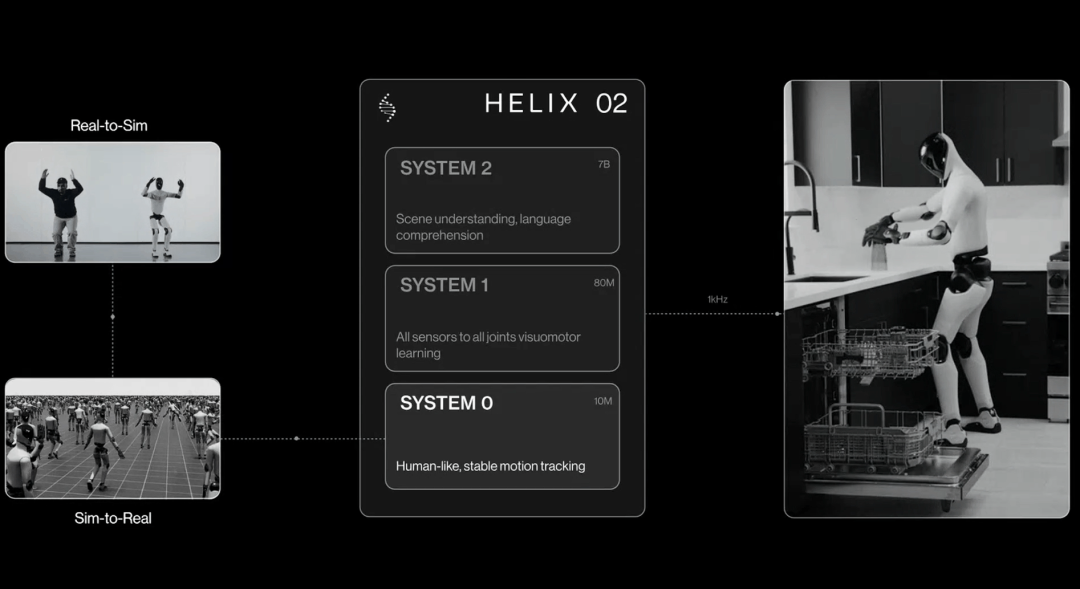
What Figure’s System 0 Integration in Helix Means
Figure AI's introduction of System 0 in the Helix 02 model marks a pivotal shift toward embodied AI, enabling seamless loco-manipulation by replacing traditional control code with a learned physical prior.