

Latest
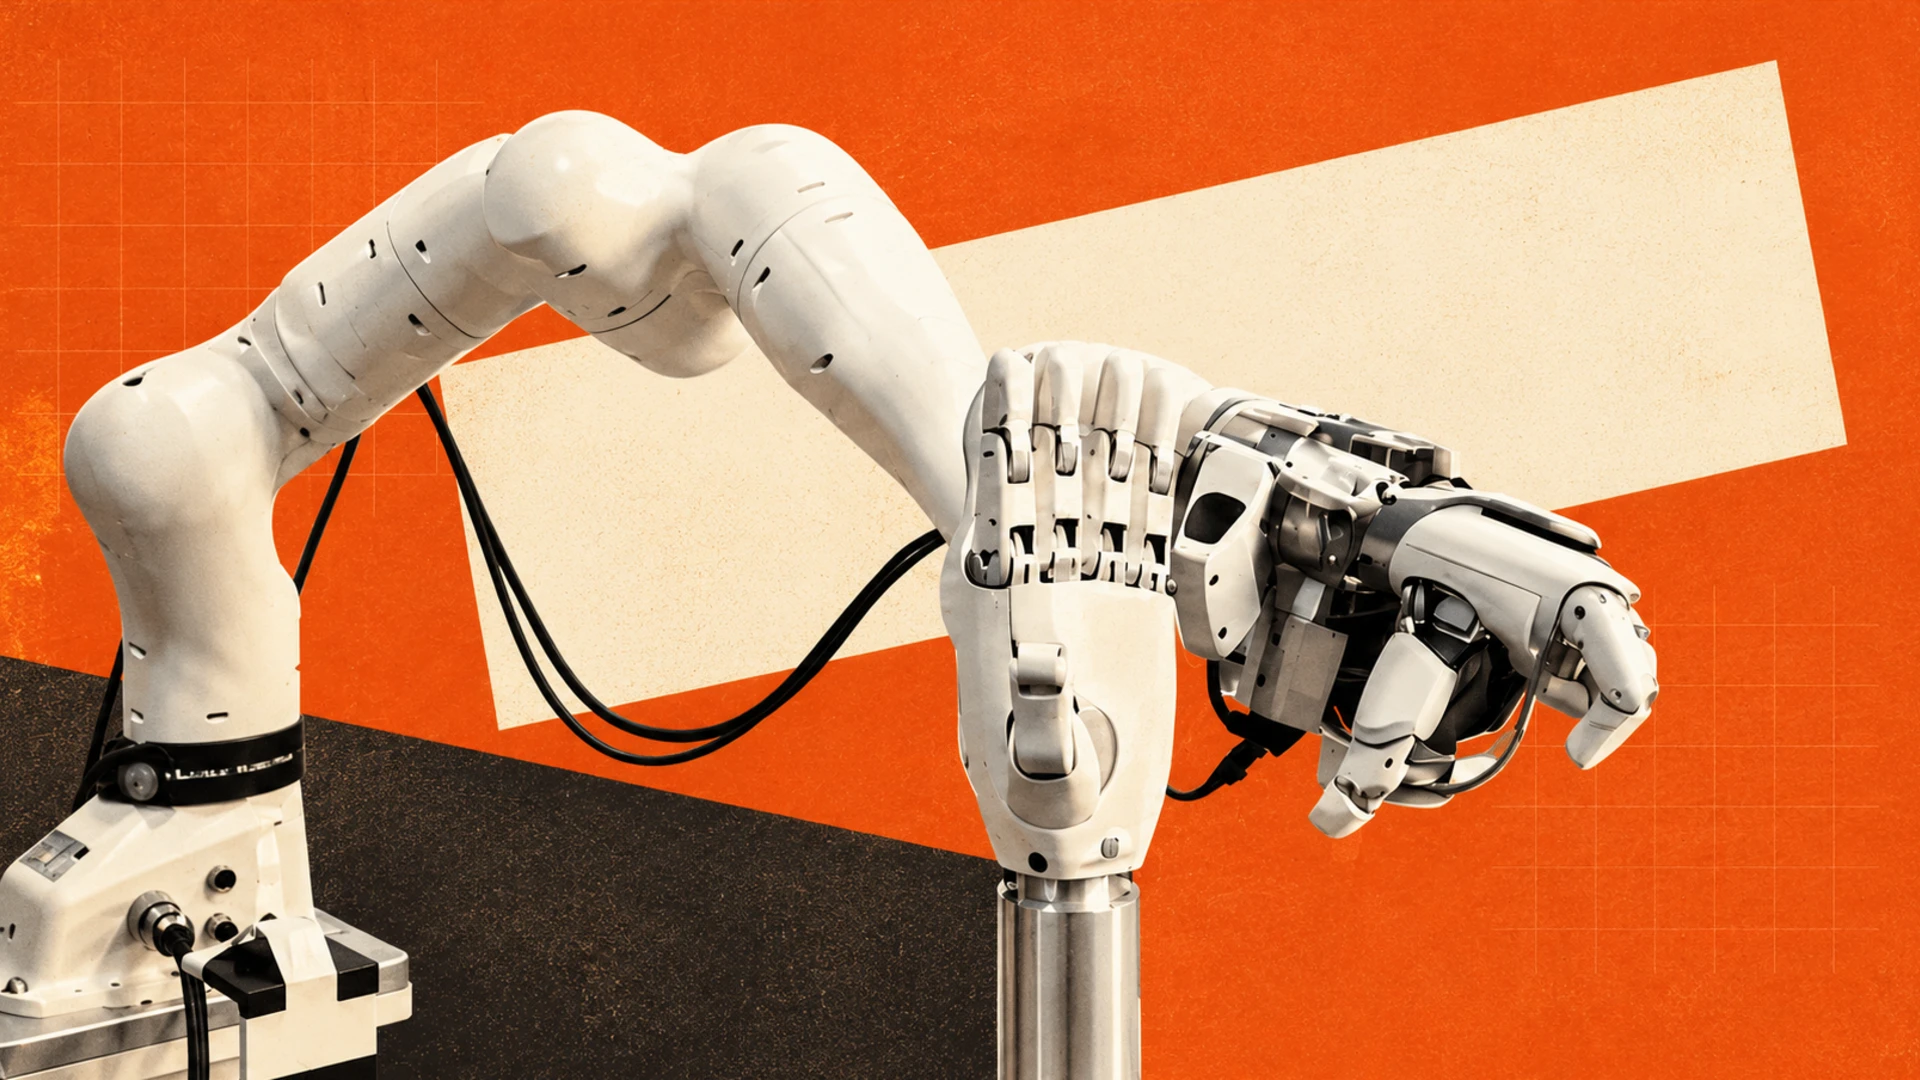
AGILINK Cuts Dexterous Hand Failure Rate to 0.5% for Industrial Deployment
At AgiBot's Innovation Day on October 29, AGILINK demonstrated a production testing station via a cross-city link, where a dexterous hand used a screw gun to test another unit awaiting factory release. At the company's joint manufacturing base with Wolong in Shaoxing, the robot executes 72 operational steps, including material loading, barcode scanning, clamping, screw tightening, equipment activation, and unloading.

AgiBot Proposes 'Worken' Metric to Measure Actual Robot Labor Output
Following the deployment of over 300 robots at Chimelong, AgiBot introduced the "Worken" metric to evaluate actual labor output rather than mere deployment numbers, highlighting the ongoing challenge of scaling on-site engineering support.
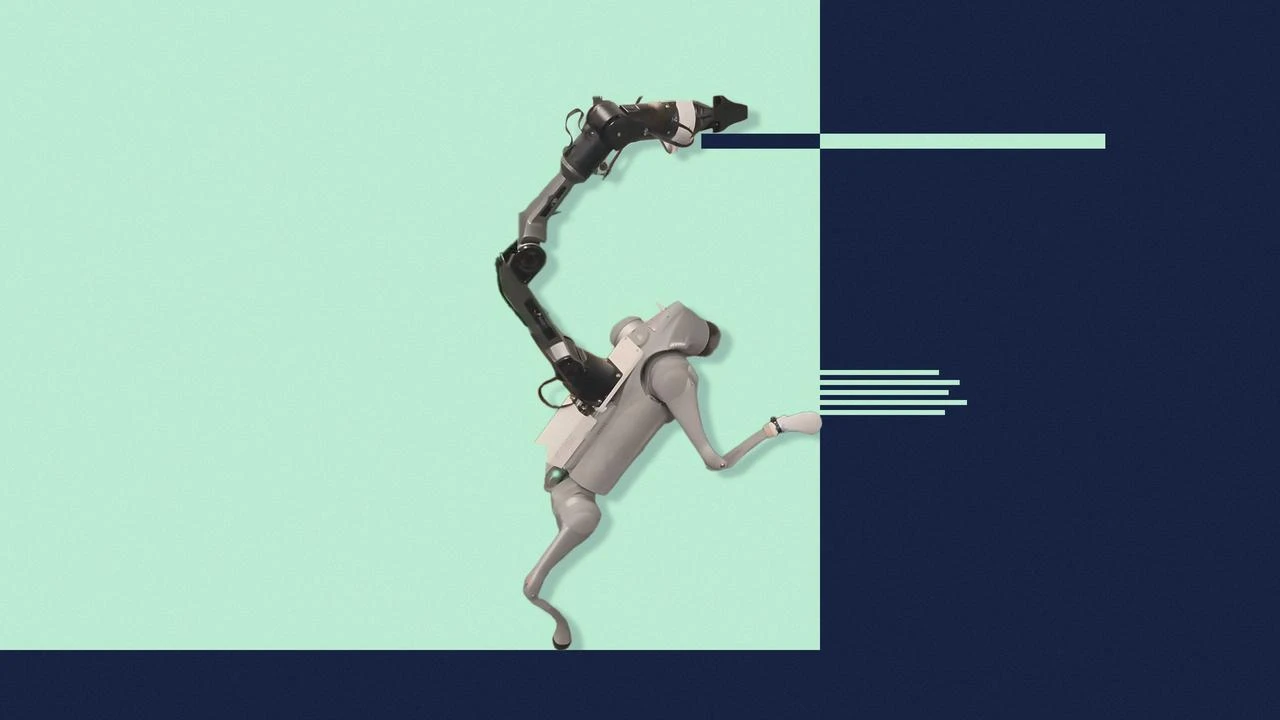
Carnegie Mellon Researchers Introduce ELEVATE Framework to Help Quadrupeds Acquire New Controllers from Task Failures
Quadruped robots with manipulators face a hard limit when required motions are absent from pre-trained libraries. The new ELEVATE framework enables these robots to autonomously diagnose missing physical capabilities during task failures and train new whole-body controllers using reinforcement learning.
ACE Robotics and Nanyang Technological University Release Mundo, an Interactive World Model
On October 30, ACE Robotics and the S-Lab at Nanyang Technological University released Mundo, an environment-specific world model that converts a small number of images or videos into explorable, interactive 3D scenes for robot navigation and manipulation training. The system integrates 3D scene representation, physical simulation, and video generation with Astra to enable spatial understanding.

PokeBot Launches Free RoboAPI to Adapt a Single World-Action Model Across Multiple Robot Arms
On October 30, PokeBot released RoboAPI, a public interface for its proprietary Poke-Aurora world-action model, aiming to eliminate the need for repeated data collection and retraining when developers switch robot hardware.
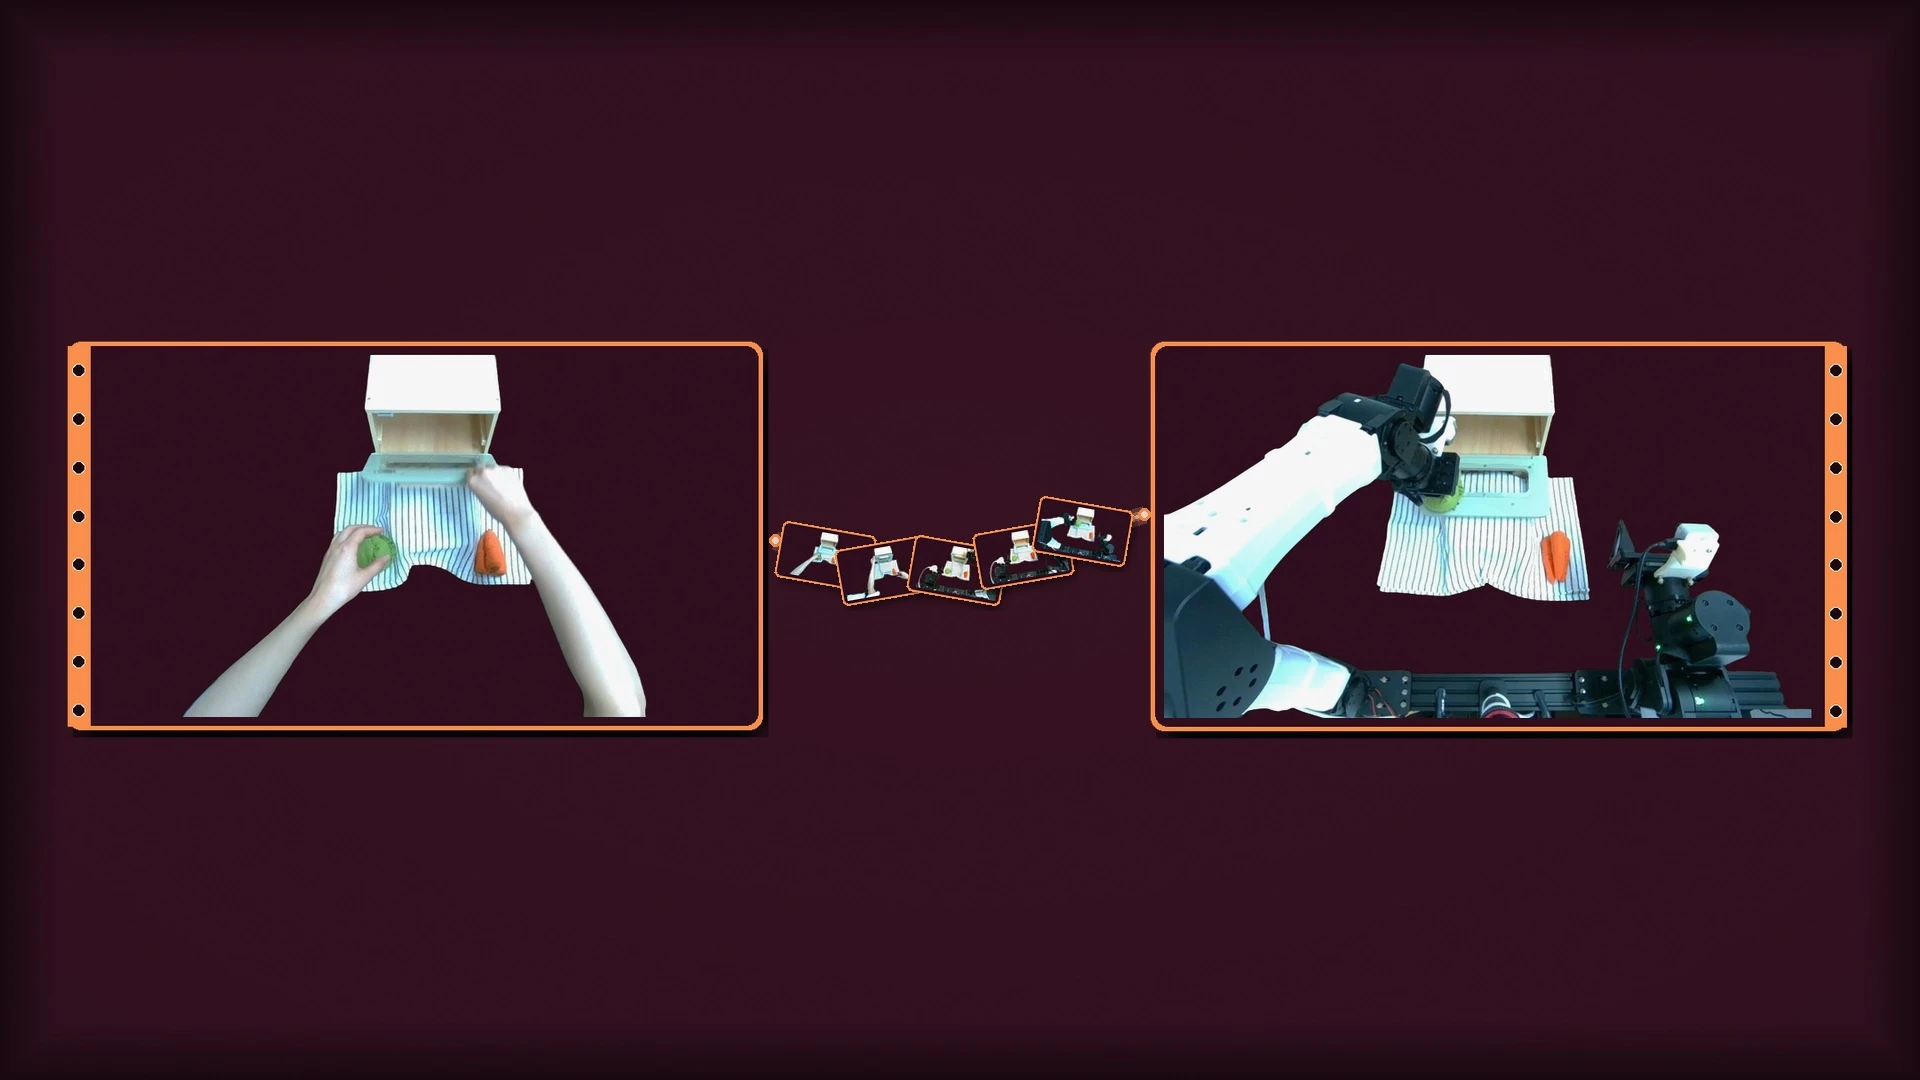
NVIDIA Proposes ThinkWorld to Train VLAs on Unannotated Human Videos via Chain-of-Dynamics and Imagined Futures
NVIDIA and KAIST introduce ThinkWorld, a vision-language action framework that leverages chain-of-dynamics reasoning and imagined future states to extract training signals from unannotated human videos for robot policy learning.
Unitree's First Post-IPO Earnings: Q3 Revenue Surges Nearly 70% as Net Profit Declines
Unitree's first post-IPO financial report shows third-quarter revenue jumping nearly 70% year-on-year while net profit fell and R&D spending surged 2.5-fold, reflecting the company's pivot of hardware earnings and IPO funds into embodied AI.
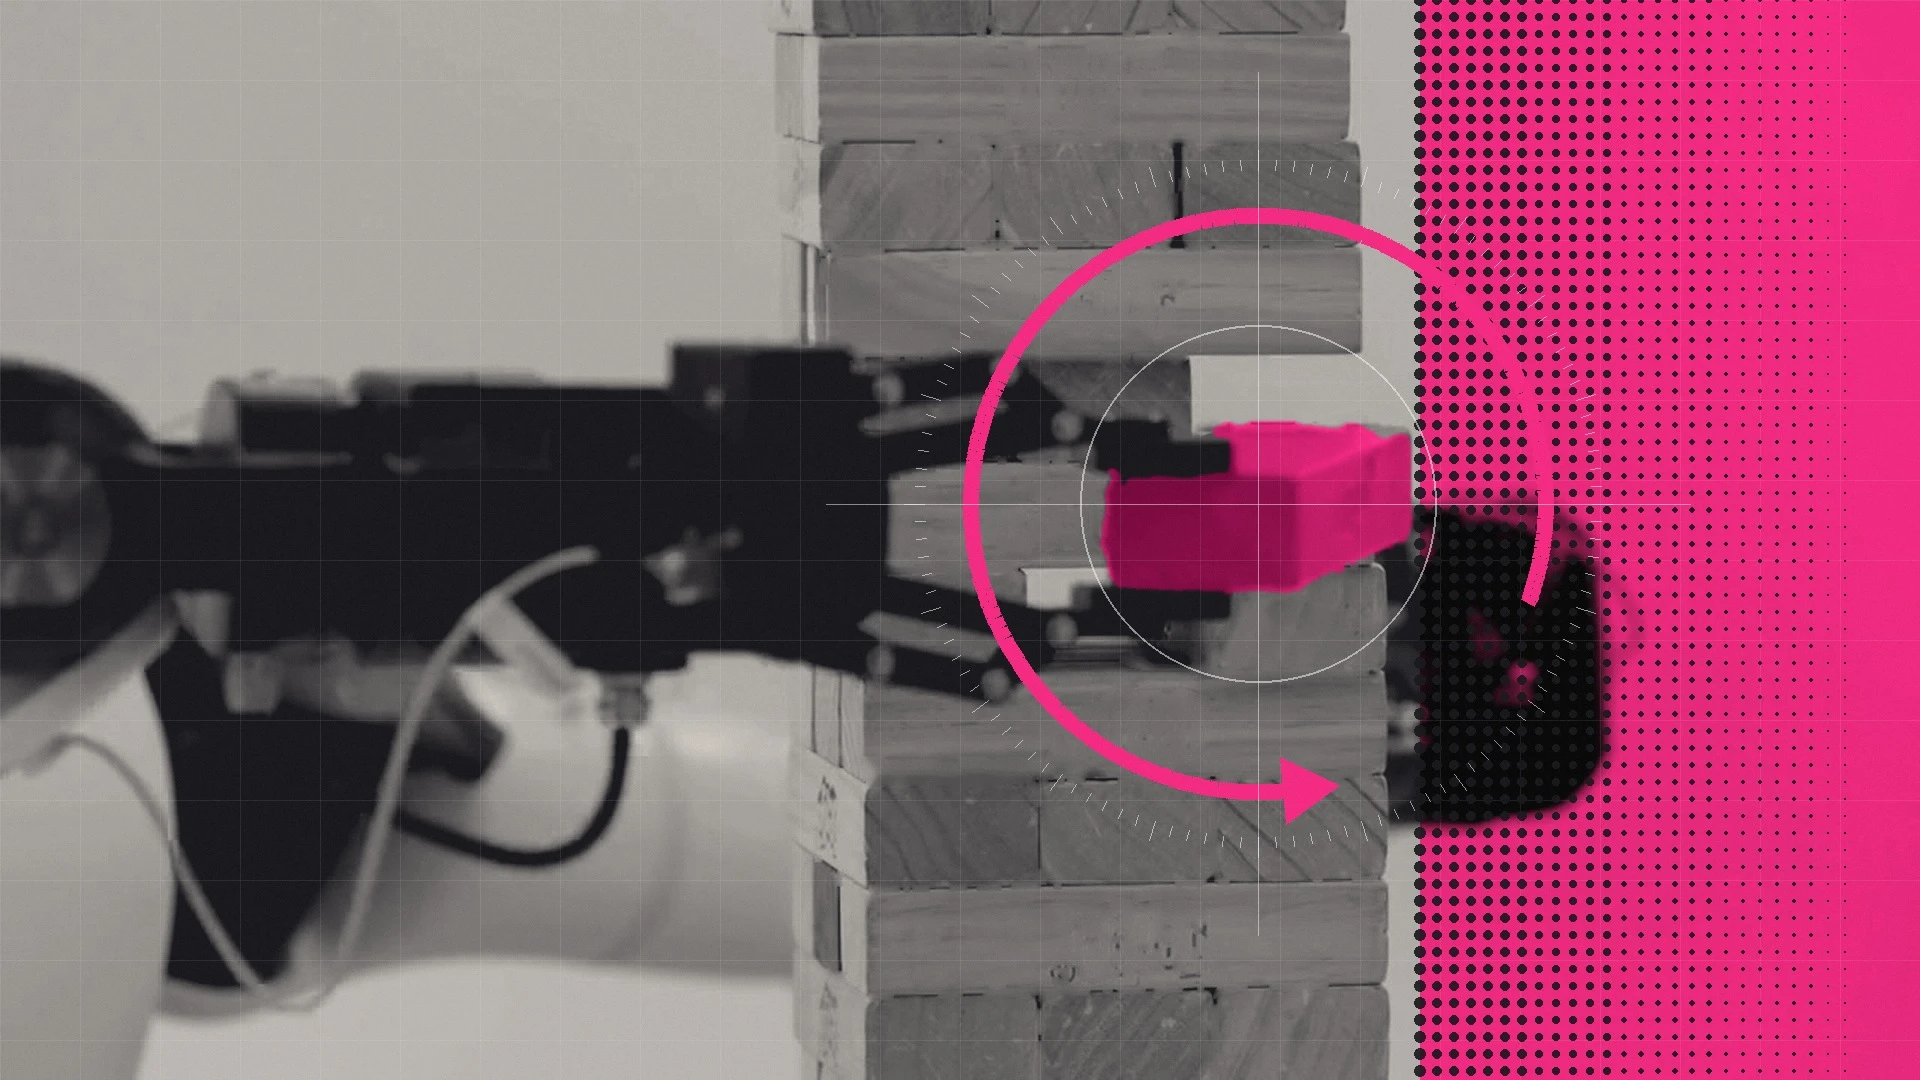
AgiBot's Rollback Method Uses World Model 'Rewind' to Surpass Human Averages in 8 Hours of Real-Robot Training
AgiBot, Beihang University, and the National University of Singapore introduced Rollback, a policy improvement method that backtracks within a world model to explore alternative actions. Trained on a single real robot for eight hours, the approach outperformed human baselines in ball tossing and tabletop curling by eliminating costly physical scene resets.
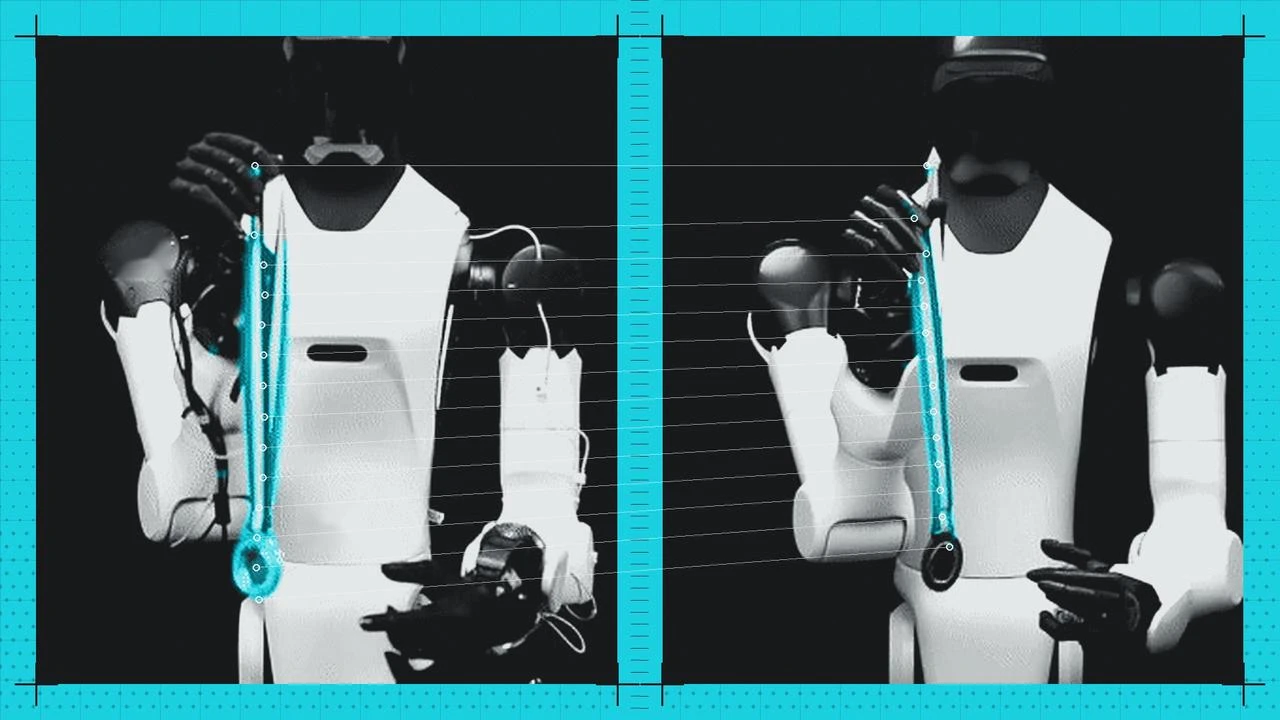
AgiBot Upgrades Genie Sim to Unify Robot Training and Evaluation via Flexible-Body Simulation
Folding a towel or tightening a drawstring bag is simple for humans but challenging for robots, as fabrics and ropes continuously deform and contact friction alters subsequent manipulation conditions. If simulation fails to replicate these dynamics, robots may perform well virtually but fail in real-world deployment.
Google DeepMind Unveils Genie 4, the First World Model in the Series to Generate Native Audio
Google DeepMind has released Genie 4, a new real-time interactive world model that natively generates audio, prompting questions about how close such sounding, simulated environments are to being used for robot training.
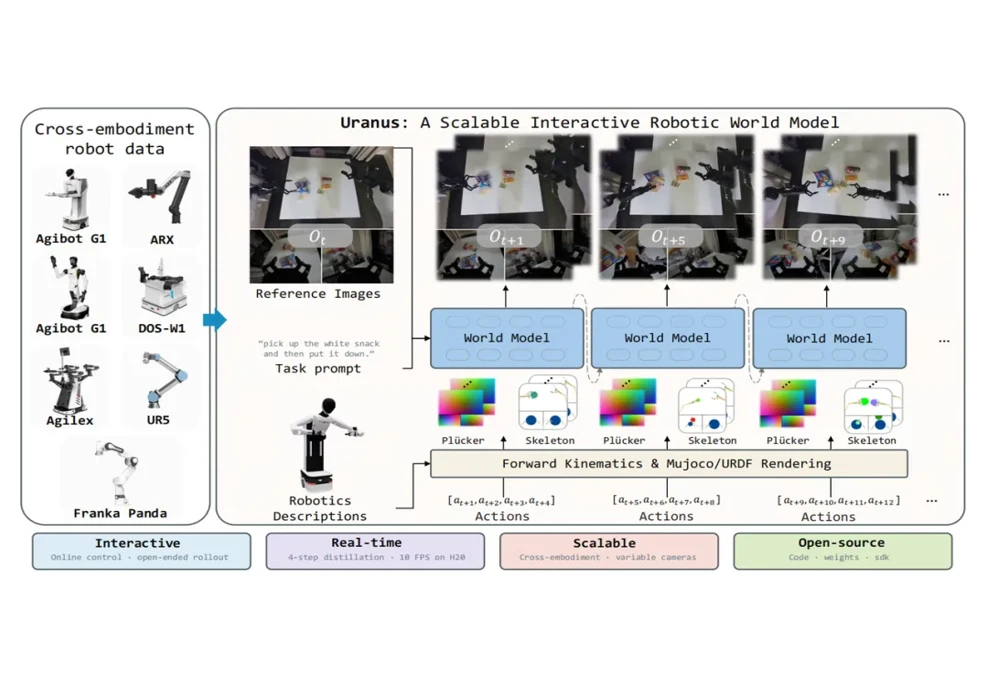
D-Robotics Open-Sources Uranus World Model Simulation Platform, Achieving 0.98 Correlation in RoboTwin Closed-Loop Evaluation
On October 27, the D-Robotics large model team open-sourced the Uranus technical report alongside its inference code, SDK, and model weights, offering 100 early access slots to developers and researchers worldwide.
Ball Screw Suppliers Await Tesla's Production Ramp-Up Amid Unconverged Humanoid Robot Designs
During Tesla's third-quarter earnings call, Elon Musk defended early production ramp-ups for Optimus despite unfinished hand designs, citing parallel progress in robot manufacturing, supply chain development, hardware design tweaks, and AI software. Meanwhile, Chinese ball screw suppliers are scaling capacity but waiting for actual downstream demand as humanoid robot joint architectures remain unsettled.