

Embodied AI
164 related stories
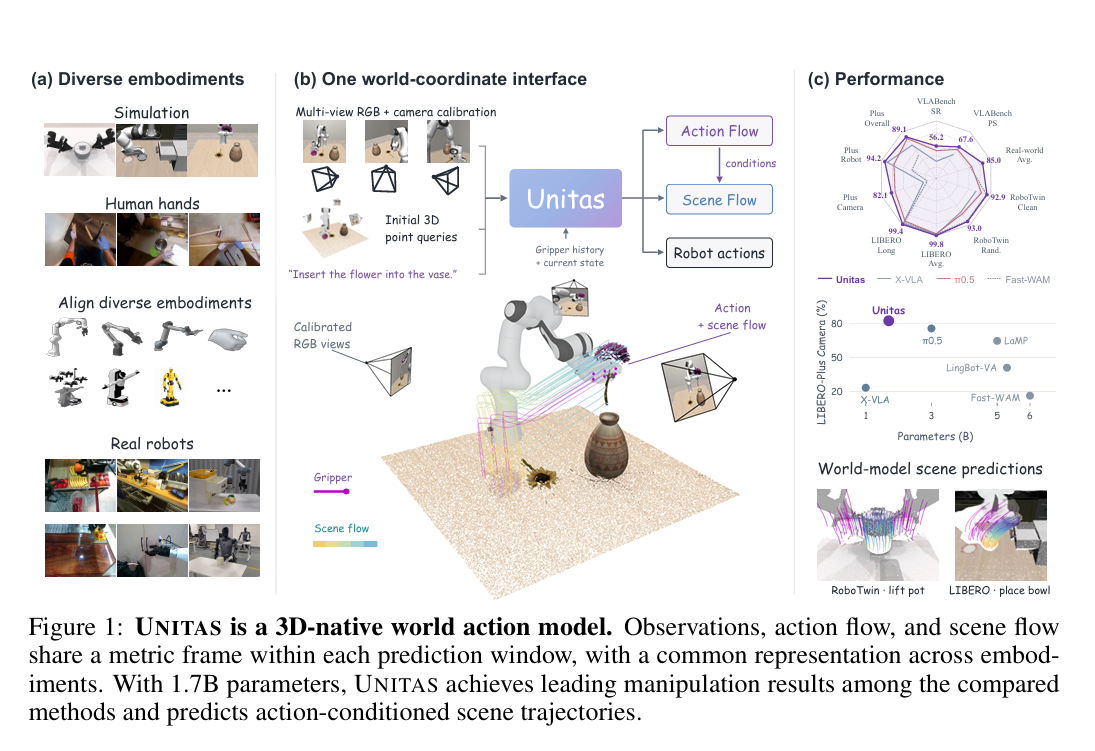
Kui Jia Team's New Work: Enabling World Action Models to Truly Understand 3D Space
A joint team led by Kui Jia has published UNITAS, a world action model that unifies observation, action, and scene changes in a shared metric 3D coordinate system. The 1.7B-parameter model achieves 99.8% task success on the LIBERO benchmark and reduces displacement prediction error by 35% compared to PointWorld.
DeepSeek Reportedly Eyes Embodied AI as Chinese and U.S. Foundation-Model Firms Signal Moves
Reports indicate DeepSeek is assessing a move into embodied AI through team building or investment, with plans to lead the seed round for Winverse AI at a post-money valuation of approximately USD 400 million.
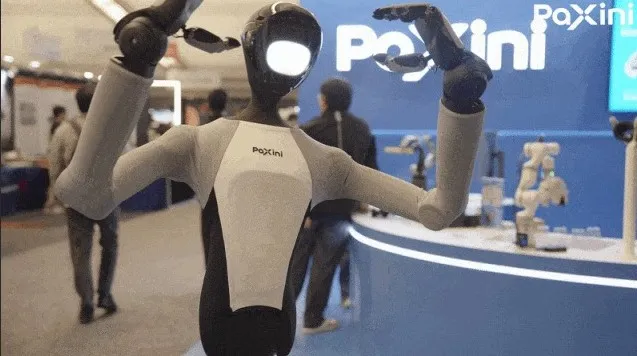
Tactile Sensor Startups Expand Beyond Hardware Into Data and Embodied AI
At IROS 2026, companies like PaXini and Sharpa unveiled full-stack solutions combining tactile sensors with dexterous hands and data platforms, signaling a shift from component suppliers to providers of embodied AI training data.
Yann LeCun’s Latest JEPA Paper: Where Does End-to-End Planning Go Next?
A new paper from Yann LeCun’s team introduces H-JEPA, a hierarchical world model that improves long-horizon planning success rates from approximately 18% to 73%. The architecture separates temporal scales to enhance stability and reduce computational costs in embodied AI tasks.
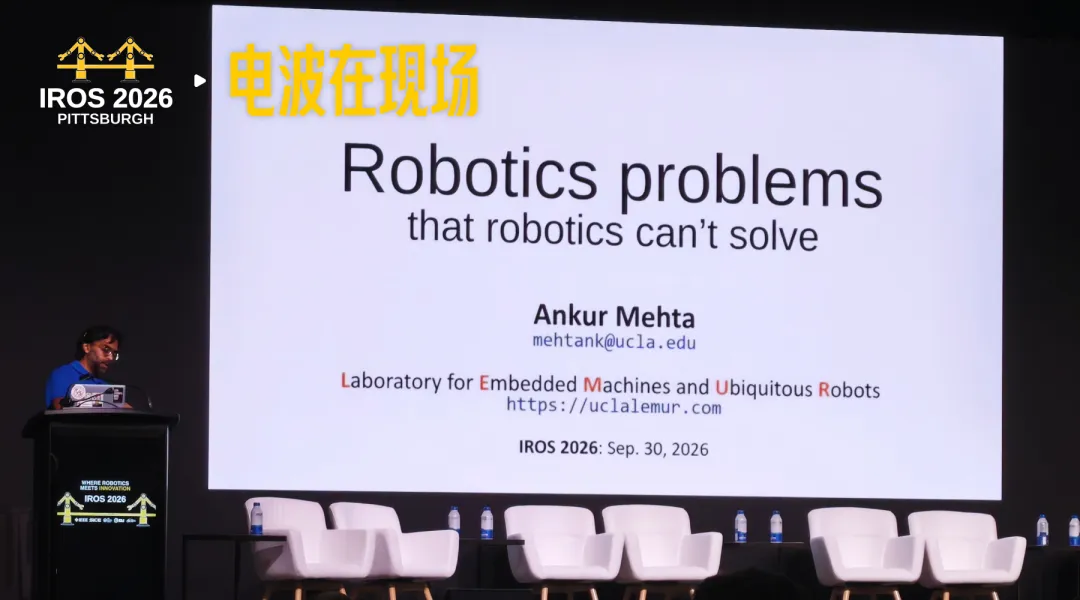
IROS 2026: UCLA's Ankur Mehta on Robotics, Public Trust, and Resource Constraints
In a keynote at the IEEE/RSJ International Conference on Intelligent Robots and Systems, Ankur Mehta highlighted how shrinking research funding, talent shortages, and public anxiety over AI and robotics are reshaping the field. He urged researchers to engage directly with communities to address concerns about equity and responsibility.
Purdue Team's IROS Best Paper Nominee: Active Palm and Multimodal Sensing in a Three-Finger Robot Hand
Yuhao Zhou and team from Purdue University present the VTAP Gripper, a three-fingered robot hand that achieves complex manipulation by making the palm active and multimodal. The design challenges the trend of adding fingers, proving that dexterity can come from effective use of existing contact surfaces rather than increased degrees of freedom.

Samsung Researchers Show Compressed VLA Model Outperforms Larger Teacher on Real Robots
Researchers from Samsung R&D Institute demonstrate that compressing a visual-language-action model's Transformer layers from 18 to 6 via knowledge distillation reduces inference latency by more than half while maintaining success rates, enabling faster real-world robotic deployment.
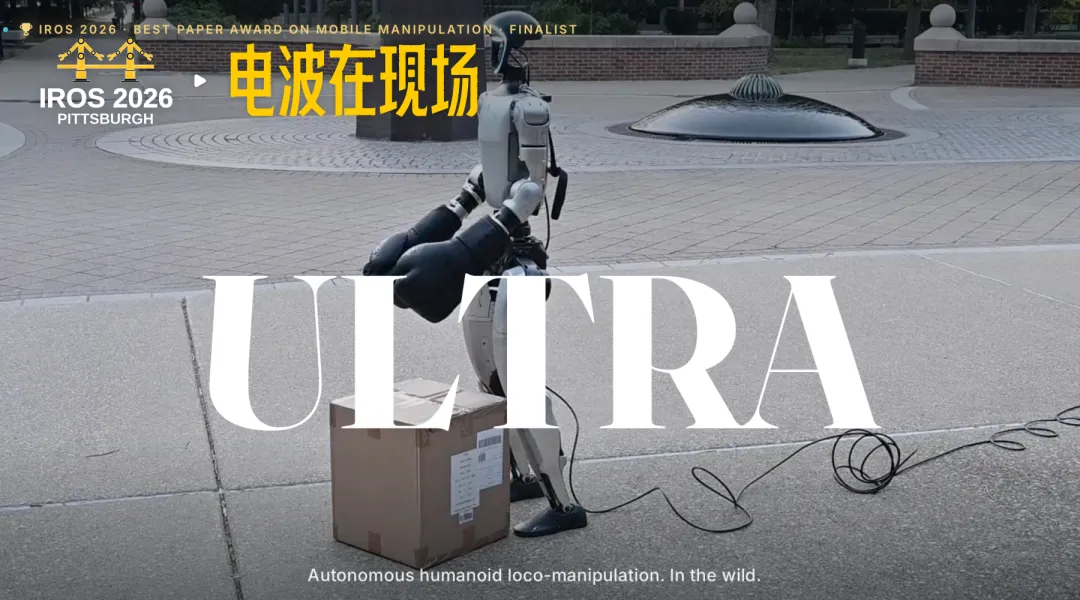
ULTRA: Toward Autonomous Whole-Body Movement and Manipulation
At IROS 2026, Xialin He and Sirui Xu from UIUC presented ULTRA, a unified multimodal control framework that enables humanoid robots to learn whole-body loco-manipulation through physical simulation and reinforcement learning.

Shanghai Jiao Tong University and LandSpace Team Release DynaForge to Turn Failed Robot Demonstrations into Training Data
Researchers from Shanghai Jiao Tong University and LandSpace have released DynaForge, a system that uses motion planning as a prior and residual learning to convert failed dynamic manipulation trajectories in simulation into valid training data for robot policies.
IROS Best Paper Finalist: Helping Robots Detect Glass for Safer Navigation
42HOW Robotics interviews co-first author Yu Jingwen on the Southern University of Science and Technology team’s RANSAC-based framework that fuses depth foundation models with sensor data to enable safe robot navigation through glass obstacles.

RIMBOT Unveils Physical RSI Framework, Targets Industrial Validation
RIMBOT, a robotics startup founded in March 2026, is deploying its Physical Recursive Self-Improvement framework in industrial ICT testing lines. Co-founder Yuanxin Zhong explains why factories offer the necessary failure data and infrastructure to move beyond zero-shot generalization toward continuous real-world learning.
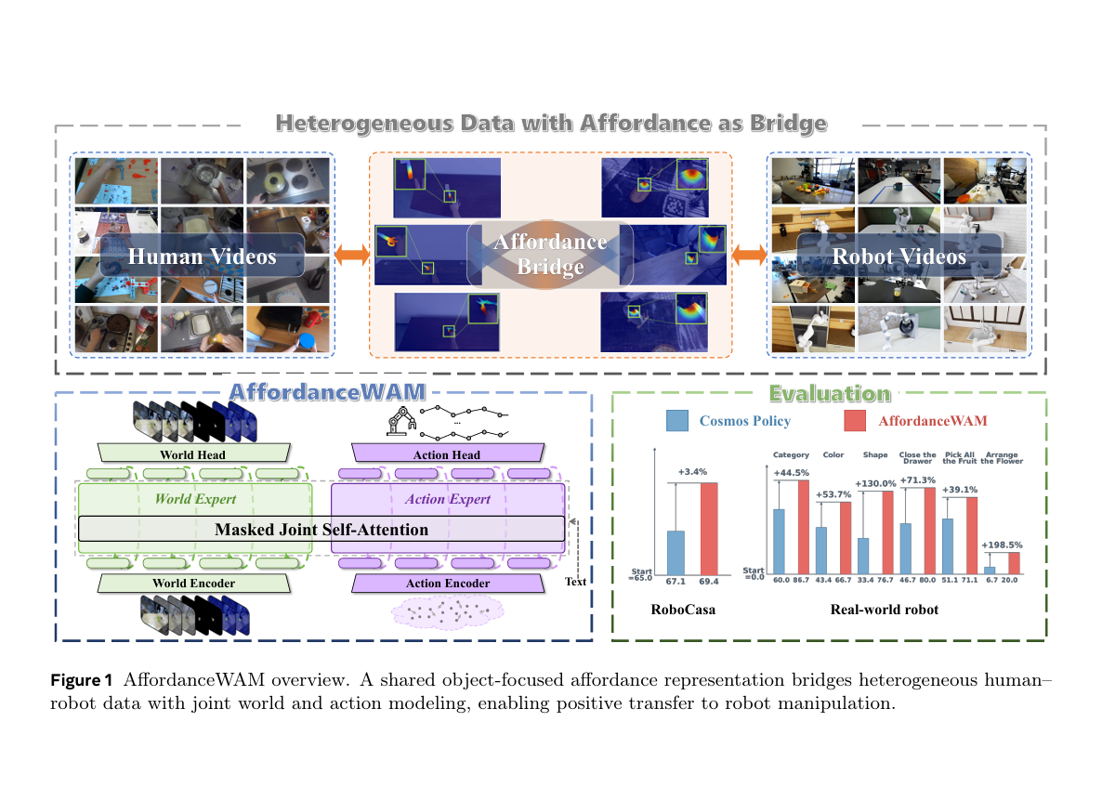
Five Universities and Knowin AI Release AffordanceWAM to Bridge Human Video and Robot Training via Affordance Prediction
A joint team from five universities and Knowin AI introduces AffordanceWAM, a world-action model that uses explicit affordance prediction to align human video data with robot training, resolving long-standing semantic mismatches in embodied AI.